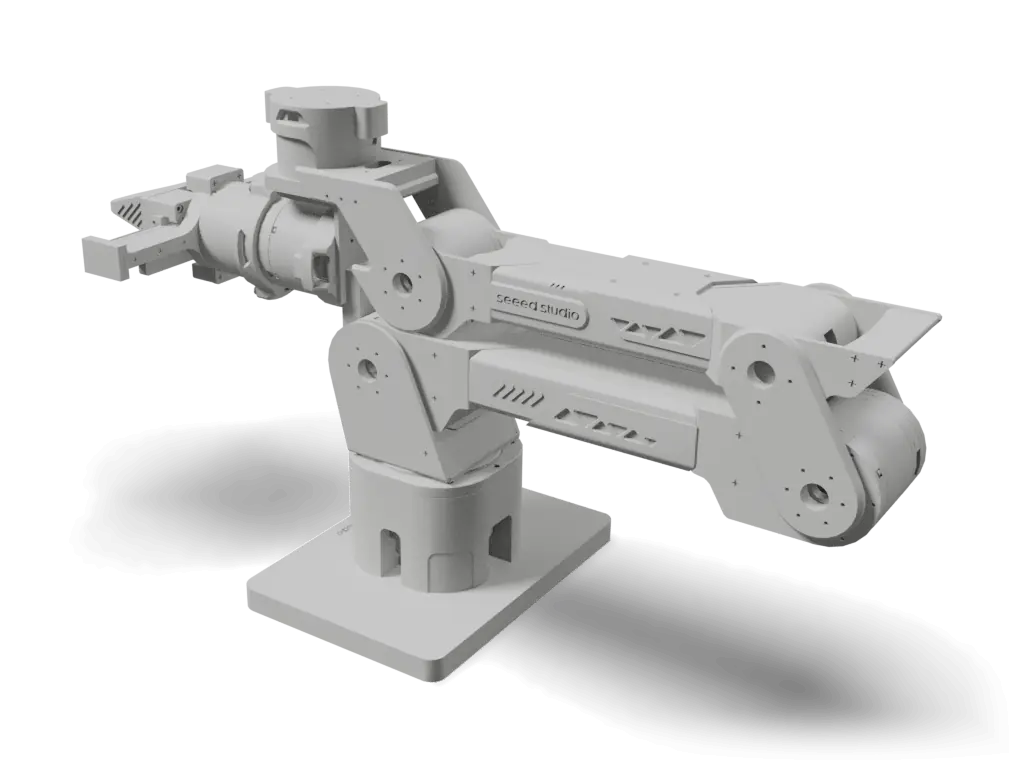
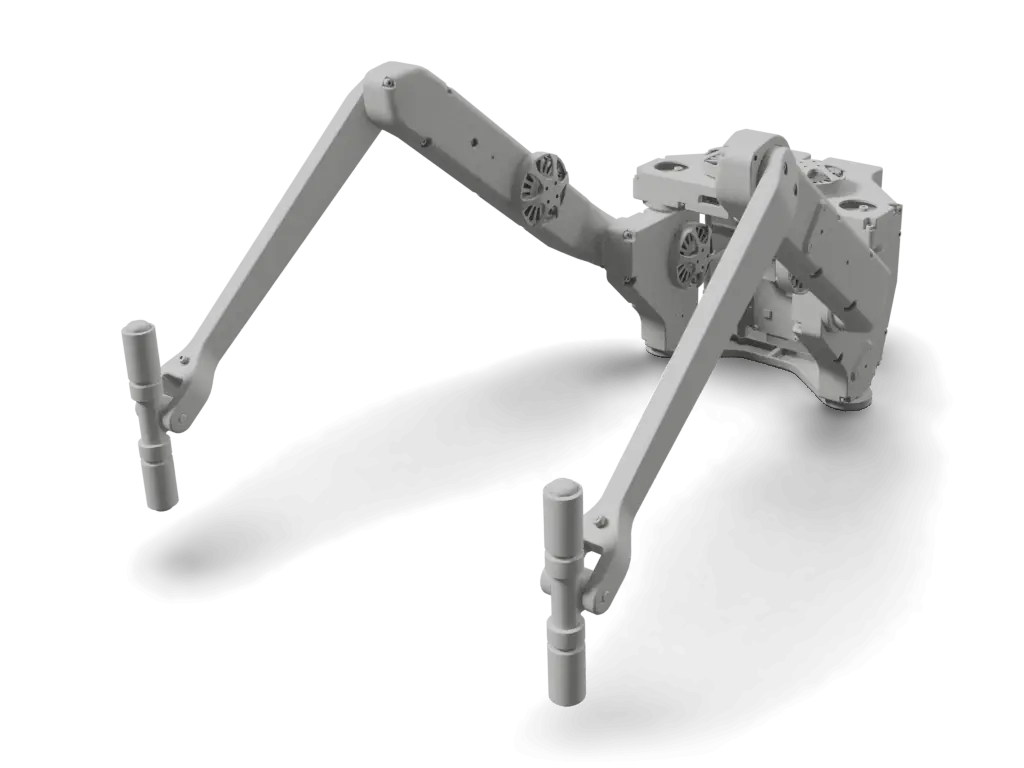
Open 6-DoF + gripper developer arm on Damiao or Robstride motors, 767 mm reach (B601-DM).
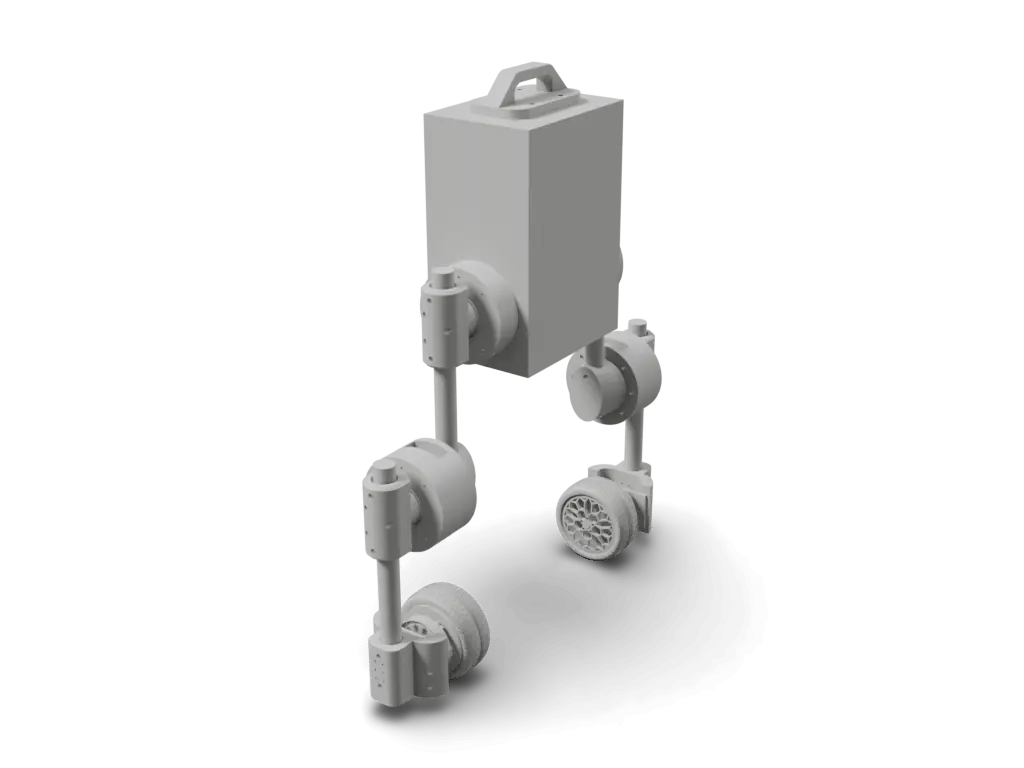
Wheeled biped that balances, build-it-yourself.
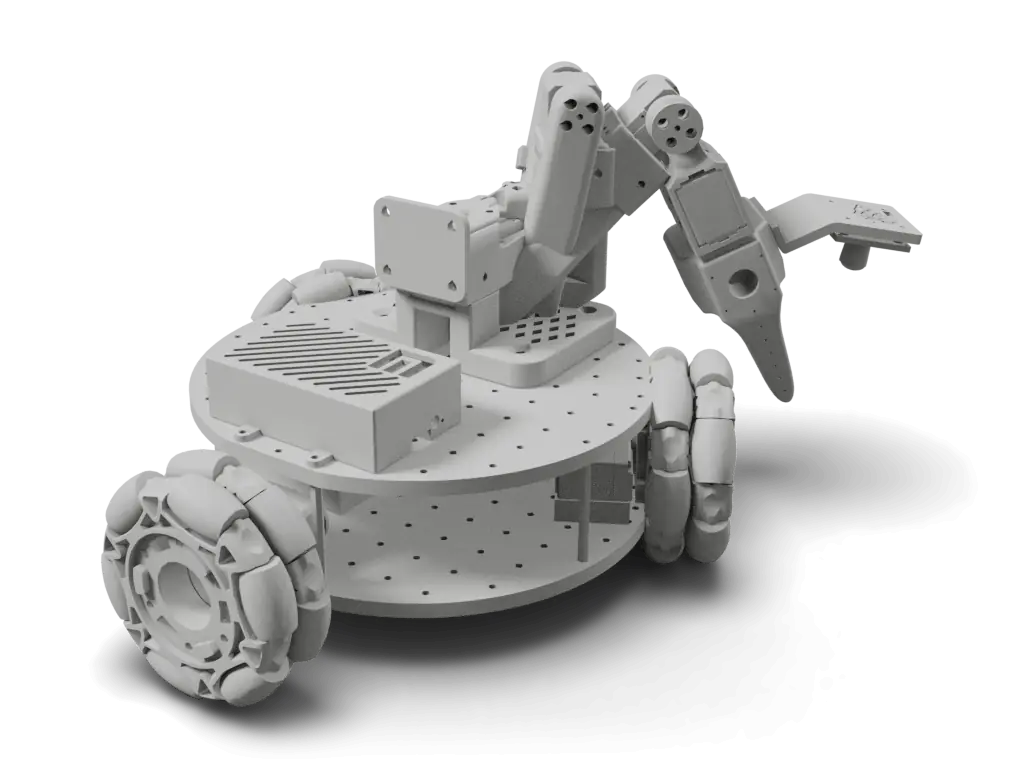
Mobile base + SO-arm, holonomic LeRobot rover.
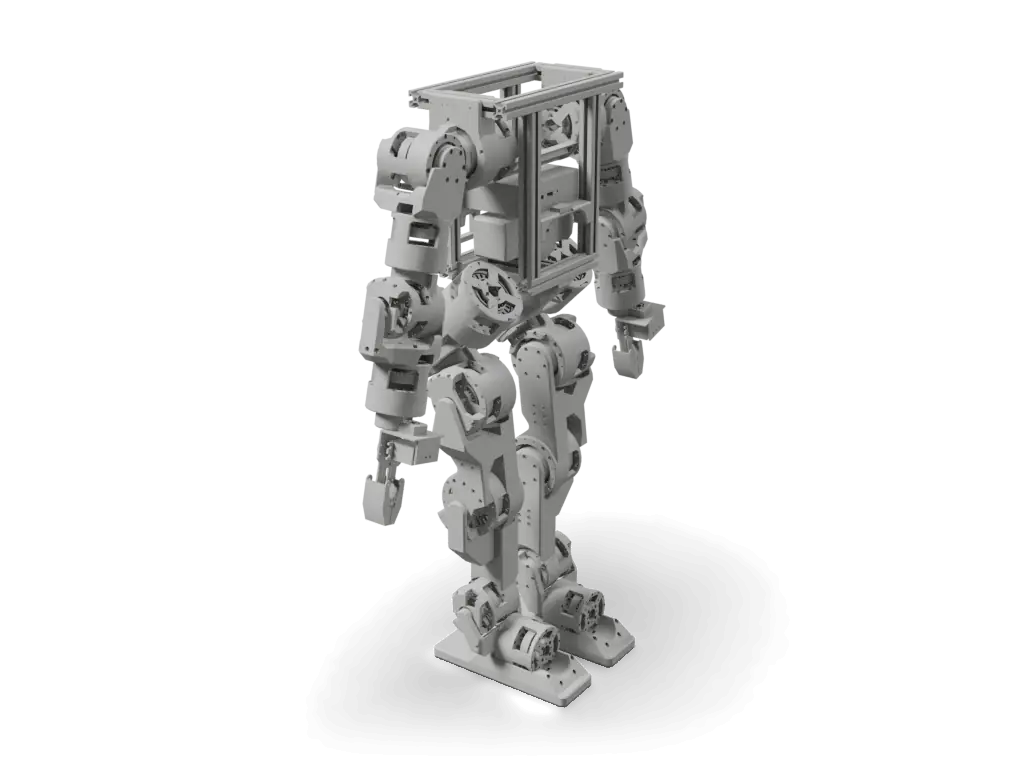
Open biped on RobStride actuators, with a costed BOM and a strict build order written for a builder working with an AI agent.
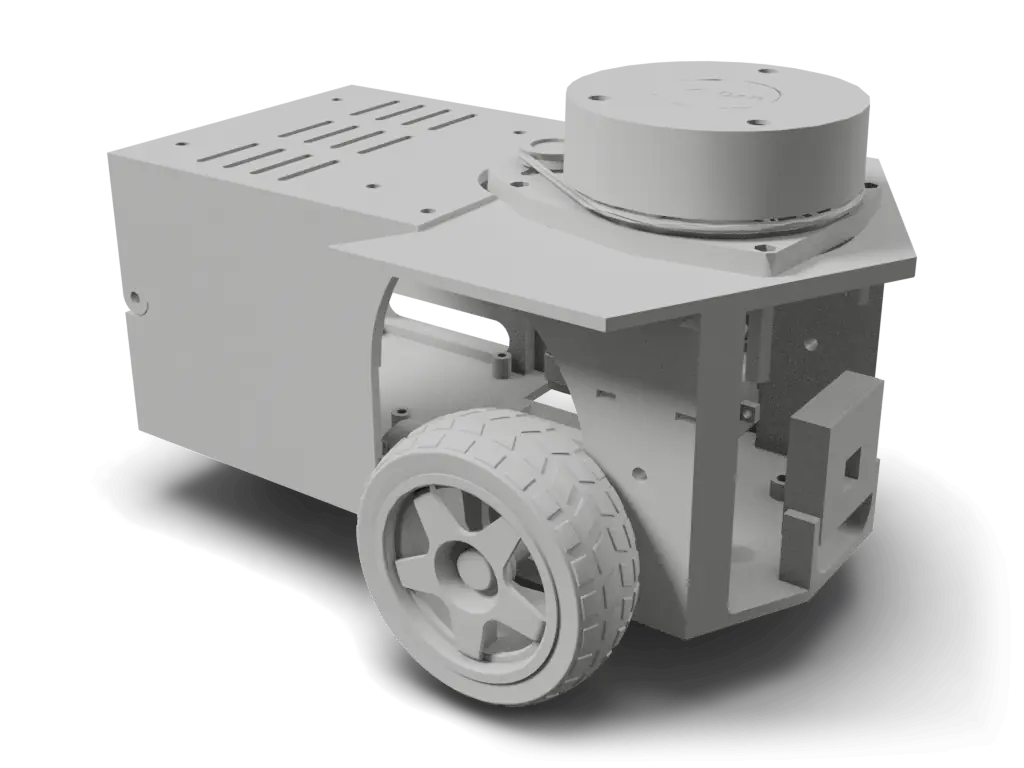
Open ROS 2 differential-drive robot with a parts list, URDF and a printable chassis.
Open actuator module plus Solo8/Solo12 quadruped, Bolt biped and TriFinger hardware; overlaps the Solo-12 page.
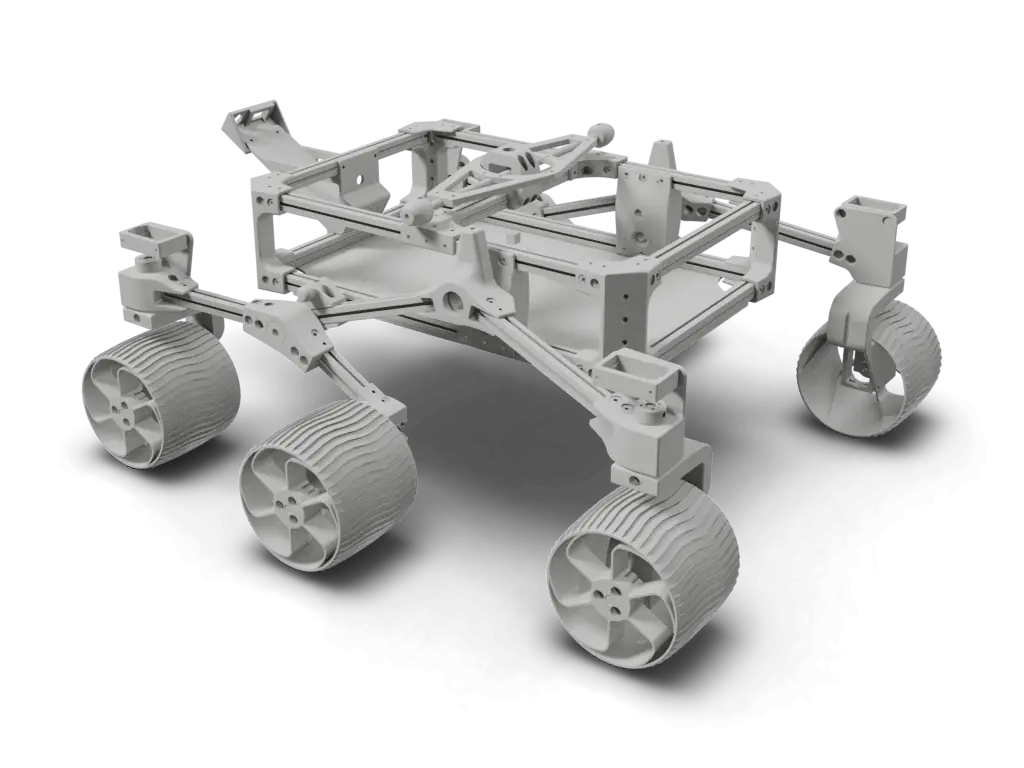
Rocker-bogie Mars rover model built from 3D prints, 15 mm extrusion and 10 bus servos.
Open-source 6-DoF stepper-driven robot arm by Skyentific.
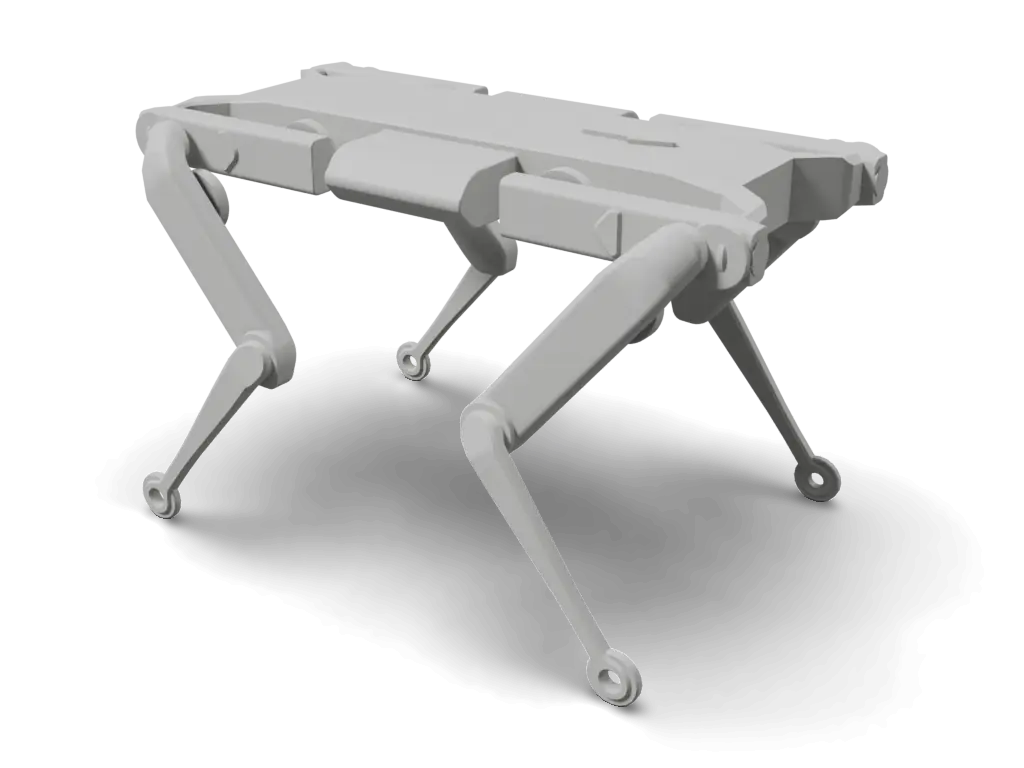
Open torque-controlled quadruped from the ODRI initiative.
M5Stack-based pan-tilt companion robot with JavaScript firmware and printable cases.
Sub-$5k open-source humanoid with modular 3D-printed cycloidal gearboxes.
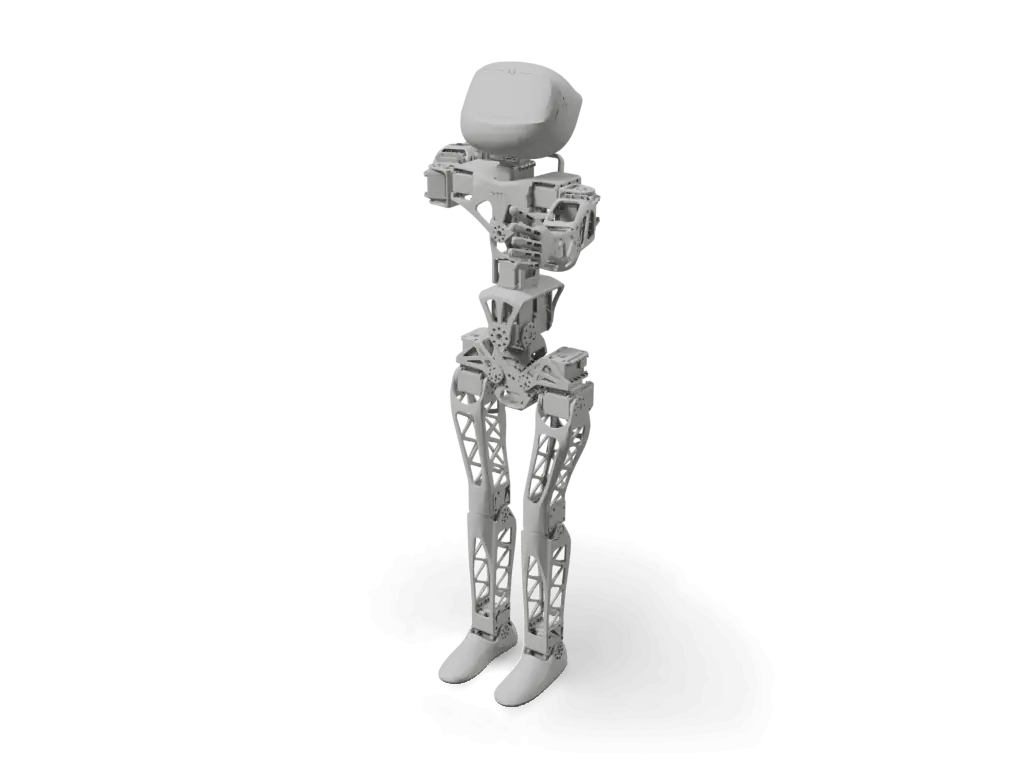
Open-source, mostly 3D-printed humanoid for research and education, driven by 25 Dynamixel actuators.