
Solo-12
Open torque-controlled quadruped from the ODRI initiative.
- Cost unknownnot published by the source
- 12 DoF
- BSD-3-Clausehardware
- 80 / 100 reproducibilityStrong source coverage, unverified
What it is
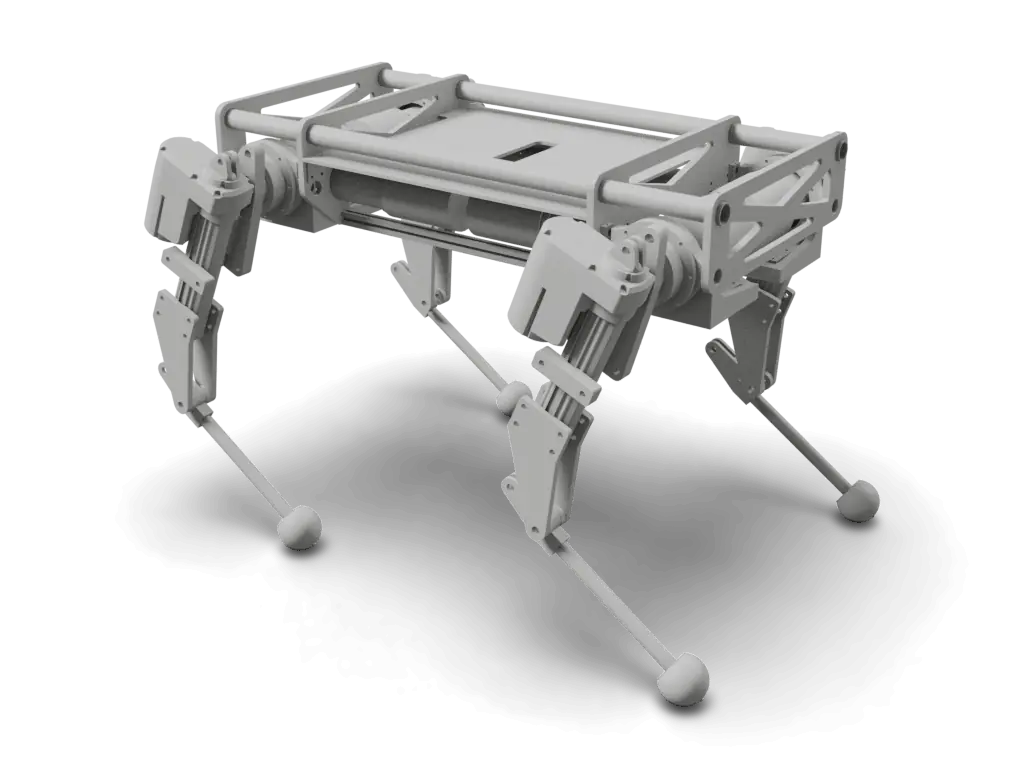
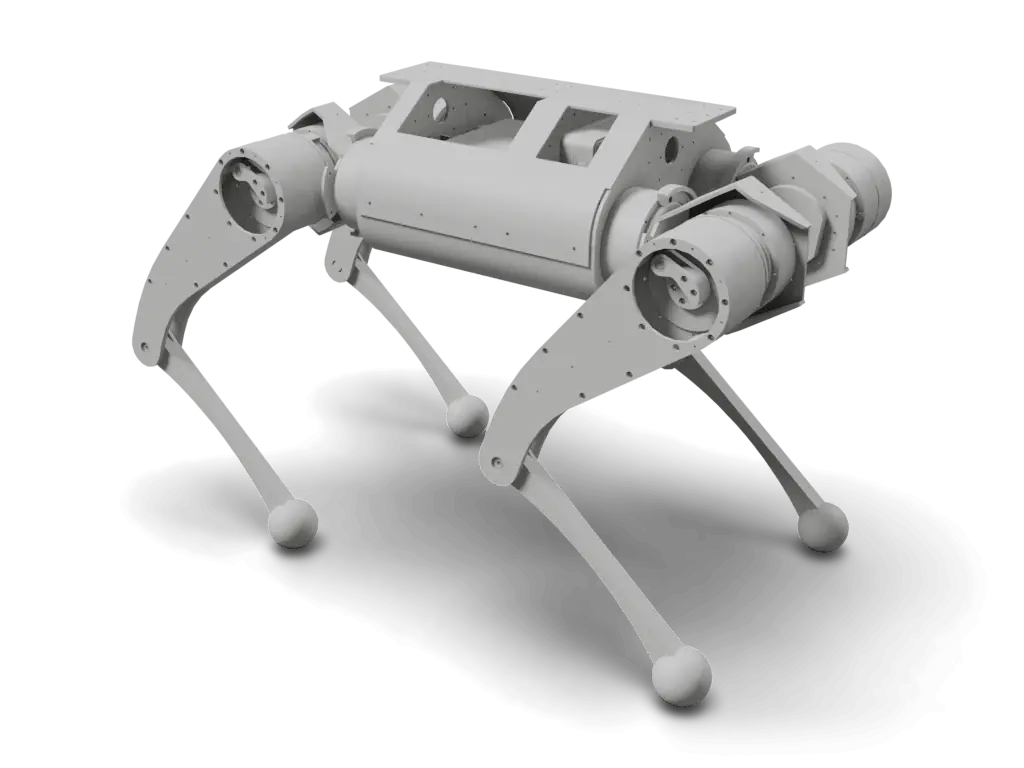
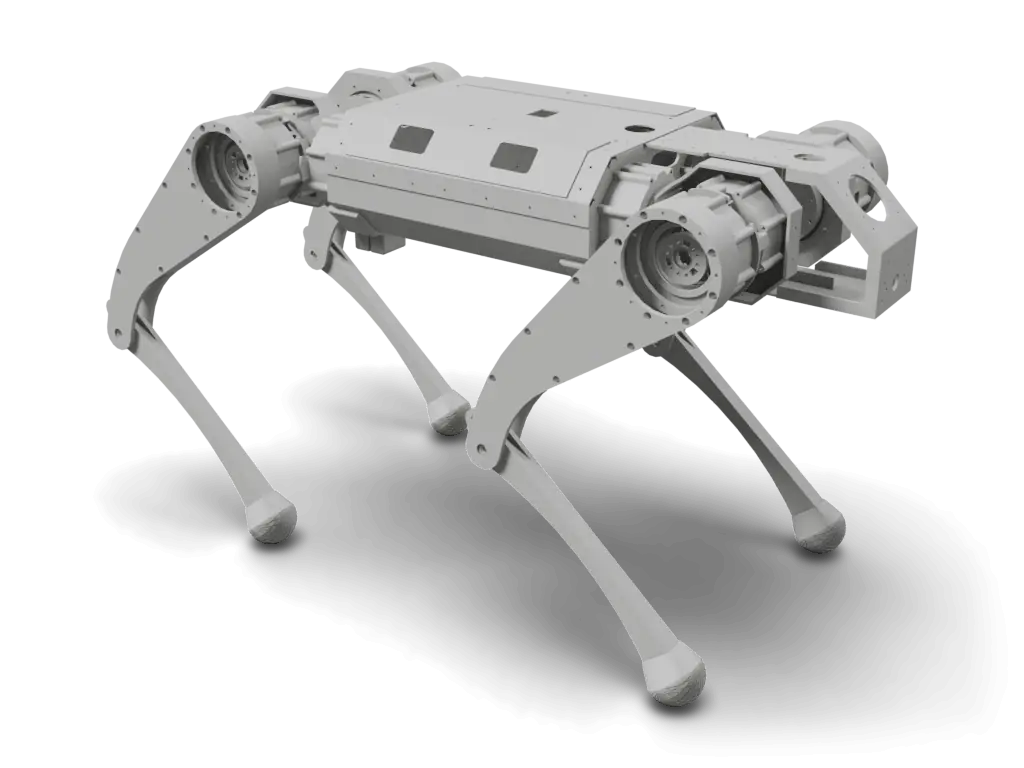
An open, torque-controlled Solo-family quadruped from the Open Dynamic Robot Initiative (ODRI). The 3D view comes from the robot_properties_solo description; the actuator, electronics, wiring and body build documentation lives in the separate ODRI hardware repository.
Licenses
- Hardware
- BSD-3-Clause
- Software
- Not published
- Docs
- Not published
Degrees of freedom
12 DoF legs 12
Quadrupedsource
Claimed by maintainer
Source record
- Sources
- open-dynamic-robot-initiative/open_robot_actuator_hardware@66af152
- open-dynamic-robot-initiative/robot_properties_solo@2201f45
- open-dynamic-robot-initiative/master-board@574fe98
- HW license
- BSD-3-Clause
- Cost
- not published
- Lifecycle
- Dormant
- Engine
- v3.1.1
- Checked
- Model
- solo12.urdf.xacro@2201f45rendered 2026-06-08
- Envelope
- 467 × 295 × 304 mmas modelled, default pose
Claimed by a GitHub contributor of the project. Maintainer dashboard
Parts and cost
Cost to build
The sources do not publish a cost total. The rows below are what they list, without a sum.
Solo-12 parts, as the source lists them (read 2026-06-06). Prices are the source's, not checked against vendors.
| Part | Qty | Spec | Source | Confidence |
|---|---|---|---|---|
3DOF leg modulefour identical Solo-12 leg modules | 4 | 3 active degrees of freedom per leg | self-build / ODRI docsprice not listedODRI hardware README describes the robot as a body module plus four identical 3DOF legs | high |
Master Board v2central controller/electronics board | 1 | custom electronics; Ethernet/control hub | make yourself / ODRI master-boardprice not listedODRI hardware BOM lists one Master Board v2 and links master-board docs | high |
Micro Driver Board v2motor driver stacks for the quadruped | 6 | custom micro driver electronics | make yourself / ODRI micro driverprice not listedODRI hardware BOM lists six Micro Driver Board v2 units | high |
Lord Microstrain 3DM-CX5-25 IMUinertial measurement unit | 1 | extended measurement range; +/-900 deg/s gyro, +/-20G accelerometer | Lord Microstrainprice not listedODRI hardware README lists the 3DM-CX5-25 IMU and measurement range | high |
3D-printed body structure setbody plates, supports, covers, spacers | 1 | printed body module parts from hardware README STL links | 3D print yourself / service printprice not listedODRI hardware BOM itemizes body structure printed parts and STL links | high |
Bearings, fasteners, helicoils, Vicon markersoff-the-shelf hardware for assembly and tracking | 1 | Hip AA bearings, stainless fasteners, thread inserts, markers | listed vendors / genericnot totaled in source BOMODRI hardware BOM lists bearings, fasteners, helicoils, and Vicon markers with ordering links | high |
URDF/STL visual assembly assetsrendered catalog primary assembly | 1 | solo12 xacro plus 9 unique STL visual meshes | source repositorysource assets includedThe 3D model uses 11 files from robot_properties_solo at commit 2201f45 | high |
Rows from the source's own parts list 7
mechanics/quadruped_robot_12dof_v1/README.md@66af152markdown
| Source row | Qty | Price and vendor | Line |
|---|---|---|---|
3DOF Leg | 4 | github.comno price listed | L197 |
Master Board v2 | 1 | github.comno price listed | L198 |
Micro Driver Board v2 | 6 | github.comno price listed | L199 |
Inertia Measurement Unit | 1 | microstrain.comgithub.comno price listed | L200 |
Body structure printed parts | 1 set | github.comno price listed | L201 |
Bearings, fasteners, helicoils, Vicon markers | assorted | github.comno price listed | L214 |
src/robot_properties_solo/resources/xacro/solo12.urdf.xacro@2201f45xacro
| Source row | Qty | Price and vendor | Line |
|---|---|---|---|
Solo-12 primary assembly xacro | 1 | github.comsource assets included | L14 |
How to build
Steps marked Motari summary condense the linked source; follow the source for exact instructions.
Assemble the actuator modules
Build the 12 actuator modules (3 per leg) from the actuator module BOM: brushless motor, one optical encoder with codewheel, 9:1 dual-stage timing belt transmission, machined motor shaft and pulleys, and 3D printed pulleys and shells.
Motari summaryarxiv.org/abs/1910.00093Fabricate the boards
Order the six MicroDriver boards and the Master Board assembled, solder the remaining resistors and connectors, then flash the MicroDrivers with a JTAG emulator and the Master Board with ESP-IDF.
Motari summaryarxiv.org/abs/1910.00093Print the legs and body
Print the leg shells and body structure (SLS or FDM) and the pulleys and codewheel mounts (SLA or Multijet), install Helicoil inserts, and glue a strip of bicycle tire to each printed lower leg foot.
Motari summaryarxiv.org/abs/1910.00093Wire the SPI bus
Connect each of the six MicroDriver boards to its own SPI connector on the Master Board, then route the motor phase, encoder, power and SPI wires as shown on the Solo12 wiring page.
Motari summaryarxiv.org/abs/1910.00093Bring up and calibrate
Align the legs with the 3D printed calibration tools and save each joint's offset from its encoder index, then run the robot through the Master Board SDK.
Motari summaryarxiv.org/abs/1910.00093
Wiring, power and firmware are safety-relevant and shown for reference only. Check them against the source before building.
metCAD / mesh present69 editable CAD files (SLDASM/SLDPRT) for 64 parts (69 inside archives), including an assembly + 26 mesh files20/20
partialBOM evidencemechanics/quadruped_robot_12dof_v1/README.md table (Bill of Materials - Quadruped Robot 12dof): 27 line items, quantities10/20
Quality tier 2 of 5
metWiring diagramschematic or PCB source files (4 files, brd/sch)15/15
Quality tier 3 of 3
metFirmware linkedfirmware source in the repo10/10
Quality tier 3 of 3
- firmware/Makefile574fe98
- firmware/sdkconfig574fe98
- firmware/main/defines.h574fe98
- sdk/master_board_sdk/package.xml574fe98
metBuild instructionsReviewedODRI docs give photo step-by-step guides for building the actuator modules, linked from the Solo 12 and leg pages; the engine only read the quadruped folder, which holds none.15/15
Quality tier 2 of 3
Reviewed override, 2026-09-30
Evidence on github.comEngine alone: missing at tier 0 (no build instructions found)
metOSHW-compatible licenseBSD-3-Clause (from repository license)10/10
Quality tier 2 of 2
- LICENSE66af152
missingKnown reproductionsno verified builds yet0/10
Quality tier 0 of 2
Only build reports a maintainer or admin has reviewed count here.
Engine v3.1.1 at 66af152, 1 item reviewed by hand
How this score is computedFiles and sim
- src/robot_properties_solo/resources/xacro/leg.xacro
- src/robot_properties_solo/resources/xacro/solo12.urdf.xacro
- src/robot_properties_solo/resources/xacro/solo8.urdf.xacro
- src/robot_properties_solo/resources/meshes/obj/with_foot/solo_body.obj
- src/robot_properties_solo/resources/meshes/obj/without_foot/solo_body.obj
- src/robot_properties_solo/resources/meshes/stl/with_foot/solo_body.stl
- src/robot_properties_solo/resources/rviz/dgbullet_vs_pybullet.rviz
- src/robot_properties_solo/resources/rviz/solo.rviz
- src/robot_properties_solo/resources/rviz/display.rviz
- src/robot_properties_solo/resources/meshes/stl/solo12/_solo12_visualisation_model.PDF
- license.txt
- readme.md
Files stay in the upstream repository under their own licenses; these links open them there. The 3D model on this page is Motari's conversion of the file named under Simulation.
Simulation
Robot description files a simulator or CAD tool can load, linked at the commit they were found.
- URDFsrc/robot_properties_solo/resources/xacro/solo12.urdf.xacroopen-dynamic-robot-initiative/robot_properties_solo
The 3D specimen on this page is converted from src/robot_properties_solo/resources/xacro/solo12.urdf.xacro at 2201f45.
Builds
No reviewed builds of Solo-12 yet.
A build log records the evidence (photos, a video, your repository), what the build cost, how long it took and what you changed. Each one is checked by the maintainer before it shows here, and reviewed builds count toward the reproducibility score.
Sources
Where the facts come from
- Hardwaregithub.com/open-dynamic-robot-initiative/open_robot_actuator...66af152
- Simulationgithub.com/open-dynamic-robot-initiative/robot_properties_solo2201f45
- Hardwaregithub.com/open-dynamic-robot-initiative/master-board574fe98
- Documentationarxiv.org/abs/1910.00093
Last push to open-dynamic-robot-initiative/robot_properties_solo: 2023-03-22 (checked 2026-10-01)
Related links
- robot_interfaces driverrobot_interfaces_solo (Solo12 driver)
- Demo scriptsdisplay and simulate scripts
- Forks and variantsGitHub network
How this page was made
First assembled from public sources on 2026-05-12 and now claimed by a GitHub contributor of the project. Each figure links to where it is stated; a value the sources do not state reads "not published". The fields were read from public sources and have not been re-checked against the live repository.
Original files stay intact and separately licensed; Motari adds only the summary on this page. Maintainer? Request a correction or removal.
Robots like Solo-12
None of the parts in this bill of materials is tracked across robots yet. See the parts robots have in common.
Similar robots
The same type of robot, closest first by body plan, published cost and degrees of freedom. All legged robots
Badge for the README
Maintain Solo-12? Show its reproducibility score in the project's README. The badge links back to this page and updates with the score.

[](https://motari.io/r/solo-12)<a href="https://motari.io/r/solo-12"><img src="https://motari.io/api/v1/badge/solo-12" alt="Motari reproducibility score for Solo-12" height="20"></a>Not fully met yet: bom evidence (partial). The score is read from the project's own sources, so publishing what is missing is what raises it. A score of 90 or more needs a reviewed build. How the score is computed