Build your first robot arm
SO-101: 6 DoF, $122 in parts (follower arm), reproducibility 83
View the build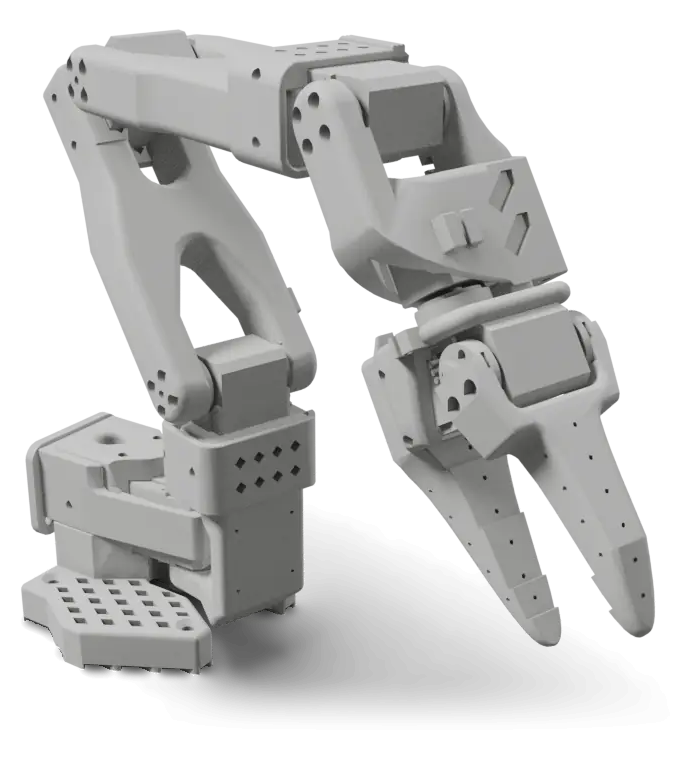
Good first builds
Browse every robot
Search and filter all 103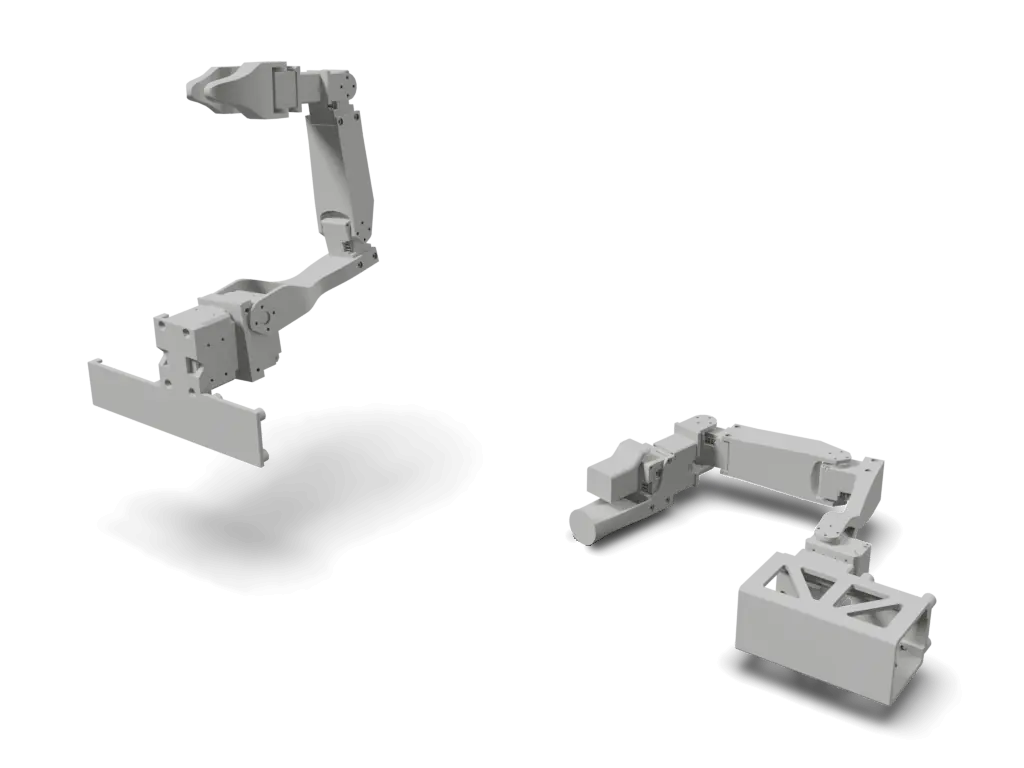 Koch v1.16 DoF · $477
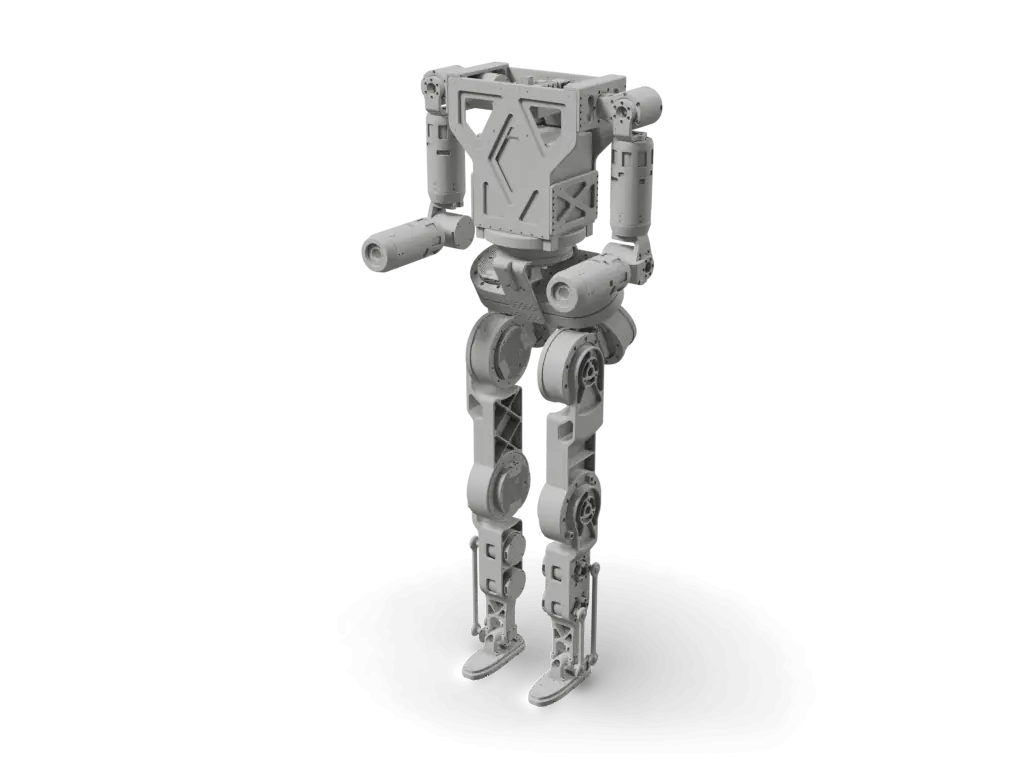 Roboto Origin23 DoF · CN¥50k
 Sesame8 DoF · $55
 SSG-48 Adaptive Electric Gripper1 DoF · €774
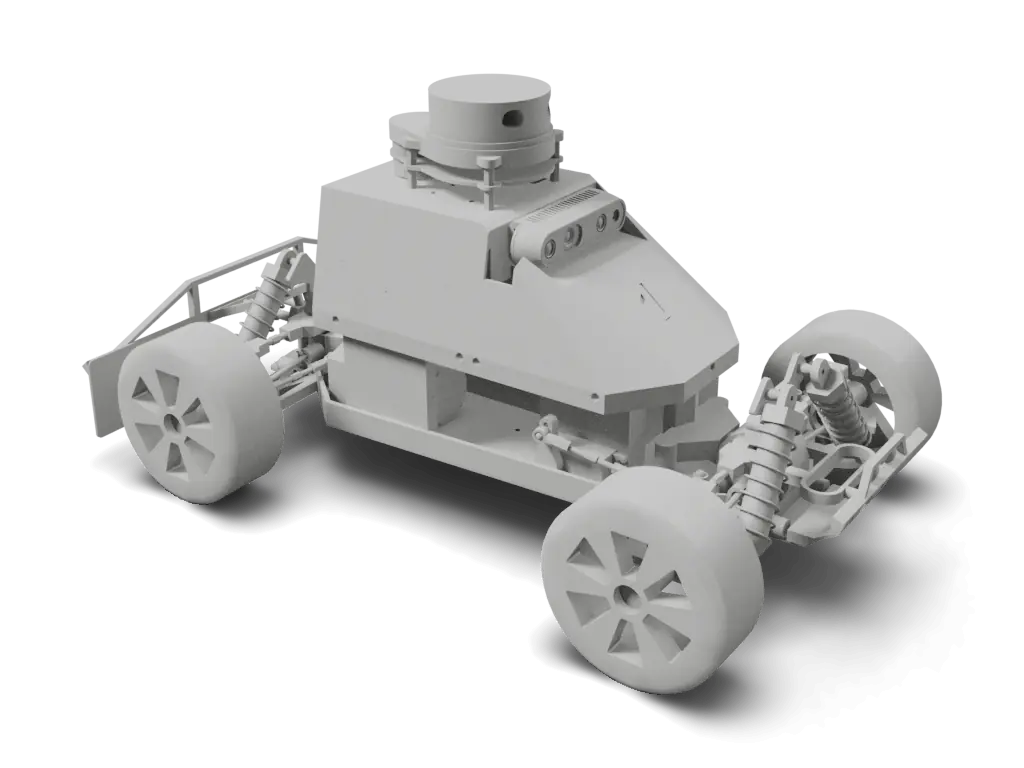
 JPL Open Source Rover10 DoF · $1.3k
 CogniFly4 DoF · CA$408
 OpenArm8 DoF
 Asimov 125 DoF · $20k
 ODRI Open Robot Actuator Hardware (Solo / Bolt)12 DoF
 Amazing Hand Enhanced8 DoF · €287
 NVIDIA JetBot2 DoF · $629
 Flix4 DoF
 Seeed reBot-DevArm7 DoF
 Berkeley Humanoid Lite24 DoF · $4.3k
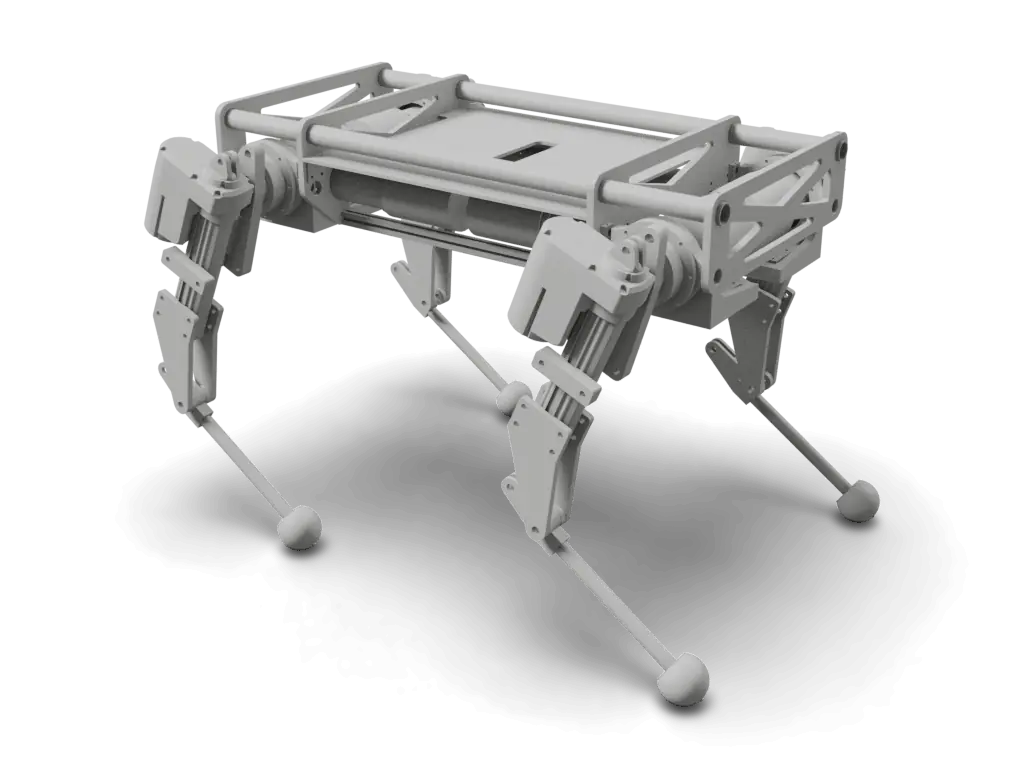 POPI12 DoF · €5.1k
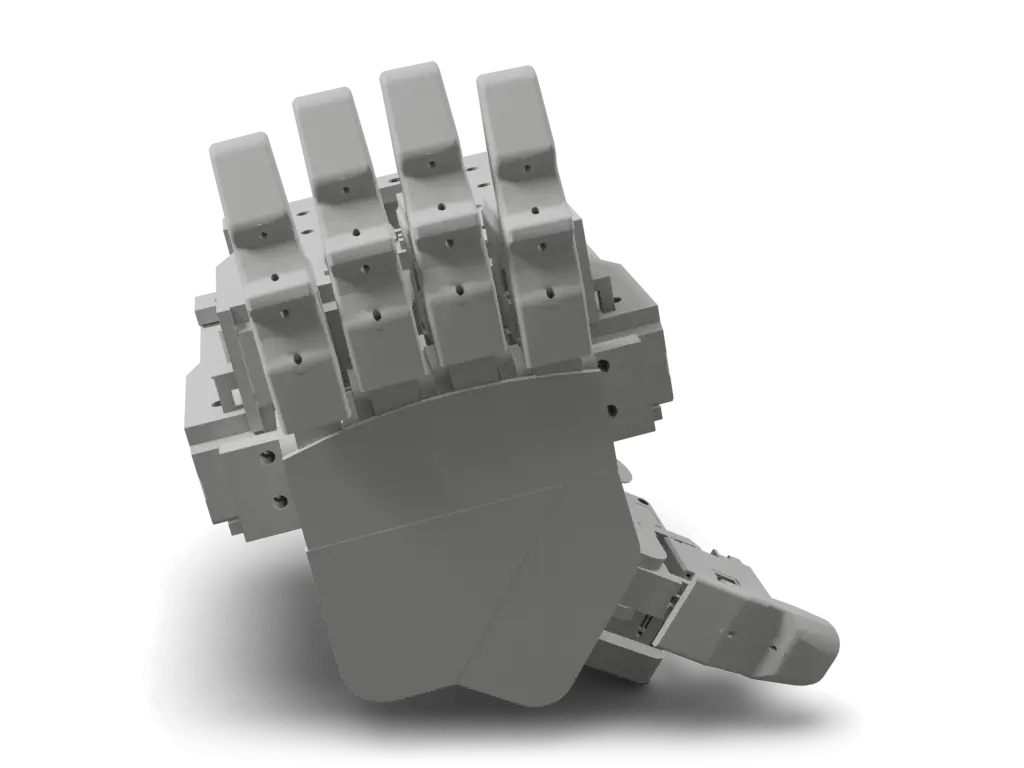 LEAP Hand v2 Advanced17 DoF · $4.1k
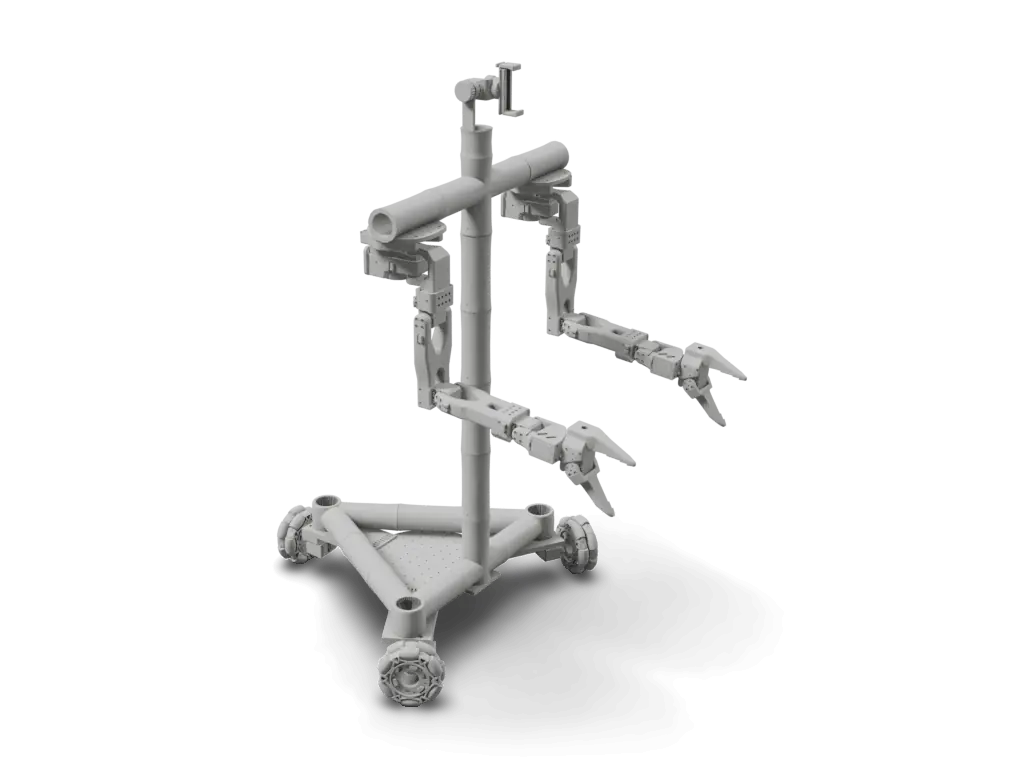
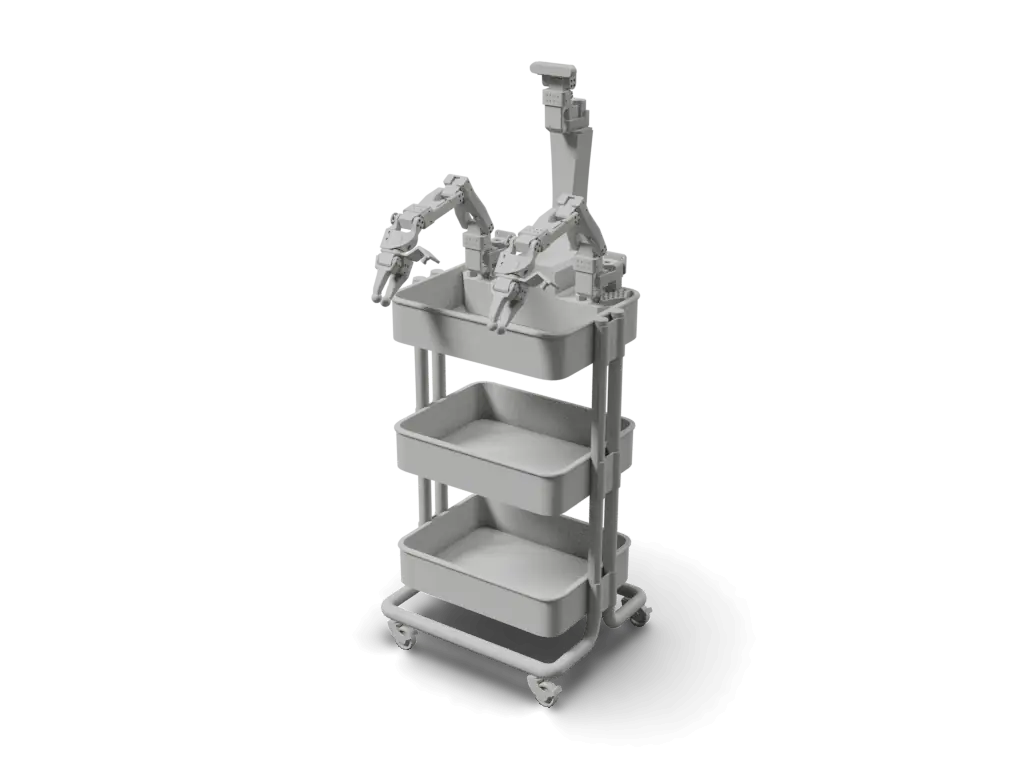 XLeRobot16 DoF · $660
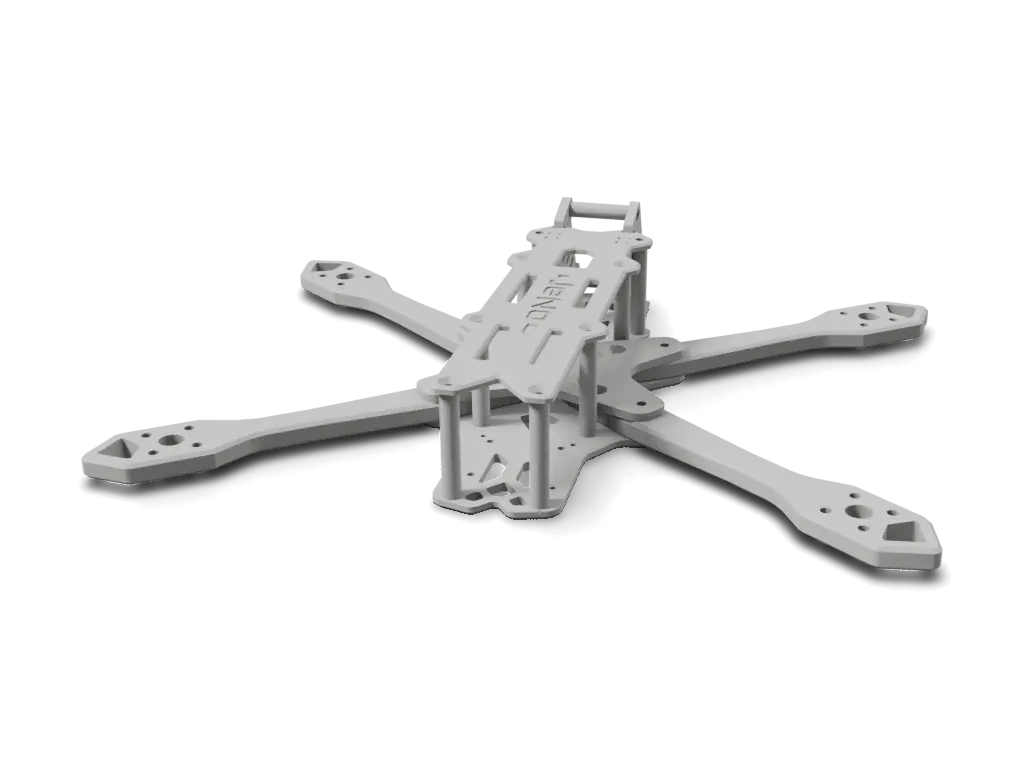 JeNo 5.14 DoF · €63
- Koch v1.16 DoF · $477
- OpenArm8 DoF
- Seeed reBot-DevArm7 DoF
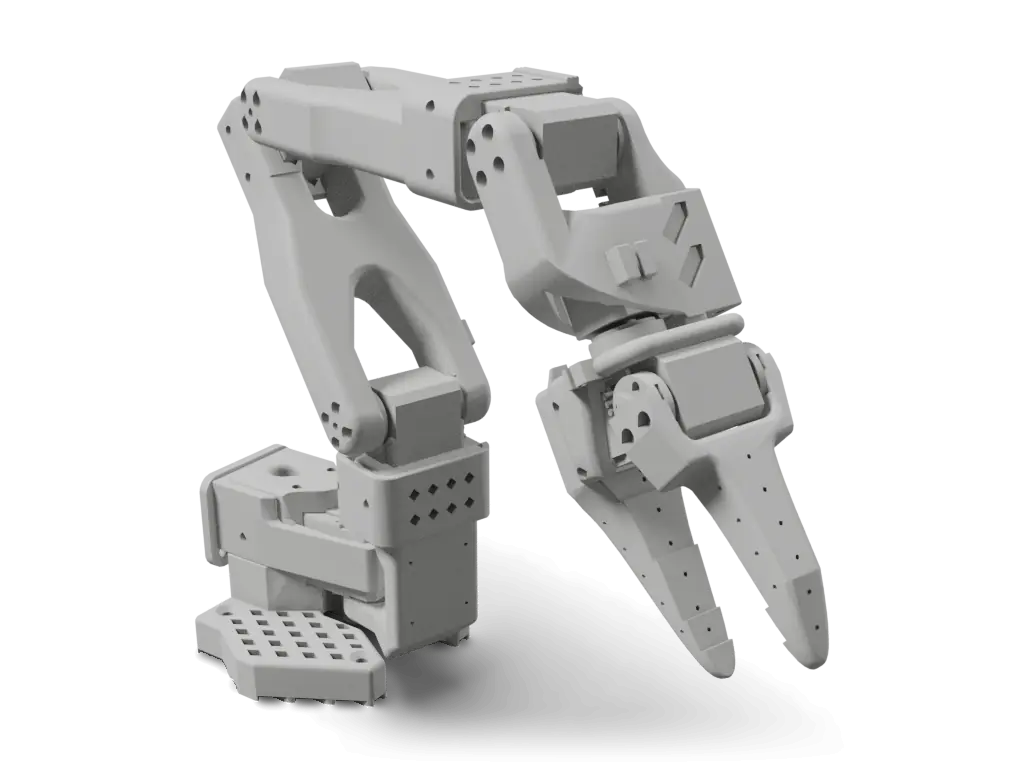 SO-1016 DoF · $122
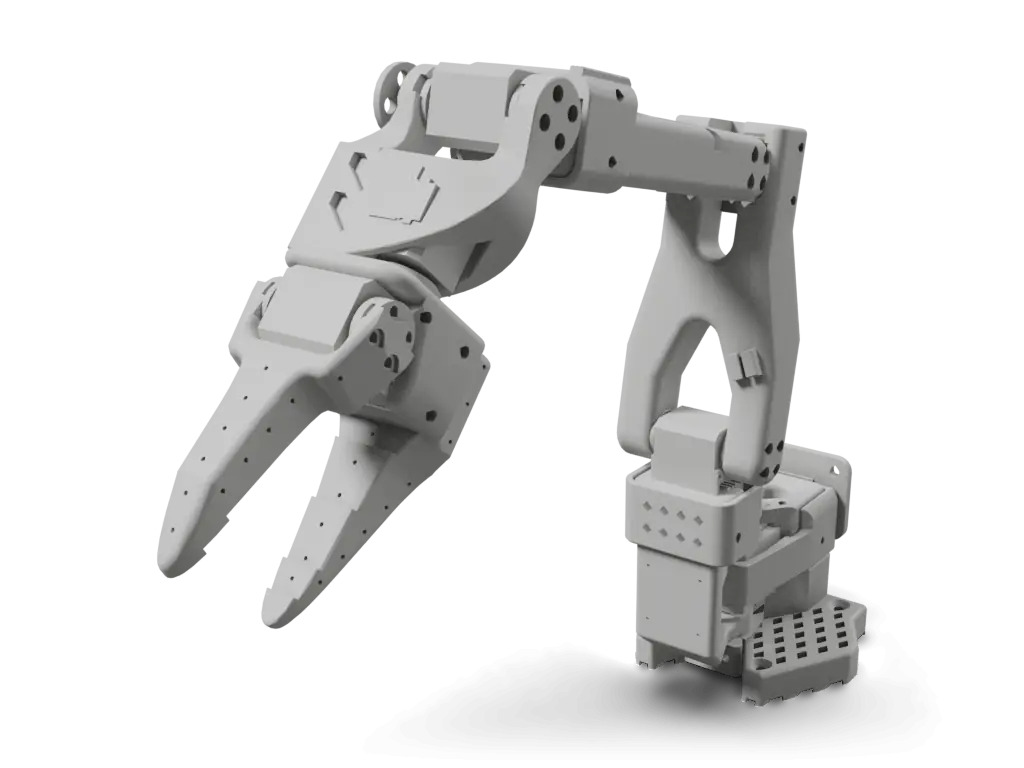 SO-ARM100 / SO-ARM101 (Standard Open Arm)6 DoF · $123
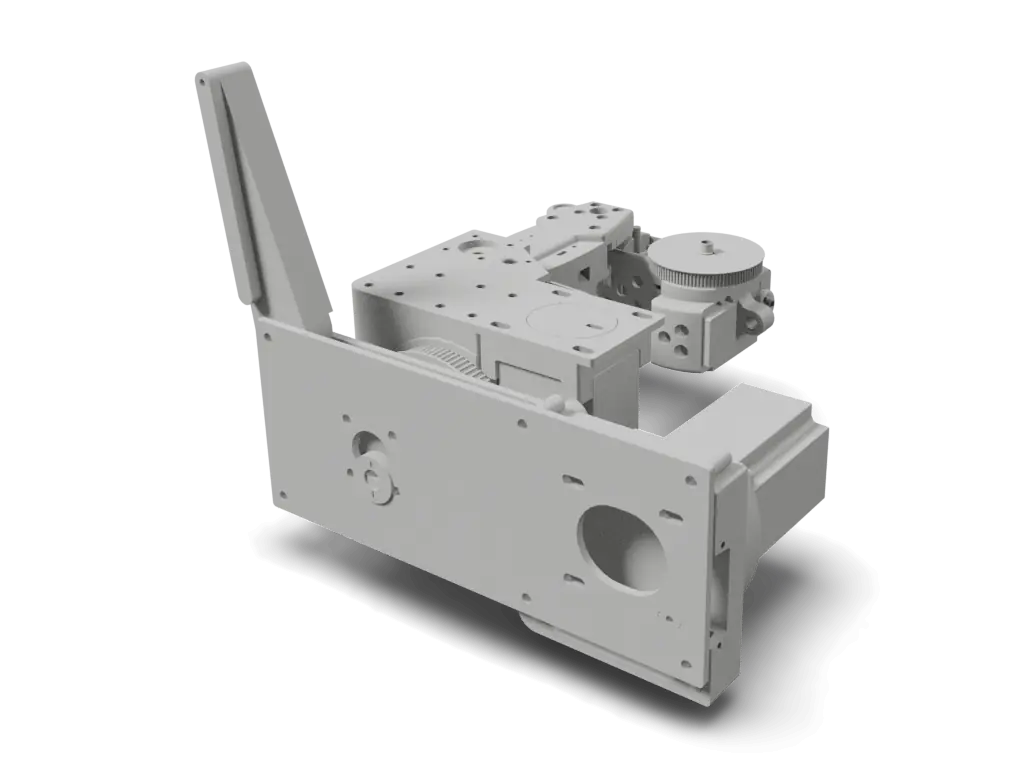 SmallRobotArm (Skyentific)6 DoF
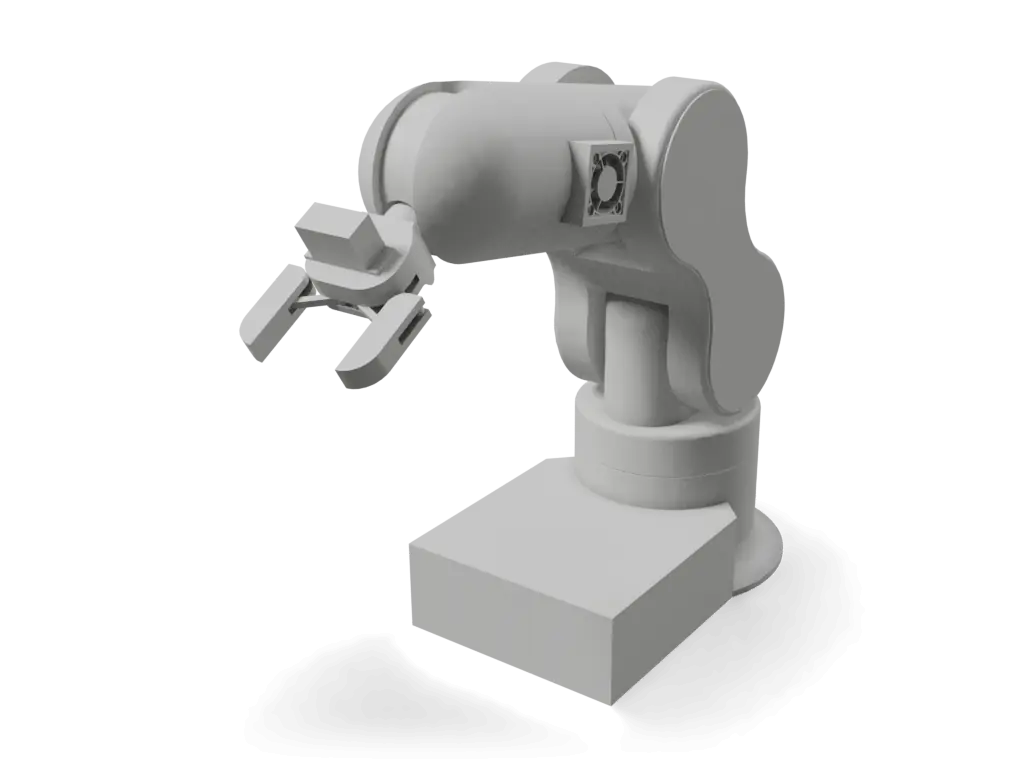 Thor6 DoF · €350
 Seeed reCamera Gimbal2 DoF
 GELLO7 DoF · $272
 PAROL6 Desktop Robot Arm6 DoF · €2.4k
 PingTi Arm6 DoF · $261
 Faze4 Robotic arm6 DoF · $1k
- Roboto Origin23 DoF · CN¥50k
- Asimov 125 DoF · $20k
- Berkeley Humanoid Lite24 DoF · $4.3k
 Poppy Humanoid25 DoF · $8.5k
 MEVITA10 DoF · $12k
 ToddlerBot30 DoF · $5.7k
 Legolas (open-source biped)10 DoF
 ElectronBot6 DoF
 Open Duck Mini16 DoF · €398
 pib (printable intelligent bot)26 DoF · €3.1k
 InMoov30 DoF
 HOPEJr66 DoF · $3k
- Sesame8 DoF · $55
- ODRI Open Robot Actuator Hardware (Solo / Bolt)12 DoF
- POPI12 DoF · €5.1k
 Q8bot8 DoF · $337
 Solo-1212 DoF
 Bob The Hexapod18 DoF
 MEVIUS12 DoF · $12k
 MEVIUS212 DoF · $13k
 Stanford Pupper v312 DoF · $2k
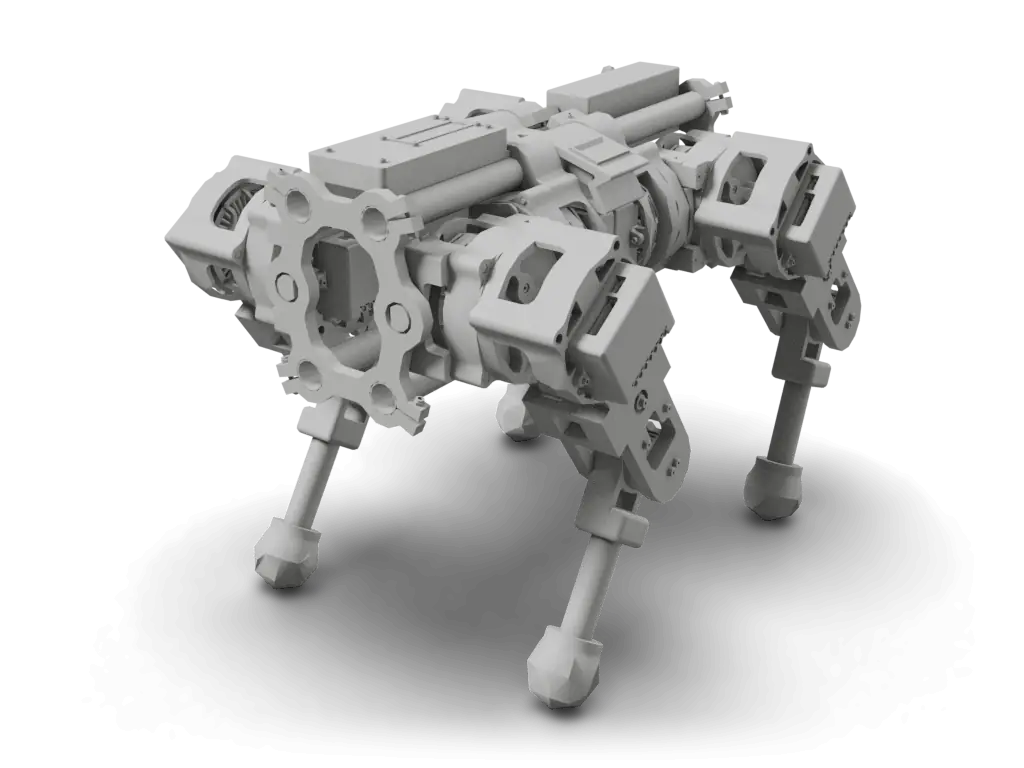 TOPS12 DoF · $3.3k
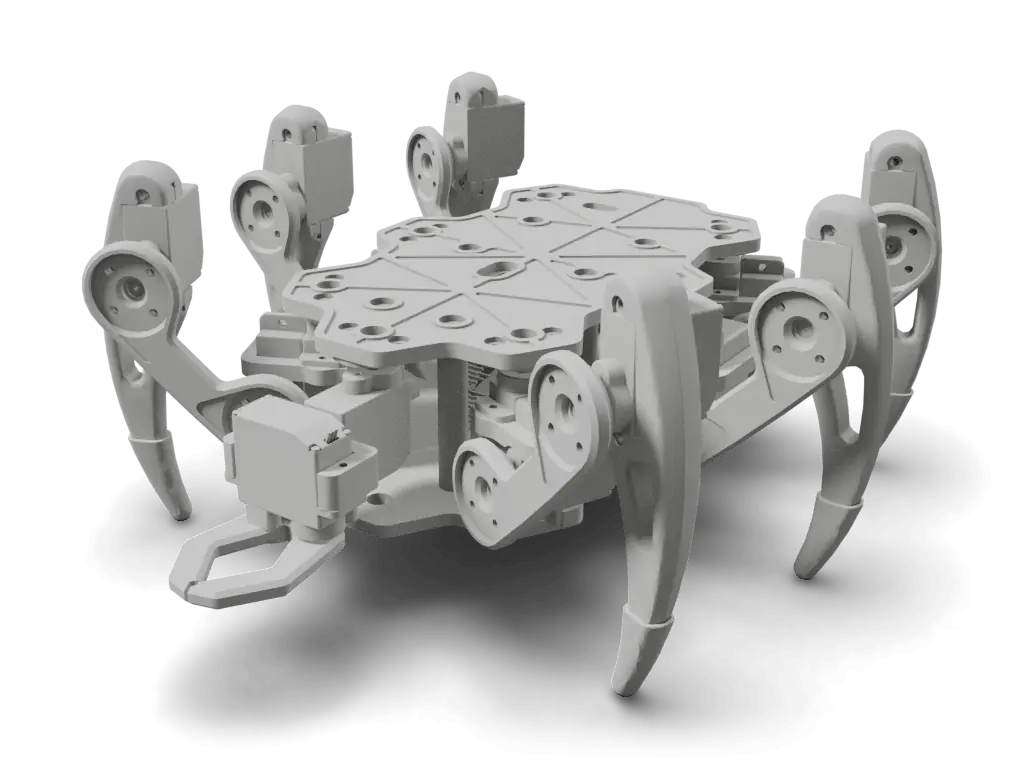 ZeroBug18 DoF
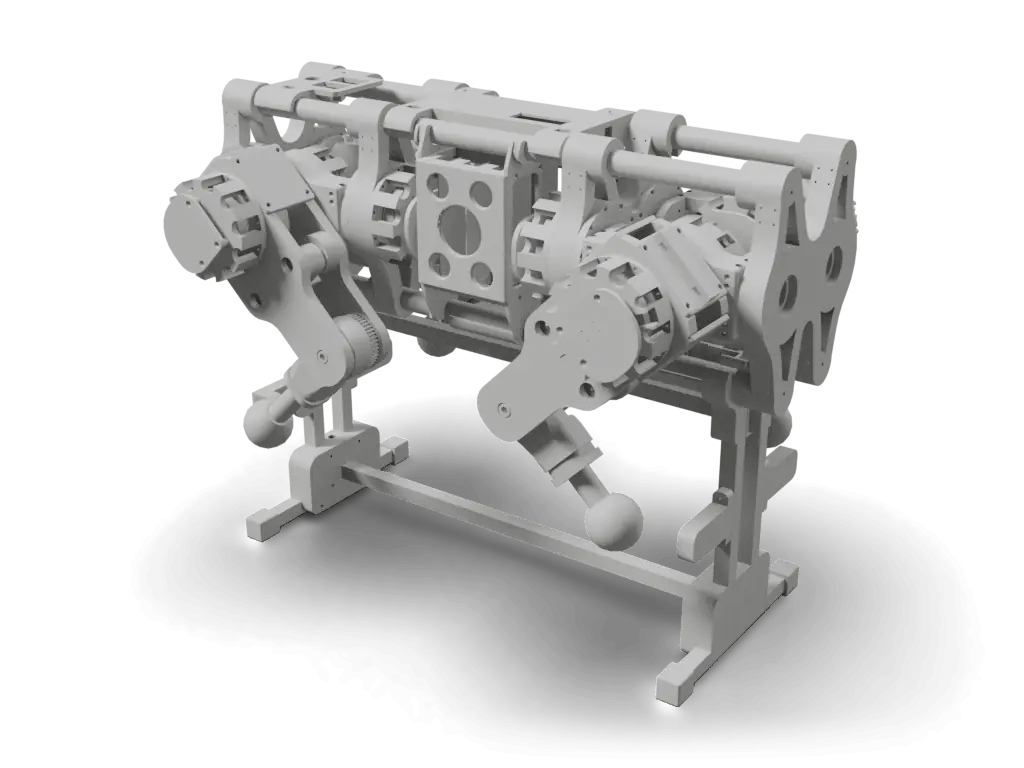 openDog V312 DoF
- SSG-48 Adaptive Electric Gripper1 DoF · €774
- Amazing Hand Enhanced8 DoF · €287
- LEAP Hand v2 Advanced17 DoF · $4.1k
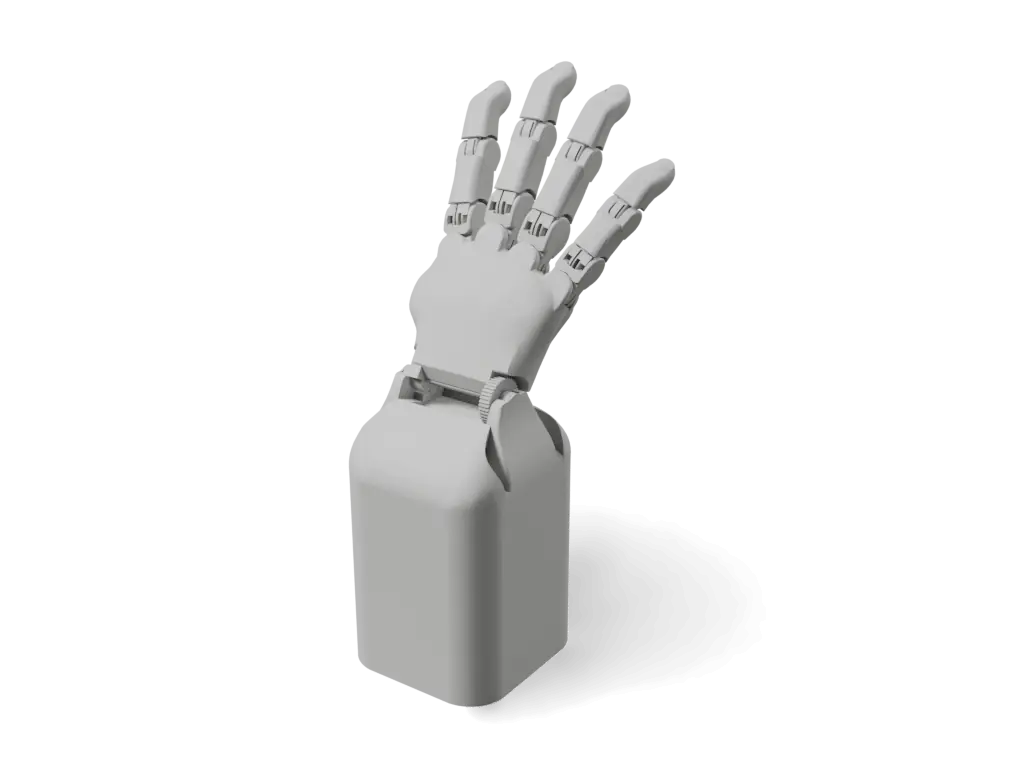 ORCA Hand17 DoF · $2.4k
 Aero Hand Open7 DoF · $316
 Amazing Hand8 DoF · €128
 Actuated UMI Gripper1 DoF
 LEAP Hand16 DoF · $1.8k
 RUKA Hand11 DoF · $520
 PincOpen1 DoF · €26
Most reproducible robots
How the score works- Rank 1JPL Open Source Rover89 / 100
- Rank 1Koch v1.189 / 100
- Rank 1NVIDIA JetBot89 / 100
- Rank 1OpenArm89 / 100
- Rank 1Roboto Origin89 / 100
Robots with the same score share a rank and are listed by name. Until someone's build of a robot has been reviewed, its score stops at 89.
Start from a question
Parts robots share
Read from the robots' bills of materials: how many robots list each part.
How the atlas is built
Read the source. Each robot starts from its public repository, pinned to a commit, and the README, bill of materials and build guides it publishes.
Render and extract. The 3D model is rendered from the project's own files; parts, costs and licenses are copied with a link to where each one is stated.
Score and link out. A published rubric scores how complete the build documentation is. Code stays on GitHub, models and datasets on Hugging Face.
103 robots indexed · 96 3D models rendered from source files · 65 with a sourced cost · 117k GitHub stars across their repositories · 2026-10-02 last re-verified against sources. More on how the data is gathered and checked and how the score works.