
Berkeley Humanoid Lite
Sub-$5k open-source humanoid with modular 3D-printed cycloidal gearboxes.
- $4,312 in partsfull humanoid incl. 22 actuators, 2 grippers, compute, battery (US prices), source total
- 24 DoF
- CC-BY-SA-4.0hardware
- 80 / 100 reproducibilityStrong source coverage, unverified
What it is
Berkeley Humanoid Lite is an open-source, sub-$5,000 humanoid robot built around modular, fully 3D-printed cycloidal gearbox actuators and widely available off-the-shelf parts. Standing roughly 0.8 m and weighing about 16 kg, it is designed to democratize humanoid robotics research. The repo ships the IsaacLab training environment, sim2sim/sim2real deployment code, low-level robot code, and robot descriptions (URDF, MJCF, USD) exported from an Onshape project; CAD and 3D-print files are published via the documentation releases.
Licenses
- Hardware
- CC-BY-SA-4.0
- Software
- MIT
- Docs
- Not published
Degrees of freedom
24 DoF arms 10legs 12grippers 2
Humanoidsource
Auto-assembled, not yet reviewed
Source record
- Sources
- HybridRobotics/berkeley-humanoid-lite@984741a
- HybridRobotics/berkeley-humanoid-lite-assets@fc90fed
- T-K-233/Recoil-Motor-Controller-BESC@3571ab6
- HW license
- CC-BY-SA-4.0
- Cost
- $4,312source total, full humanoid incl. 22 actuators, 2 grippers, compute, battery (US prices)
- Lifecycle
- Active
- Engine
- v3.1.1
- Checked
- Model
- berkeley_humanoid_lite.urdf@fc90fedrendered 2026-09-30
- Envelope
- 270 × 790 × 597 mmas modelled, default pose
Maintain Berkeley Humanoid Lite? Claim this page to correct it.
Parts and cost
Cost to build
- full humanoid incl. 22 actuators, 2 grippers, compute, battery (US prices)
In the source currency, as read on 2026-09-30. Not converted, and not checked against current vendor prices: none of these is a Motari-verified checkout total.
Berkeley Humanoid Lite parts, as the source lists them. Prices are the source's, not checked against vendors.
| Part | Qty | Spec | Source | Confidence |
|---|---|---|---|---|
6512 actuator setlarge 3D-printed cycloidal actuators | 10 | M6C12 BLDC motor, B-G431B-ESC1 driver, AS5600 encoder, bearings, fasteners, 3D printed parts, cables and connectors per Table I | online marketplaces / Digikey / Mouser$1,880 US totalDemonstrating Berkeley Humanoid Lite paper, Table I and Table III | high |
5010 actuator setsmall 3D-printed cycloidal actuators | 12 | 5010 BLDC motor, B-G431B-ESC1 driver, AS5600 encoder, bearings, fasteners, 3D printed parts, cables and connectors per Table II | online marketplaces / Digikey / Mouser$1,632 US totalDemonstrating Berkeley Humanoid Lite paper, Table II and Table III | high |
Compute, IMU, power and CAN electronicscontroller, bus adapters, hub, sensing and battery | 1 | Mini PC, USB-CAN adapters x4, USB hubs x2, BNO085 IMU, 6S LiPo battery | online marketplaces / electronics suppliers$316 US subtotalDemonstrating Berkeley Humanoid Lite paper, Table III | high |
Structure, grippers and miscellaneous hardwareprinted and off-the-shelf robot body components | 1 | grippers x2, aluminum extrusions, 3D printed components, miscellaneous structural components and miscellaneous electronic components | 3D print yourself / online marketplaces$484 US subtotalDemonstrating Berkeley Humanoid Lite paper, Table III | high |
Rows from the source's own parts list 3
demonstrating-berkeley-humanoid-lite.pdfpdf
| Source row | Qty | Price and vendor | Line |
|---|---|---|---|
Berkeley Humanoid Lite source cost scope | lite.berkeley-humanoid.orgberkeley-humanoid-lite.gitbook.iounder $5,000 source-reported hardware cost | L18 | |
6512 and 5010 actuator BOM tables | 6512 actuators x10; 5010 actuators x12 | lite.berkeley-humanoid.org$1,880 US + $1,632 US | L229 |
Robot-level BOM table | one assembled humanoid robot | lite.berkeley-humanoid.org$4,312 US table total | L318 |
How to build
Steps marked Motari summary condense the linked source; follow the source for exact instructions. Upstream step marks a step taken from the linked guide.
Get CAD and print files
Download the latest CAD model and 3D-print files from the GitBook Releases page.
Upstream stepberkeley-humanoid-lite.gitbook.io/docs/getting-started-with-...Print gearboxes and frame
FDM-print the modular cycloidal gearboxes and all PLA structural parts.
Motari summaryberkeley-humanoid-lite.gitbook.io/docsAssemble the actuators
Build the self-contained actuators and bolt up the modular joints per the hardware docs.
Motari summaryberkeley-humanoid-lite.gitbook.io/docsWire and flash low-level
Flash the Recoil motor controller firmware onto each B-G431B-ESC1, set each CAN ID per the joint ID mapping page, calibrate each actuator over a USB-CAN adapter, then wire the CAN buses and power per the wiring diagram and run the lowlevel code on the onboard computer.
Motari summaryberkeley-humanoid-lite.gitbook.io/docsTrain and deploy policy
Use the IsaacLab environment for policy training, then sim2sim validate and deploy to hardware.
Upstream stepberkeley-humanoid-lite.gitbook.io/docs/getting-started-with-...
Wiring, power and firmware are safety-relevant and shown for reference only. Check them against the source before building.
metCAD / mesh presentReviewedPublic Onshape document 'Berkeley Humanoid Lite Release' holds the editable part studios and assemblies of the whole robot, linked from the docs Releases page; the engine does not open Onshape.20/20
Quality tier 3 of 3
Reviewed override, 2026-09-30
Evidence on cad.onshape.comEngine alone: partial at tier 2 (Onshape CAD linked, not inspected by the engine; no editable CAD source in the repo)
partialBOM evidenceBOM spreadsheet linked, not inspected by the engine10/20
Quality tier 1 of 5
metWiring diagramReviewedGitBook 'Building the Robot' page has a full-robot wiring diagram (battery, breaker, USB hub, 4 USB-CAN adapters, 22 motor controllers, IMU); the engine does not read GitBook.15/15
Quality tier 2 of 3
Reviewed override, 2026-09-30
Evidence on berkeley-humanoid-lite.gitbook.ioEngine alone: missing at tier 0 (no wiring diagram found)
metFirmware linkedfirmware source in the repo10/10
metBuild instructionsReviewedGitBook build pages give photo steps (actuator prep, soldering, CAN and power cabling) plus assembly videos for the actuator, arm, leg and body; the engine does not read GitBook.15/15
Quality tier 3 of 3
Reviewed override, 2026-09-30
Evidence on berkeley-humanoid-lite.gitbook.ioEngine alone: partial at tier 1 (external build guide linked, not inspected by the engine)
metOSHW-compatible licenseReviewedThe project's robot asset repository is licensed CC BY-SA 4.0 and the main README puts all non-code assets under CC BY-SA 4.0; the engine found no hardware license since the CAD is on Onshape.10/10
Quality tier 2 of 2
Reviewed override, 2026-09-30
Evidence on github.comEngine alone: missing at tier 0 (no hardware license detected)
missingKnown reproductionsno verified builds yet0/10
Quality tier 0 of 2
Only build reports a maintainer or admin has reviewed count here.
Engine v3.1.1 at 984741a, 4 items reviewed by hand
- The engine found no license file for the hardware in the hardware source.
Files and sim
- data/robots/berkeley_humanoid/berkeley_humanoid_lite/urdf/berkeley_humanoid_lite.urdf
- data/robots/berkeley_humanoid/berkeley_humanoid_lite/mjcf/berkeley_humanoid_lite.xml
- data/robots/berkeley_humanoid/berkeley_humanoid_lite/meshes/base_visual.stl
- data/robots/berkeley_humanoid/berkeley_humanoid_lite/meshes/leg_left_hip_pitch_visual.stl
- scripts/teleop/check_connection.py
- pyproject.toml
- configs/policy_humanoid.yaml
- configs/policy_humanoid_legs.yaml
- README.md
- requirements.txt
Files stay in the upstream repository under their own licenses; these links open them there. The 3D model on this page is Motari's conversion of the file named under Simulation.
Simulation
Robot description files a simulator or CAD tool can load, linked at the commit they were found.
- URDFdata/robots/berkeley_humanoid/berkeley_humanoid_lite/urdf/berkeley_humanoid_lite.urdfHybridRobotics/Berkeley-Humanoid-Lite-Assets
- MJCF (MuJoCo)data/robots/berkeley_humanoid/berkeley_humanoid_lite/mjcf/berkeley_humanoid_lite.xmlHybridRobotics/Berkeley-Humanoid-Lite-Assets
- Onshapecad.onshape.com/documents/fc6443b1d89dcba950e85b60/w/94a2647...
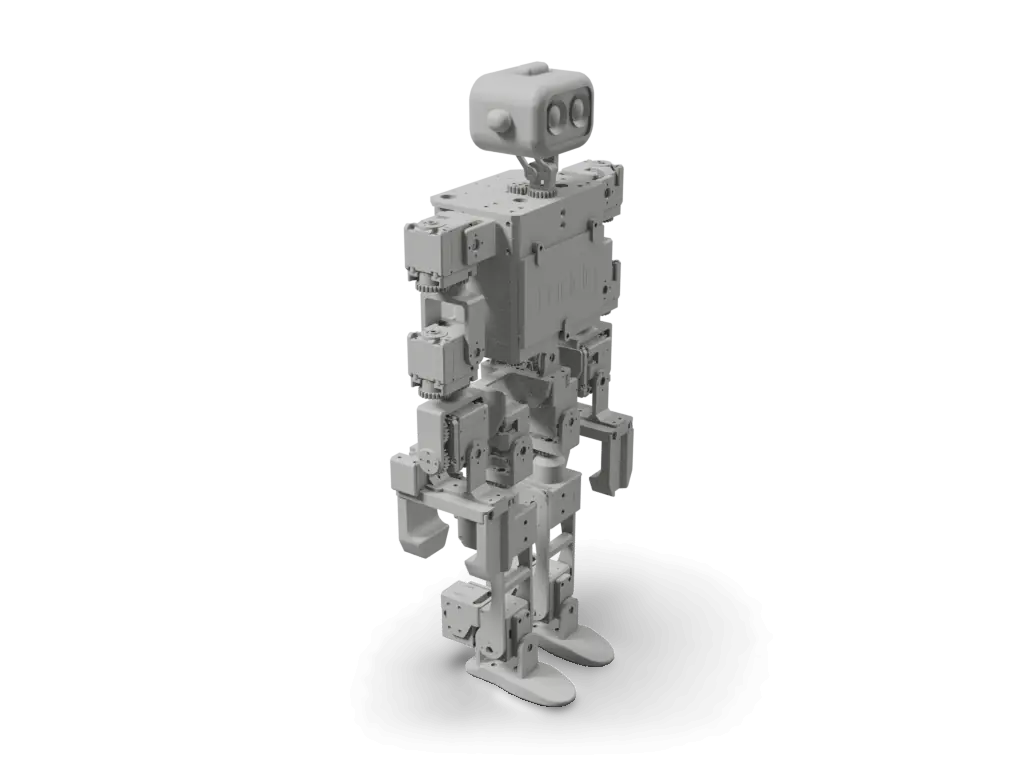
The 3D specimen on this page is converted from data/robots/berkeley_humanoid/berkeley_humanoid_lite/urdf/berkeley_humanoid_lite.urdf at fc90fed.
Builds
No reviewed builds of Berkeley Humanoid Lite yet.
A build log records the evidence (photos, a video, your repository), what the build cost, how long it took and what you changed. Each one is checked by Motari (until a maintainer claims this page) before it shows here, and reviewed builds count toward the reproducibility score.
Sources
Where the facts come from
- Softwaregithub.com/HybridRobotics/berkeley-humanoid-lite984741a
- Simulationgithub.com/HybridRobotics/berkeley-humanoid-lite-assetsfc90fed
- Hardwarecad.onshape.com/documents/fc6443b1d89dcba950e85b60/w/94a2647...
- Hardwaremakerworld.com/en/models/1327260-berkeley-humanoid-lite
- Bill of materialsdocs.google.com/spreadsheets/d/1AQEHcH_nPkXYfor2-h7bwNIUMmse...
- Build guideberkeley-humanoid-lite.gitbook.io/docs
- Softwaregithub.com/T-K-233/Recoil-Motor-Controller-BESC3571ab6
- Documentationarxiv.org/abs/2504.17249
Last push to HybridRobotics/Berkeley-Humanoid-Lite: 2026-03-10 (checked 2026-10-01)
Related links
- Source repositoryHybridRobotics/Berkeley-Humanoid-Lite
- Project websitelite.berkeley-humanoid.org
How this page was made
Assembled from public sources on 2026-06-04, not yet reviewed by the maintainer. Each figure links to where it is stated; a value the sources do not state reads "not published". Last source review: paper 2bb0f690 + assets fc90fed.
Original files stay intact and separately licensed; Motari adds only the summary on this page. Maintainer? Request a correction or removal.
Robots like Berkeley Humanoid Lite
None of the parts in this bill of materials is tracked across robots yet. See the parts robots have in common.
Similar robots
The same type of robot, closest first by body plan, published cost and degrees of freedom. All humanoid robots
Badge for the README
Maintain Berkeley Humanoid Lite? Show its reproducibility score in the project's README. The badge links back to this page and updates with the score.

[](https://motari.io/r/berkeley-humanoid-lite)<a href="https://motari.io/r/berkeley-humanoid-lite"><img src="https://motari.io/api/v1/badge/berkeley-humanoid-lite" alt="Motari reproducibility score for Berkeley Humanoid Lite" height="20"></a>Not fully met yet: bom evidence (partial). The score is read from the project's own sources, so publishing what is missing is what raises it. A score of 90 or more needs a reviewed build. How the score is computed