
Andino
Open ROS 2 differential-drive robot with a parts list, URDF and a printable chassis.
- Cost unknownnot published by the source
- 2 DoF
- BSD-3-Clausehardware
- 80 / 100 reproducibilityStrong source coverage, unverified
What it is
Andino is an open ROS 2 differential-drive robot from Ekumen for education and low-cost applications. Its upstream repository includes a hardware README with linked components, printable chassis and camera-mount STL files, URDF description, micro-controller firmware, ros2_control hardware interface, SLAM, and Nav2 navigation stack around a Raspberry Pi 4 and Arduino Nano.
Licenses
- Hardware
- BSD-3-Clause
- Software
- BSD-3-Clause
- Docs
- Not published
Degrees of freedom
2 DoF driveWheels 2
Differential drivesource
Auto-assembled, not yet reviewed
Source record
- Sources
- 337 stars, last push 2026-09-15
- HW license
- BSD-3-Clause
- Cost
- not published
- Lifecycle
- Active
- Engine
- v3.1.1
- Checked
- not recorded
- Model
- andino.urdf.xacro@645639frendered 2026-10-01
- Envelope
- 210 × 135 × 154 mmas modelled, default pose
Maintain Andino? Claim this page to correct it.
Parts and cost
Cost to build
The sources do not publish a cost total. The rows below are what they list, without a sum.
Andino parts, as the source lists them. Prices are the source's, not checked against vendors.
| Part | Qty | Spec | Source | Confidence |
|---|---|---|---|---|
Raspberry Pi 4 Bmain compute / SBC | 1 | 4 GB; 8 GB optional | PiShop / TiendaTec / Amazon links from the projectprice not listedandino_hardware/README.md line 12 | high |
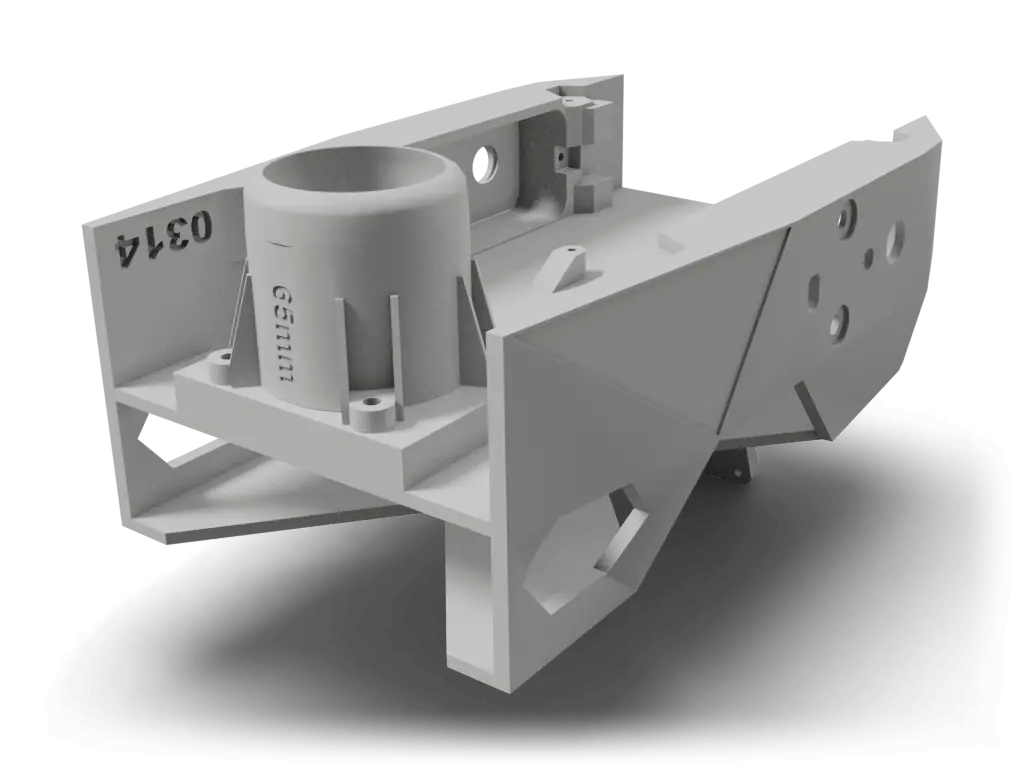
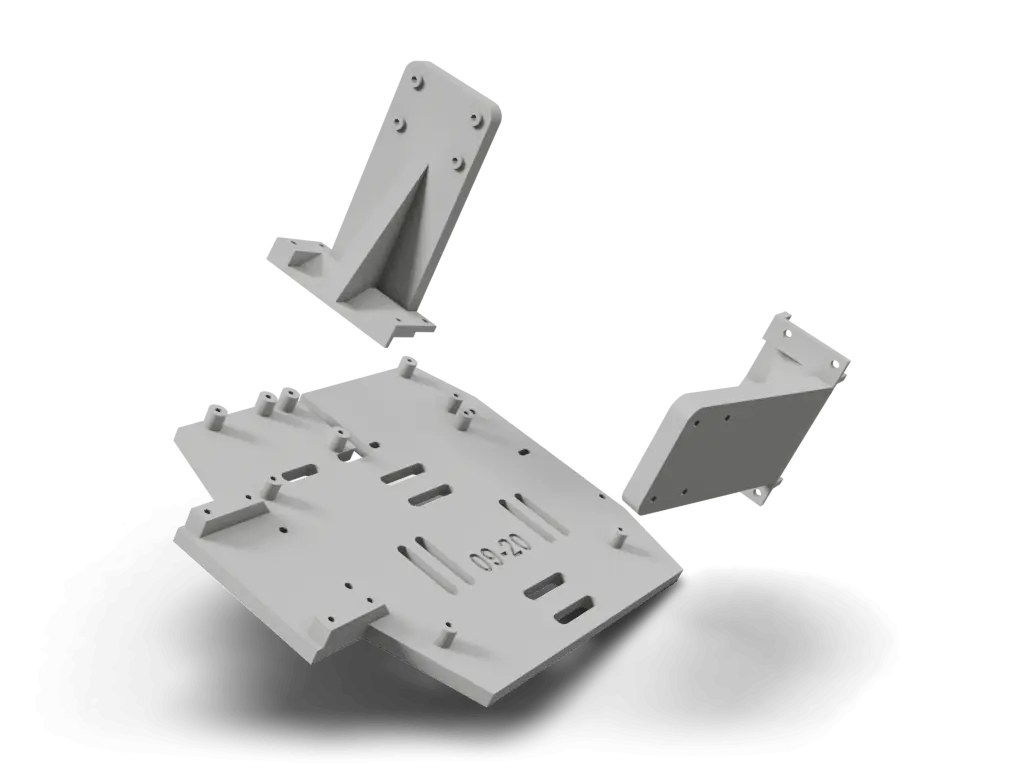
3D-printed chassis and camera mount partsbase, lidar, battery, Arduino lock base, and camera case STL paths | 1 | STL source files listed by upstream hardware README | 3D print yourselfprice not listedandino_hardware/README.md lines 13-17 | high |
Hobby Motor with Encoder - Metal Gear (DG01D-E)drive motors with encoders | 2 | DG01D-E class metal gear motor | SparkFun link from the projectprice not listedandino_hardware/README.md line 18 | high |
TT motor wheelsdrive wheels for the DG01D-E/TT-style motors | 2 | TT motor compatible wheels | Amazon link from the projectprice not listedandino_hardware/README.md line 19 | med |
Arduino Nanolow-level motor/encoder controller | 1 | Nano v3 / ATmega328P class board | Amazon link from the projectprice not listedandino_hardware/README.md line 20 | high |
IMU - BNO055orientation sensor | 1 | BNO055 IMU module | Amazon link from the projectprice not listedandino_hardware/README.md line 21 | high |
L298N Dual H Bridgemotor driver | 1 | dual H-bridge module | Amazon link from the projectprice not listedandino_hardware/README.md line 22 | high |
RPLidar A1M8360 deg 2D laser scanner; source notes a possible separate microUSB cable | 1 | A1M8 lidar | RobotShop / Amazon links from the projectprice not listedandino_hardware/README.md line 23 | high |
Raspberry Pi Camera Module V28 MP camera module and cable links | 1 | Raspi Camera Module V2, 8 MP | RobotShop / Amazon links from the projectprice not listedandino_hardware/README.md line 24 | high |
Battery case, 18650 batteries, charger, DC-DC converter, and kill switchpower system components listed separately by upstream | 1 | battery holder/cells/charger plus 5 V DC-DC converter and kill switch | Amazon links from the projectprice not listedandino_hardware/README.md lines 25-29 | med |
Caster wheel, 64 GB SD card, screws kit, and zip tiesassembly accessories listed by upstream | 1 | caster wheel, storage media, fasteners, and cable management | Amazon links from the project / hardware kitprice not listedandino_hardware/README.md lines 30-33 | med |
Rows from the source's own parts list 22
andino_hardware/README.md@645639fmarkdown
| Source row | Qty | Price and vendor | Line |
|---|---|---|---|
Raspberry Pi 4 B (4 Gb) | L12 | ||
Base_chassis | vendor not listedno price listed | L13 | |
lidar_chassis | vendor not listedno price listed | L14 | |
Battery_chassis | vendor not listedno price listed | L15 | |
Arduino_lock_base | vendor not listedno price listed | L16 | |
Camera_case | vendor not listedno price listed | L17 | |
2 x Motor with Encoder | Sparkfunsparkfun.comno price listed | L18 | |
Wheels | Amazonamazon.comno price listed | L19 |
14 more rows in andino_hardware/README.md
How to build
Steps marked Motari summary condense the linked source; follow the source for exact instructions.
Print the chassis
Print base_chassis, lidar_chassis, battery_chassis and arduino_lock_base from andino_hardware/printing_model/chassis, plus the two Raspberry Pi camera mount parts.
Motari summarygithub.com/Ekumen-OS/andino/tree/main/andino_hardwareMount motors and sensors
Install the two DG01D-E geared motors, caster wheel, BNO055 IMU and Raspberry Pi camera onto the base chassis per the assembly photos.
Motari summarygithub.com/Ekumen-OS/andino/tree/main/andino_hardwareWire the electronics
Connect the motors to the L298N driver and the Arduino Nano, then to the Raspberry Pi 4. Follow the motor/Arduino connection diagram in andino_hardware.
Motari summarygithub.com/Ekumen-OS/andino/tree/main/andino_hardwareFlash the firmware
Build and upload andino_firmware to the Arduino Nano with PlatformIO so it interfaces the low-level motor and encoder hardware with the SBC.
Motari summarygithub.com/Ekumen-OS/andino/tree/main/andino_hardwareBring up ROS 2
Build the colcon workspace on the Pi, launch andino_bringup, then run SLAM and Nav2 for autonomous navigation.
Motari summarygithub.com/Ekumen-OS/andino/tree/main/andino_hardware
Wiring, power and firmware are safety-relevant and shown for reference only. Check them against the source before building.
partialCAD / mesh present6 mesh files; no editable CAD source in the repo10/20
Quality tier 2 of 3
metBOM evidenceandino_hardware/README.md table (Bill of Materials): 22 line items, quantities, vendor links20/20
Quality tier 3 of 5
metWiring diagram1 wiring/schematic diagram (image or PDF)15/15
Quality tier 2 of 3
metFirmware linkedfirmware source in the repo (PlatformIO, Arduino)10/10
Quality tier 3 of 3
metBuild instructionsstep-by-step guide with images15/15
Quality tier 2 of 3
metOSHW-compatible licenseBSD-3-Clause (from andino_hardware/LICENSE)10/10
Quality tier 2 of 2
- andino_hardware/LICENSE645639f
missingKnown reproductionsno verified builds yet0/10
Quality tier 0 of 2
Only build reports a maintainer or admin has reviewed count here.
Engine v3.1.1 at 645639f
- The engine found no joint model or stated figure to count degrees of freedom from.
Files and sim
- andino_description/urdf/include/common_macros.urdf.xacro
- andino_description/urdf/andino.urdf.xacro
- andino_description/urdf/include/common_sensors.urdf.xacro
- andino_description/meshes/sensors/rplidar-a2.stl
- andino_description/meshes/andino/wheel_tire.stl
- andino_description/meshes/components/wheel.stl
- andino_hardware/docs/assembly/8.motor_driver_connections.jpg
- andino_firmware/andino_firmware.ino
- andino_navigation/rviz/nav2_default_view.rviz
- andino_navigation/params/nav2_params_humble.yaml
- andino_slam/rviz/andino_slam.rviz
- andino_hardware/README.md
- CODE_OF_CONDUCT.md
- README.md
Files stay in the upstream repository under their own licenses; these links open them there. The 3D model on this page is Motari's conversion of the file named under Simulation.
Simulation
Robot description files a simulator or CAD tool can load, linked at the commit they were found.
- URDFandino_description/urdf/andino.urdf.xacroEkumen-OS/andino
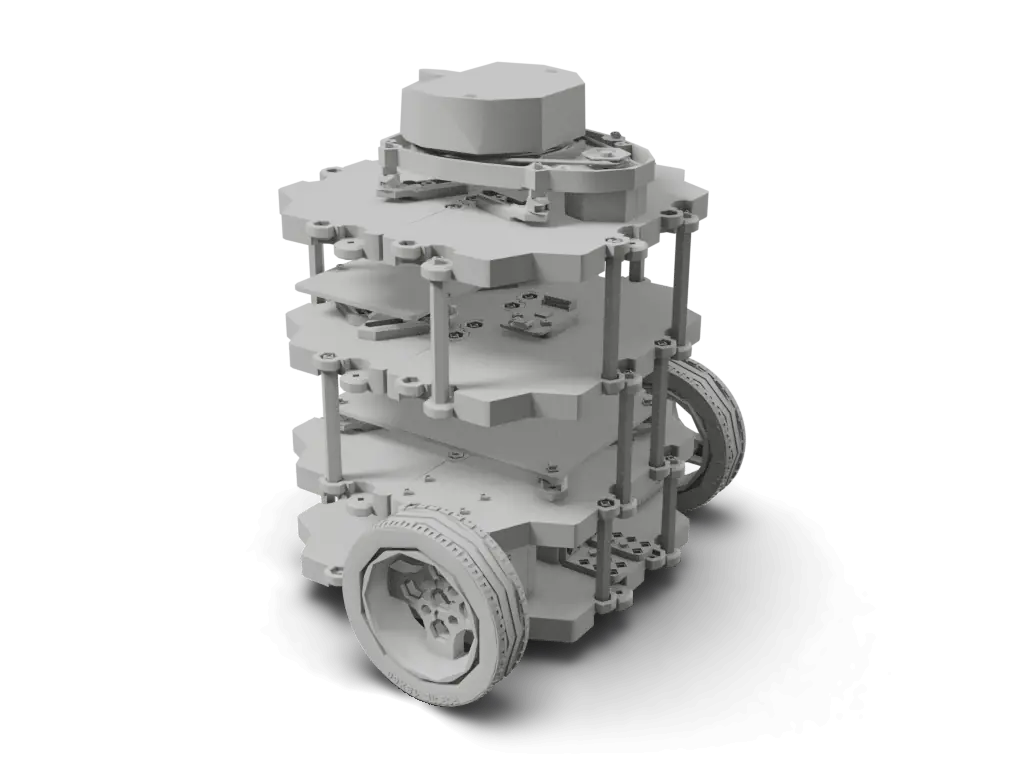
The 3D specimen on this page is converted from andino_description/urdf/andino.urdf.xacro at 645639f.
Builds
No reviewed builds of Andino yet.
A build log records the evidence (photos, a video, your repository), what the build cost, how long it took and what you changed. Each one is checked by Motari (until a maintainer claims this page) before it shows here, and reviewed builds count toward the reproducibility score.
Sources
Where the facts come from
- Hardwaregithub.com/Ekumen-OS/andino/tree/main/andino_hardware645639f
- Bill of materialsgithub.com/Ekumen-OS/andino/blob/main/andino_hardware/README.md645639f
- Softwaregithub.com/Ekumen-OS/andino645639f
- Simulationgithub.com/Ekumen-OS/andino_gz4dabcb2
Last push to Ekumen-OS/andino: 2026-09-15 (checked 2026-10-01)
How this page was made
Assembled from public sources on 2026-06-04, not yet reviewed by the maintainer. Each figure links to where it is stated; a value the sources do not state reads "not published". Last source review: source BOM 645639f.
Original files stay intact and separately licensed; Motari adds only the summary on this page. Maintainer? Request a correction or removal.
Robots like Andino
Shares parts with
Robots whose bill of materials names the same parts, most shared first. Each part links to every robot that uses it.
- Linorobot2Raspberry PiRPLIDAR33
- JPL Open Source RoverRaspberry Pi89
- XLeRobotRaspberry Pi89
- AlohaMiniRaspberry Pi83
- UpkieRaspberry Pi83
- Asimov 1Raspberry Pi80
Parts in this robot's BOM: Raspberry Pi (25 other robots), Arduino (8 other robots), Slamtec RPLIDAR (3 other robots)
Similar robots
The same type of robot, closest first by body plan, published cost and degrees of freedom. All mobile robots
Badge for the README
Maintain Andino? Show its reproducibility score in the project's README. The badge links back to this page and updates with the score.

[](https://motari.io/r/andino)<a href="https://motari.io/r/andino"><img src="https://motari.io/api/v1/badge/andino" alt="Motari reproducibility score for Andino" height="20"></a>Not fully met yet: cad / mesh present (partial). The score is read from the project's own sources, so publishing what is missing is what raises it. A score of 90 or more needs a reviewed build. How the score is computed