
SO-ARM100 / SO-ARM101 (Standard Open Arm)
Deprecated first Standard Open Arm, superseded by SO-101: low-cost printable leader/follower arm.
- $123 in partsfollower arm only, source total
- 6 DoF
- Apache-2.0hardware
- 83 / 100 reproducibilityStrong source coverage, unverified
What it is
SO-ARM100 is The Robot Studio's first Standard Open Arm, a low-cost printable 6-DoF arm used with LeRobot. Upstream marks the SO-100 docs as deprecated in favour of SO-101. The BOM is the SO100.md table for one follower arm, without print costs. Upstream says the six leader-arm motors need their gears removed.
Licenses
- Hardware
- Apache-2.0
- Software
- Not published
- Docs
- Not published
Degrees of freedom
6 DoF arm 5gripper 1
Serial armLeader-follower pairsource
Auto-assembled, not yet reviewed
Source record
- Source
- 7.6k stars, last push 2026-09-23
- HW license
- Apache-2.0
- Cost
- $123source total, follower arm only
- Lifecycle
- Deprecated
- Engine
- v3.1.1
- Checked
- Model
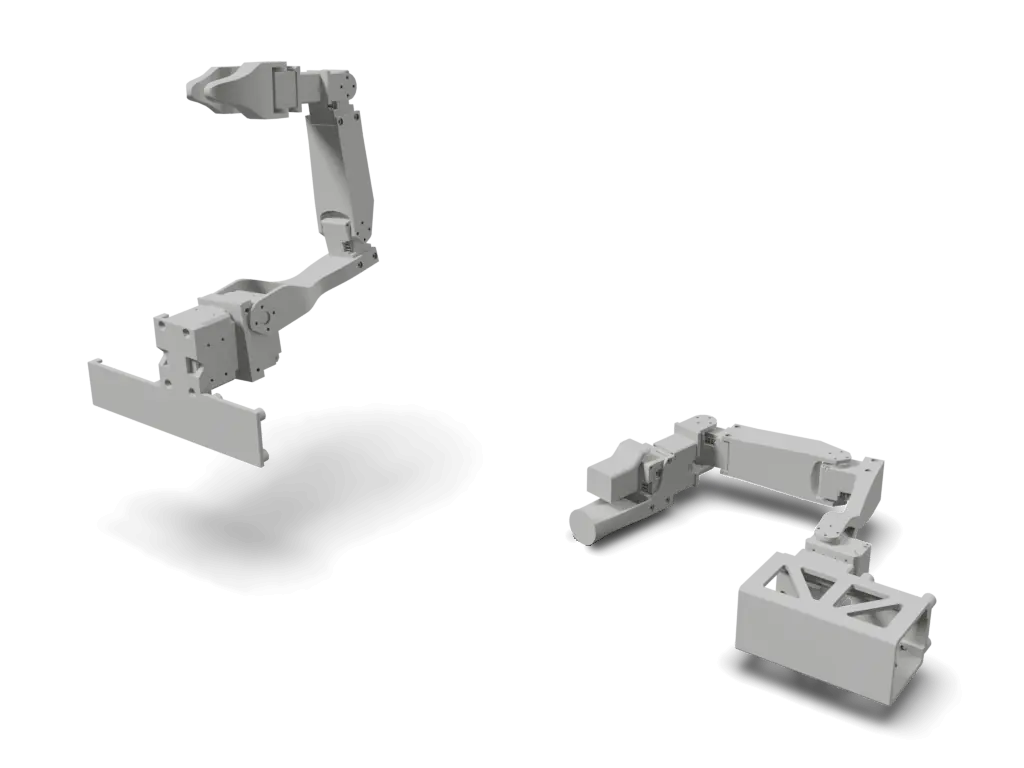
- so100.urdf@fda892crendered 2026-10-01
- Envelope
- 111 × 284 × 373 mmas modelled, in a presentation pose
Maintain SO-ARM100 / SO-ARM101 (Standard Open Arm)? Claim this page to correct it.
Parts and cost
Cost to build
- follower arm only
- leader and follower pair
In the source currency, as read on 2026-09-30. Not converted, and not checked against current vendor prices: none of these is a Motari-verified checkout total.
SO-ARM100 / SO-ARM101 (Standard Open Arm) parts, as the source lists them (read 2026-09-30). Prices are the source's, not checked against vendors.
| Part | Qty | Spec | Source | Confidence |
|---|---|---|---|---|
STS3215 ServoFollower-arm servos from the SO-100 BOM table | 6 | Feetech STS3215 7.4V bus servo | Alibaba / TaoBao$14 eachTheRobotStudio/SO-ARM100 SO100.md line 34 | high |
Motor Control BoardUSB servo control board | 1 | Waveshare serial bus servo board | Amazon / TaoBao$11TheRobotStudio/SO-ARM100 SO100.md line 35 | high |
USB-C Cable 2 pcsCable pair listed as one BOM line | 1 | USB-C cable, 2 pieces | Amazon / TaoBao$7TheRobotStudio/SO-ARM100 SO100.md line 36 | high |
Power SupplyDC power supply for the follower arm | 1 | 5V supply in upstream BOM | Amazon / TaoBao$10TheRobotStudio/SO-ARM100 SO100.md line 37 | high |
Table Clamp 2pcsFollower-arm table clamp set | 1 | 2-piece clamp set | Amazon / TaoBao$5TheRobotStudio/SO-ARM100 SO100.md line 38 | high |
Screwdriver SetAssembly tool listed in the source BOM | 1 | precision screwdriver set | Amazon / TaoBao$6TheRobotStudio/SO-ARM100 SO100.md line 39 | high |
How to build
Steps marked Motari summary condense the linked source; follow the source for exact instructions. Upstream step marks a step taken from the linked guide.
Print the structural parts
STL files are provided for several printer bed sizes, plus STEP files. Upstream recommends PLA at 13% infill with a 0.4 mm nozzle at 0.2 mm layers or a 0.6 mm nozzle at 0.4 mm layers.
Motari summaryhuggingface.co/docs/lerobot/so100ID the servos
Assign each Feetech STS3215 bus servo a unique ID with the motor control board before assembly.
Motari summaryhuggingface.co/docs/lerobot/so100Assemble the links
Bolt the printed links to the servo horns from the base up, following the assembly guide. Upstream says to remove the gears of the six leader-arm motors before assembly.
Upstream stephuggingface.co/docs/lerobot/so100Wire power and data
Daisy-chain the bus servos and connect the control board to USB. Verify wiring against the docs.
Upstream stephuggingface.co/docs/lerobot/so100Calibrate and teleoperate
Run the LeRobot calibration, then drive the follower from the leader arm.
Motari summaryhuggingface.co/docs/lerobot/so100
Wiring, power and firmware are safety-relevant and shown for reference only. Check them against the source before building.
metCAD / mesh present35 editable CAD files (STEP), including an assembly + 117 mesh files20/20
Quality tier 3 of 3
metBOM evidenceREADME.md table (Parts For Two Arms (Follower and Leader Setup):): 8 line items, quantities, priced (USD), vendor links, stated total USD 229.8820/20
Quality tier 5 of 5
partialWiring diagramReviewedThe LeRobot SO-100 guide describes the wiring in text (USB and power to the controller board, jumper setting, 3-pin cables chained motor to motor) with routing photos; no diagram.7.5/15
Quality tier 1 of 3
Reviewed override, 2026-09-30
Evidence on huggingface.coEngine alone: missing at tier 0 (no wiring diagram found)
metFirmware linkedReviewedLeRobot's so_follower module (with its so100 page) is the SO-100 control code that drives the arm's Feetech bus; the engine only counts the project's own repos.10/10
Quality tier 2 of 3
Reviewed override, 2026-09-30
Evidence on github.comEngine alone: partial at tier 1 (firmware mentioned, no source or link)
- README.md mentions firmware5f6d2b8
metBuild instructionsReviewedLeRobot's SO-100 guide has 27 numbered assembly steps with 29 photos; the engine does not open the Hugging Face docs.15/15
Quality tier 2 of 3
Reviewed override, 2026-09-30
Evidence on huggingface.coEngine alone: partial at tier 1 (external build guide linked, not inspected by the engine)
metOSHW-compatible licenseApache-2.0 (from repository license)10/10
Quality tier 2 of 2
- LICENSE5f6d2b8
missingKnown reproductionsno verified builds yet0/10
Quality tier 0 of 2
Only build reports a maintainer or admin has reviewed count here.
Engine v3.1.1 at 5f6d2b8, 3 items reviewed by hand
How this score is computedFiles and sim
- Simulation/SO101/so101_new_calib.urdf
- Simulation/SO101/so101_old_calib.urdf
- Simulation/SO100/so100.urdf
- STEP/SO101/SO101 Assembly.step
- STEP/SO100/Follower_Specific/SO_5DOF_ARM100_Assembly.step
- STEP/SO100/Leader_Specific/SO_5DOF_ARM100_Assembly.step
- STL/SO101/Individual/SO101 Assembly.stl
- STL/SO101/Leader/Ender_Leader_SO101.stl
- STL/SO101/Follower/Ender_Follower_SO101.stl
- README.md
- SO100.md
- Optional/Overhead_Cam_Mount_Webcam/README.md
Files stay in the upstream repository under their own licenses; these links open them there. The 3D model on this page is Motari's conversion of the file named under Simulation.
Simulation
Robot description files a simulator or CAD tool can load, linked at the commit they were found.
- URDFSimulation/SO100/so100.urdfTheRobotStudio/SO-ARM100
The 3D specimen on this page is converted from Simulation/SO100/so100.urdf at fda892c.
Builds
No reviewed builds of SO-ARM100 / SO-ARM101 (Standard Open Arm) yet.
A build log records the evidence (photos, a video, your repository), what the build cost, how long it took and what you changed. Each one is checked by Motari (until a maintainer claims this page) before it shows here, and reviewed builds count toward the reproducibility score.
Sources
Where the facts come from
- Hardwaregithub.com/TheRobotStudio/SO-ARM1005f6d2b8
- Bill of materialsgithub.com/TheRobotStudio/SO-ARM100/blob/main/SO100.md5f6d2b8
- Build guidehuggingface.co/docs/lerobot/so100
Last push to TheRobotStudio/SO-ARM100: 2026-09-23 (checked 2026-10-01)
Related links
- LeRobot integrationhuggingface.co/lerobot
How this page was made
Assembled from public sources on 2026-06-04, not yet reviewed by the maintainer. Each figure links to where it is stated; a value the sources do not state reads "not published". Last source review: 2026-06-07 TheRobotStudio/SO-ARM100 README BOM.
Original files stay intact and separately licensed; Motari adds only the summary on this page. Maintainer? Request a correction or removal.
Robots like SO-ARM100 / SO-ARM101 (Standard Open Arm)
Lineage
- Superseded by
- SO-101
- Supersedes
- Moss v1 Robot Arms
Shares parts with
Robots whose bill of materials names the same parts, most shared first. Each part links to every robot that uses it.
Parts in this robot's BOM: Feetech STS3215 servo (10 other robots)
Similar robots
The same type of robot, closest first by body plan, published cost and degrees of freedom. All robot arms
Badge for the README
Maintain SO-ARM100 / SO-ARM101 (Standard Open Arm)? Show its reproducibility score in the project's README. The badge links back to this page and updates with the score.

[](https://motari.io/r/so-arm100)<a href="https://motari.io/r/so-arm100"><img src="https://motari.io/api/v1/badge/so-arm100" alt="Motari reproducibility score for SO-ARM100 / SO-ARM101 (Standard Open Arm)" height="20"></a>Not fully met yet: wiring diagram (partial). The score is read from the project's own sources, so publishing what is missing is what raises it. A score of 90 or more needs a reviewed build. How the score is computed