
Koch v1.1
Low-cost 6-DoF leader/follower arm, an improved Alexander Koch design.
- $477 in partsleader and follower arms, source total
- 6 DoF
- Apache-2.0hardware
- 89 / 100 reproducibilityStrong source coverage, unverified
What it is
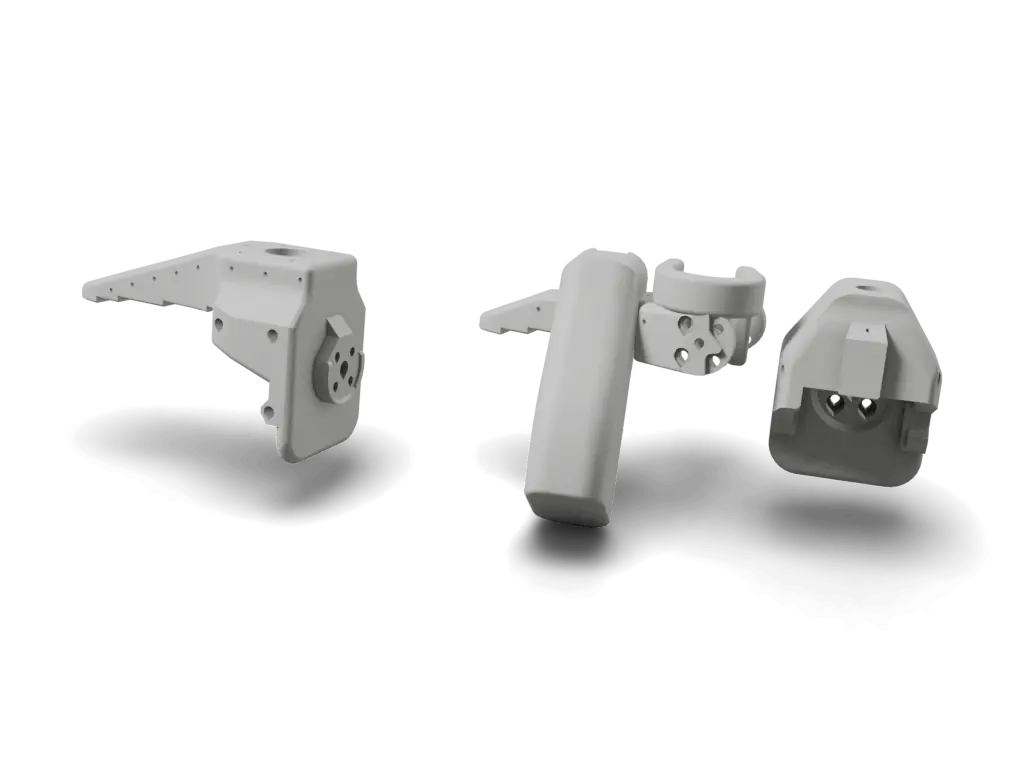
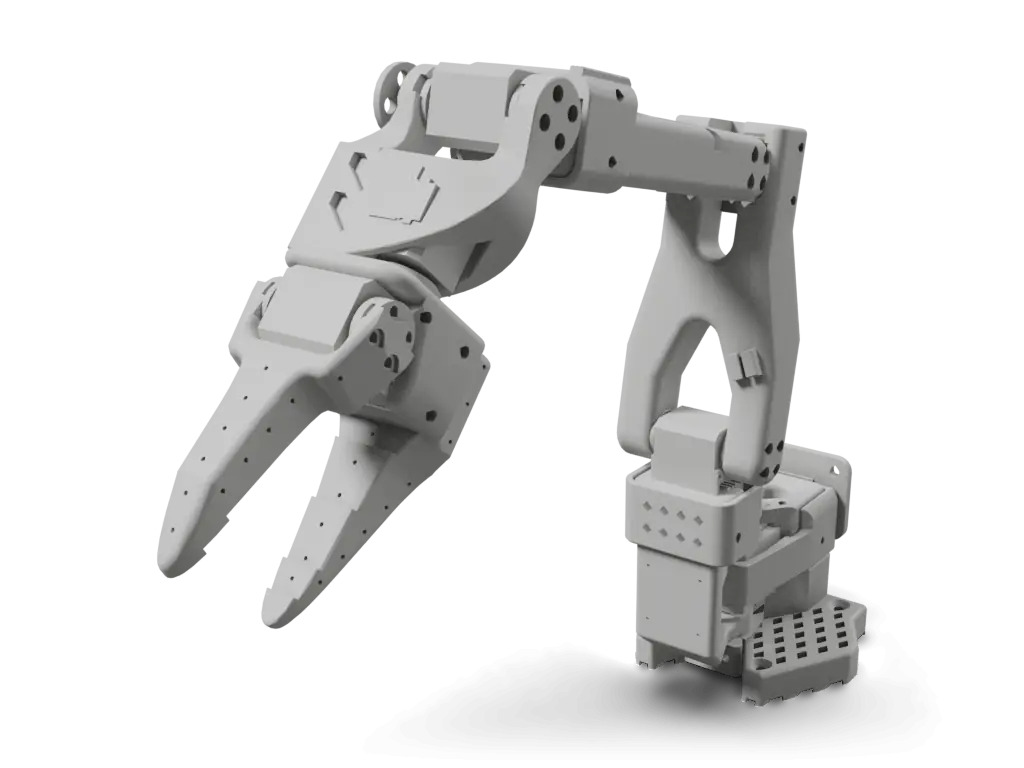
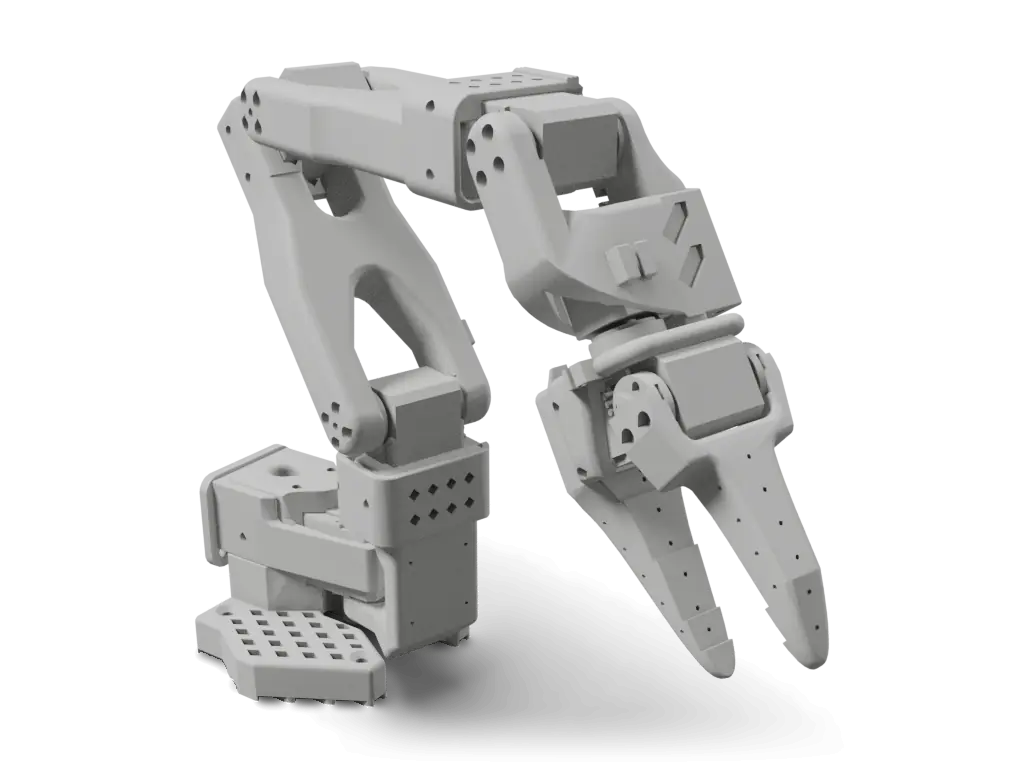
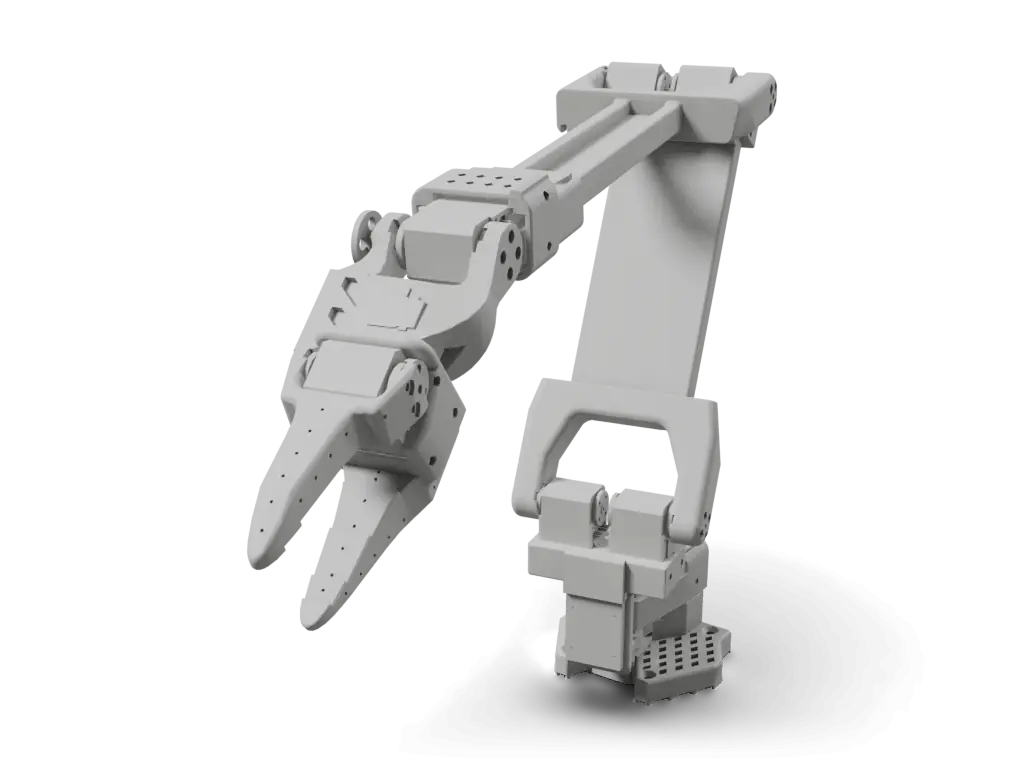
Koch v1.1 is an improved version of Alexander Koch's low-cost robot arm, refined for easier assembly with no soldering required. It is a teleoperated leader and follower pair built around Dynamixel XL-series servos and integrates with the LeRobot library. The 3D view shows both arms from the upstream STEP assemblies. The README publishes separate leader and follower BOM tables that add up to $477 at the listed US prices.
Licenses
- Hardware
- Apache-2.0
- Software
- Not published
- Docs
- Not published
Degrees of freedom
6 DoF arm 5gripper 1
Serial armLeader-follower pairsource
Auto-assembled, not yet reviewed
Source record
- Source
- 733 stars, last push 2024-09-17
- HW license
- Apache-2.0
- Cost
- $477source total, leader and follower arms
- Lifecycle
- Dormant
- Engine
- v3.1.1
- Checked
- Model
- Follower_Arm.STEP@1a553e1rendered 2026-06-07
- Envelope
- 536 × 311 × 292 mmas modelled, default pose
Maintain Koch v1.1? Claim this page to correct it.
Parts and cost
Cost to build
- leader and follower arms
- follower arm
- leader arm
In the source currency, as read on 2026-09-30. Not converted, and not checked against current vendor prices: none of these is a Motari-verified checkout total.
Koch v1.1 parts, as the source lists them. Prices are the source's, not checked against vendors.
| Part | Qty | Spec | Source | Confidence |
|---|---|---|---|---|
Dynamixel XL330-M077-T servoLeader BOM | 6 | leader arm smart serial servos; $24 each in US BOM | vendors in the project's README$144Leader BOM; README lines 28 | high |
Dynamixel XL430-W250-T servoFollower BOM | 2 | follower base smart serial servos; $50 each in US BOM | vendors in the project's README$100Follower BOM; README lines 47 | high |
Dynamixel XL330-M288-T servoFollower BOM | 4 | follower distal smart serial servos; $24 each in US BOM | vendors in the project's README$96Follower BOM; README lines 48 | high |
XL330 frame and idler wheel 4pcs setLeader and follower BOM | 2 | one set for leader and one set for follower; $10 each in US BOM | ROBOTIS$20Leader and follower BOM; README lines 29,49 | high |
XL430 idler wheel setFollower BOM | 1 | follower hardware set; $7 in US BOM | ROBOTIS$7Follower BOM; README lines 50 | high |
Waveshare Serial Bus Servo Driver BoardLeader and follower BOM | 2 | one per arm; $10 each in US BOM | Waveshare$20Leader and follower BOM; README lines 30,51 | high |
5V power supplyLeader BOM | 1 | leader power supply; $6 in US BOM | vendors in the project's README$6Leader BOM; README lines 31 | high |
12V power supplyFollower BOM | 1 | follower power supply; $12 in US BOM | vendors in the project's README$12Follower BOM; README lines 53 | high |
Voltage reducerFollower BOM | 1 | follower voltage reducer; $14 in US BOM | vendors in the project's README$14Follower BOM; README lines 52 | high |
Jumper wires 3x40 pcs setLeader and follower BOM | 2 | one set per arm in source tables; $7 each in US BOM | vendors in the project's README$14Leader and follower BOM; README lines 32,54 | high |
Table clampLeader and follower BOM | 2 | one clamp per arm in source tables; $6 each in US BOM | vendors in the project's README$12Leader and follower BOM; README lines 33,55 | high |
1.5 mm star/cruciform screwdriver 2pcs setLeader and follower BOM | 2 | tool row appears in both source tables; $7 each in US BOM | vendors in the project's README$14Leader and follower BOM; README lines 35,57 | high |
USB C-A or C-C 2pcs cable setLeader and follower BOM | 2 | USB cable row appears in both source tables; $9 each in US BOM | vendors in the project's README$18Leader and follower BOM; README lines 36,58 | high |
3D-printed structural partsprintable STL files provided for leader and follower arms; local filament cost is not part of the README $477 total | 1 | leader and follower printed parts from hardware/*/STL | 3D print yourselfnot included in source totalPrintable source files present; no source filament price found | high |
Rows from the source's own parts list 21
README.md@1a553e1markdown
| Source row | Qty | Price and vendor | Line |
|---|---|---|---|
Dynamixel XL330-M077-T | 6 | L28 | |
XL330 Frame and Idler Wheel 4pcs set | 1 | L29 | |
Waveshare Serial Bus Servo Driver Board | 1 | L30 | |
5V Power Supply | 1 | L31 | |
Jumper Wires 3*40 pcs set (M-M, M-F, F-F) | 1 | L32 | |
Table Clamp | 1 | L33 | |
Table Clamp 4pcs set | 1 | L34 | |
1.5mm Star/Cruciform Screwdriver 2pcs set | 1 | L35 |
13 more rows in README.md
How to build
Steps marked Motari summary condense the linked source; follow the source for exact instructions. Upstream step marks a step taken from the linked guide.
Print the structural parts
STL files provided for leader and follower arms. SolidWorks CAD models are included for modification.
Motari summaryhuggingface.co/docs/lerobot/kochID and configure servos
Set unique IDs for the Dynamixel XL servos using the Waveshare driver board.
Motari summaryhuggingface.co/docs/lerobot/kochAssemble the arms
Assemble both arms following the upstream assembly video and SolidWorks animations. Version 1.1 needs no soldering and adds a leader arm platform, fastened to the leader base with four M2x5 screws and M2 nuts.
Motari summaryhuggingface.co/docs/lerobot/kochWire power and data
Wire the leader (5V) and follower (12V with voltage reducer) per the included wiring diagram.
Upstream stepgithub.com/jess-moss/koch-v1-1/blob/1a553e1fa7d5404b51bbd83b...Calibrate and teleoperate
Run calibration and drive the follower from the leader arm.
Motari summaryhuggingface.co/docs/lerobot/koch
Wiring, power and firmware are safety-relevant and shown for reference only. Check them against the source before building.
metCAD / mesh present34 editable CAD files (STEP/SLDASM/SLDPRT), including an assembly + 17 mesh files20/20
Quality tier 3 of 3
metBOM evidenceREADME.md table (Leader Arm): 9 line items, quantities, priced (USD), vendor links, stated total USD 199.0020/20
Quality tier 5 of 5
- README.md table (Leader Arm)1a553e1
metWiring diagram1 wiring/schematic diagram (image or PDF)15/15
Quality tier 2 of 3
metFirmware linkedReviewedThe koch-v1-1 README names LeRobot as the control stack; LeRobot's KochFollower class drives the Dynamixel bus. The engine does not follow the external link.10/10
Quality tier 2 of 3
Reviewed override, 2026-09-30
Evidence on github.comEngine alone: missing at tier 0 (no firmware found)
metBuild instructionsstep-by-step guide with images15/15
metOSHW-compatible licenseApache-2.0 (from repository license)10/10
Quality tier 2 of 2
- LICENSE1a553e1
missingKnown reproductionsno verified builds yet0/10
Quality tier 0 of 2
Only build reports a maintainer or admin has reviewed count here.
Capped at 89: the criteria add up to 90, and a score of 90 or more needs a reviewed build.
Engine v3.1.1 at 1a553e1, 1 item reviewed by hand
- The engine found no joint model or stated figure to count degrees of freedom from.
Files and sim
- hardware/leader/SolidWorks/Leader_Arm.SLDASM
- hardware/follower/STEP/Robotis_DYNAMIXEL_XL430_W250_T.STEP
- hardware/follower/STEP/Robotis_DYNAMIXEL_XL330_M288_T.STEP
- hardware/leader/STL/Robotis_FPX330_S101.STL
- hardware/leader/STL/Leader_Base.STL
- hardware/follower/STL/Follower_Elbow_To_Wrist.STL
- electrical/Wiring_Diagram_Alexander_Koch_V1.1.pdf
- README.md
- hardware/leader/STEP/Leader_Arm.STEP
- hardware/follower/STEP/Follower_Arm.STEP
Files stay in the upstream repository under their own licenses; these links open them there. The 3D model on this page is Motari's conversion of the file named under Simulation.
Simulation
Robot description files a simulator or CAD tool can load, linked at the commit they were found.
No URDF, MJCF, SDF, USD or Onshape model has been found in the sources.
The 3D specimen on this page is converted from hardware/follower/STEP/Follower_Arm.STEP at 1a553e1.
Builds
No reviewed builds of Koch v1.1 yet.
A build log records the evidence (photos, a video, your repository), what the build cost, how long it took and what you changed. Each one is checked by Motari (until a maintainer claims this page) before it shows here, and reviewed builds count toward the reproducibility score.
Sources
Where the facts come from
- Hardwaregithub.com/jess-moss/koch-v1-11a553e1
- Build guidehuggingface.co/docs/lerobot/koch
Last push to jess-moss/koch-v1-1: 2024-09-17 (checked 2026-10-01)
Related links
- LeRobot integrationhuggingface.co/lerobot
- Based onAlexander Koch low-cost arm
How this page was made
Assembled from public sources on 2026-06-04, not yet reviewed by the maintainer. Each figure links to where it is stated; a value the sources do not state reads "not published". Last source review: 2026-06-07 source README BOM total; vendor prices not checkout-reconciled.
Original files stay intact and separately licensed; Motari adds only the summary on this page. Maintainer? Request a correction or removal.
Robots like Koch v1.1
Shares parts with
Robots whose bill of materials names the same parts, most shared first. Each part links to every robot that uses it.
- Q8botDynamixelXL33080
- Stack-chanDynamixelXL33080
- GELLODynamixelXL33073
- ToddlerBotDynamixelXL43070
- Actuated UMI GripperDynamixelXL43068
- TRLC-DK1DynamixelXL33065
Parts in this robot's BOM: ROBOTIS Dynamixel servos (16 other robots), Dynamixel XL330 servo (6 other robots), Dynamixel XL430 servo (3 other robots)
Similar robots
The same type of robot, closest first by body plan, published cost and degrees of freedom. All robot arms
Badge for the README
Maintain Koch v1.1? Show its reproducibility score in the project's README. The badge links back to this page and updates with the score.

[](https://motari.io/r/koch-v1-1)<a href="https://motari.io/r/koch-v1-1"><img src="https://motari.io/api/v1/badge/koch-v1-1" alt="Motari reproducibility score for Koch v1.1" height="20"></a>A score of 90 or more needs a reviewed build. How the score is computed