
AlohaMini
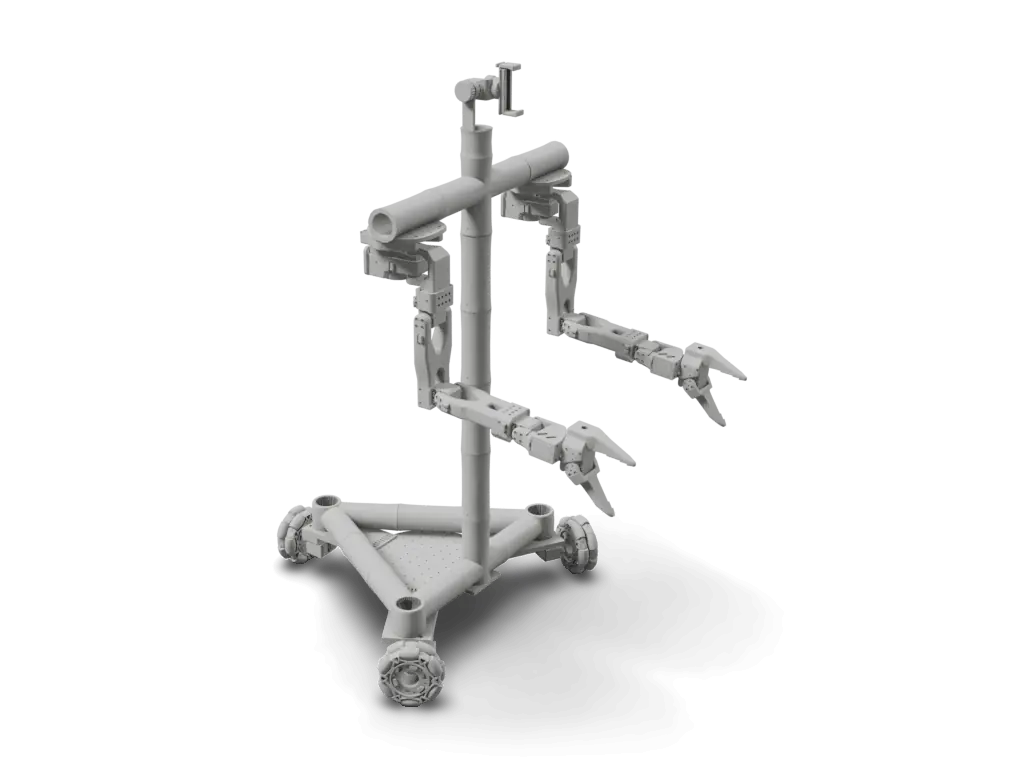
AlohaMini2: dual 6+1 DoF arms on a motorized lift over a 3-omni-wheel printed base.
- $950AlohaMini2 major components per the README BOM table, leader arms excluded; upstream wording 'keeping the self-build BOM under $1,000'. The full AlohaMini2/docs/BOM.md estimate is ~1,097 USD (CNY 7,548) self-print including leader arms (~277 USD), filament not included, estimate
- 18 DoF
- Apache-2.0hardware
- 83 / 100 reproducibilityStrong source coverage, unverified
What it is
AlohaMini is Li Yiteng and Wu Zhiyong's open dual-arm mobile robot; the current AlohaMini2 (released 2026-06-06) puts two 6+1 DoF AM-ARM200 follower arms on a motorized vertical lift over a three-omni-wheel 3D-printed base, with five USB cameras and a Raspberry Pi 5. AlohaMini1, with SO-ARM100/101 arms and a base that needs a large-format printer, stays in the same repo. The repo holds STEP and STL files for the AlohaMini2 base and lift, URDFs for AlohaMini2 and 2 Pro, a BOM and print and assembly guides; the arm CAD lives in liyiteng/AM-ARM and the LeRobot-based software in liyiteng/lerobot_alohamini, all Apache-2.0. Upstream says the self-build BOM stays under $1,000 (README estimate ~$950 without the leader arms), while the full BOM.md estimate with leader arms is ~$1,097, filament excluded.
Licenses
- Hardware
- Apache-2.0
- Software
- Apache-2.0
- Docs
- Not published
Degrees of freedom
18 DoF arm 12lift 1wheels 3gripper 2
Mobile manipulatorBimanualHolonomic baseOmni wheelsVertical liftLeader-follower pairsource
Auto-assembled, not yet reviewed
Source record
- Sources
- 1.1k stars, last push 2026-07-01
- HW license
- Apache-2.0
- Cost
- $950estimate, AlohaMini2 major components per the README BOM table, leader arms excluded; upstream wording 'keeping the self-build BOM under $1,000'. The full AlohaMini2/docs/BOM.md estimate is ~1,097 USD (CNY 7,548) self-print including leader arms (~277 USD), filament not included
- Lifecycle
- Active
- Engine
- v3.1.1
- Checked
- Model
- alohamini2.urdf@17c6a98rendered 2026-10-02
- Envelope
- 531 × 1126 × 649 mmas modelled, in a presentation pose
Maintain AlohaMini? Claim this page to correct it.
Parts and cost
Cost to build
- AlohaMini2 major components per the README BOM table, leader arms excluded; upstream wording 'keeping the self-build BOM under $1,000'. The full AlohaMini2/docs/BOM.md estimate is ~1,097 USD (CNY 7,548) self-print including leader arms (~277 USD), filament not included
In the source currency, as read on 2026-09-30. Not converted, and not checked against current vendor prices: none of these is a Motari-verified checkout total.
AlohaMini parts, as the source lists them. Prices are the source's, not checked against vendors.
| Part | Qty | Spec | Source | Confidence |
|---|---|---|---|---|
Servo, STS-3215 (wheel)Mobile base: three omni-wheel drive servos | 3 | ST-3215-C018, 12V, 1/345 gear | Alibaba$15.97 eachliyiteng/AlohaMini AlohaMini2/docs/BOM.md line 16 | high |
Servo, STS-3095 (lift)Mobile base: vertical lift servo | 1 | ST-3095-C002, 12V, 95 kg·cm | Alibaba$50.37liyiteng/AlohaMini AlohaMini2/docs/BOM.md line 17 | high |
Omni wheelMobile base | 3 | 127 mm (74A) | omniawheel.com$40 eachliyiteng/AlohaMini AlohaMini2/docs/BOM.md line 18 | high |
Aluminum extrusion (T-frame)Mobile base; a printed substitute (O_T_Connector_Cross_Bar.stl) is allowed but weaker | 1 | 20x40x2 mm, L=400 mm | not listed in source BOM~$1.50liyiteng/AlohaMini AlohaMini2/docs/BOM.md line 19 | high |
Bearing, lift trackMobile base; pressed into the shoulder lift block | 8 | 4x13x5 mm | Amazon~$0.40 eachliyiteng/AlohaMini AlohaMini2/docs/BOM.md line 22 | high |
Bearing, chassis/arm/liftMobile base | 8 | 12x18x4 mm | Amazon~$0.80 eachliyiteng/AlohaMini AlohaMini2/docs/BOM.md line 23 | high |
Camera, frontMobile base | 1 | H65V1, 720p, 2.4 mm, 1 m cable | Amazon~$17liyiteng/AlohaMini AlohaMini2/docs/BOM.md line 24 | high |
Camera, backMobile base | 1 | H65V1, 720p, 2.4 mm, 1 m cable | Amazon~$17liyiteng/AlohaMini AlohaMini2/docs/BOM.md line 25 | high |
Camera, chestMobile base | 1 | H65V1, 720p, 2.4 mm, 2 m cable | Amazon~$17liyiteng/AlohaMini AlohaMini2/docs/BOM.md line 26 | high |
Raspberry Pi 5Mobile base compute (host); upstream says any SBC with USB 3.0, such as a Jetson Orin Nano, can replace it | 1 | 2 GB RAM | Adafruit~$93liyiteng/AlohaMini AlohaMini2/docs/BOM.md line 27 | high |
DC buck converterMobile base; battery 2 to the Raspberry Pi | 1 | 12V to 5V 5A (PD protocol) | Amazon~$9liyiteng/AlohaMini AlohaMini2/docs/BOM.md line 28 | high |
microSD cardMobile base | 1 | 32 GB | Amazon~$14liyiteng/AlohaMini AlohaMini2/docs/BOM.md line 30 | high |
Bus servo controllerMobile base | 1 | Waveshare Bus Servo Adapter A | Waveshare$5.00liyiteng/AlohaMini AlohaMini2/docs/BOM.md line 32 | high |
Battery 12VMobile base; one pack for the arms, one for compute | 2 | 11200 mAh, DC 5521 | Amazon~$16 eachliyiteng/AlohaMini AlohaMini2/docs/BOM.md line 33 | high |
Servo, STS-3215 (follower arms)Follower arms (x2), AM-ARM200 | 8 | ST-3215-C018, 12V, 1/345 gear | Alibaba$15.97 eachliyiteng/AlohaMini AlohaMini2/docs/BOM.md line 47 | high |
Servo, STS-3095 (follower arms)Follower arms (x2), AM-ARM200 power joints | 6 | ST-3095-C002, 12V, 95 kg·cm | Alibaba$50.37 eachliyiteng/AlohaMini AlohaMini2/docs/BOM.md line 48 | high |
Camera, wristFollower arms | 2 | H65V1, 720p, 2.4 mm, 2 m cable | Amazon~$17 eachliyiteng/AlohaMini AlohaMini2/docs/BOM.md line 52 | high |
Bus servo controller (follower arms)Follower arms | 2 | Waveshare Bus Servo Adapter A | Waveshare$5.00 eachliyiteng/AlohaMini AlohaMini2/docs/BOM.md line 53 | high |
Servo, STS-3215 (leader arms)Leader arms (x2) for teleoperation; not part of the README ~$950 figure | 14 | ST-3215-C046, 7.4V, 1/147 gear | Alibaba$15.97 eachliyiteng/AlohaMini AlohaMini2/docs/BOM.md line 63 | high |
Bus servo controller (leader arms)Leader arms | 2 | Waveshare | Amazon$12.47 eachliyiteng/AlohaMini AlohaMini2/docs/BOM.md line 65 | high |
Power supply 5VLeader arms | 1 | DC 5V AC adapter | Amazon$12.99liyiteng/AlohaMini AlohaMini2/docs/BOM.md line 66 | high |
Epoxy adhesiveFasteners and consumables; bonds chassis segments, tower posts and the shoulder T-frame. Screws, heat-set inserts, pins and small cables are listed upstream | 1 | Loctite E-120HP 50 mL | Amazon~$10liyiteng/AlohaMini AlohaMini2/docs/BOM.md line 80 | high |
3D-printed partsBase, lift tower and camera mounts from AlohaMini2/hardware/mobile_base2; arm parts from liyiteng/AM-ARM; filament not in the BOM.md totals | 1 | PLA/PETG/ABS on a Bambu P2S; README cites ~6 kg filament, BOM.md base row ~4 kg | 3D print yourselfnot included in source totalliyiteng/AlohaMini AlohaMini2/docs/BOM.md line 37 | high |
Rows from the source's own parts list 55
AlohaMini2/docs/BOM.md@17c6a98markdown
| Source row | Qty | Price and vendor | Line |
|---|---|---|---|
Servo, STS-3215 (wheel) | 3 | L16 | |
Servo, STS-3095 (lift) | 1 | L17 | |
Omni wheel | 3 | omniawheel.comTaobaono price listed | L18 |
Aluminum extrusion (T-frame) | 1 | vendor not listedno price listed | L19 |
Steel pin (chassis) | 3 | L20 | |
Steel pin (lift axis) | 1 | L21 | |
Bearing, lift track | 8 | Taobaoitem.taobao.comno price listed | L22 |
Bearing, chassis/arm/lift | 8 | L23 |
39 more rows in AlohaMini2/docs/BOM.md
README.md@17c6a98markdown
| Source row | Qty | Price and vendor | Line |
|---|---|---|---|
Servo, standard | 11 | vendor not listed~$16 | L57 |
Servo, high-torque | 7 | vendor not listed~$50 | L58 |
Bus servo controllers | 2 | vendor not listed~$5 | L59 |
Compute | 1 | vendor not listed~$93 | L60 |
Cameras | 5 | vendor not listed~$17 | L61 |
Omni wheels | 3 | vendor not listed~$40 | L62 |
Battery 12V | 2 | vendor not listed~$16 | L63 |
Frame | - | vendor not listed~6 kg filament | L64 |
How to build
Upstream step marks a step taken from the linked guide.
Print the base parts
Print the mobile_base2 STL parts on a Bambu P2S-class printer in PLA, PETG or ABS, with 4-6 wall loops (6 on load-bearing parts) and 15-25% infill. Use the print-optimized chassis segment; printed pins and T-frame substitutes work but are much weaker than the metal parts.
Upstream stepgithub.com/liyiteng/AlohaMini/blob/17c6a98d79881a45ab869c1f3...Build the arms and set base servo IDs
Build the follower and leader arms with the AM-ARM200 assembly guide. Assign the base servo IDs one at a time before installing them (wheels 10, 9 and 8, lift 11) with the lerobot_alohamini motor tool or the Feetech FD tool at 1000000 baud.
Upstream stepgithub.com/liyiteng/AlohaMini/blob/17c6a98d79881a45ab869c1f3...Build the chassis and omni wheels
Epoxy the chassis parts together with the frame joiners and tapered locking wedges, install the three wheel servos and chain servo 8 to 9, 9 to 10 and 10 to 11 (at least a 90 cm cable between servos 10 and 11, 140 cm recommended). Fit each omni wheel with its connector, axle, 12x18x4 mm bearings and cover, then run the wheel drive test.
Upstream stepgithub.com/liyiteng/AlohaMini/blob/17c6a98d79881a45ab869c1f3...Build the lift tower and shoulder block
Epoxy the tower posts in order, press the hex base into the chassis socket until flush, and route the wheel servo cable through the centre hole. Press the eight 4x13x5 mm track bearings into the shoulder block, insert the 12x25 mm shaft from the right side, fasten the lift gear to the servo output disc with four M3x10 screws, and slide the epoxied T-frame onto the tower rails.
Upstream stepgithub.com/liyiteng/AlohaMini/blob/17c6a98d79881a45ab869c1f3...Mount cameras and arms, route cables
Fit the two top cameras in their printed mounts and the chest camera in the front bracket, and bolt the follower arms to the shoulder T-frame with long M3 screws and nuts. Feed the arm and camera cables through the tower cable ports, connect lift servo 11 to the servo driver board on the left arm with enough slack for full lift travel, and sleeve the left and right bundles.
Upstream stepgithub.com/liyiteng/AlohaMini/blob/17c6a98d79881a45ab869c1f3...Install compute and power, then test
Mount the display on its bracket in the rear dovetail slot, and the Raspberry Pi 5, buck converter, batteries and counterweight in the rear support. Battery 1 feeds both arms through a 2-to-1 splitter; battery 2 feeds the Pi through the buck converter. Then run the wheel and lift debug tests.
Upstream stepgithub.com/liyiteng/AlohaMini/blob/17c6a98d79881a45ab869c1f3...
Wiring, power and firmware are safety-relevant and shown for reference only. Check them against the source before building.
metCAD / mesh present93 editable CAD files (STP) for 71 parts (2 inside archives), including an assembly + 217 mesh files20/20
metBOM evidenceAlohaMini2/docs/BOM.md (4 tables): 42 line items, quantities, priced (USD), vendor links20/20
Quality tier 4 of 5
partialWiring diagramwiring described in text only, no diagram7.5/15
Quality tier 1 of 3
metFirmware linkedcontrol software linked (software source liyiteng/lerobot_alohamini)10/10
Quality tier 2 of 3
metBuild instructionsstep-by-step guide with images15/15
Quality tier 2 of 3
- AlohaMini1/docs/hardware_assembly.md: Assembly (33 steps, 40 images)17c6a98
- AlohaMini1/docs/hardware_assembly.md: Mobile Base Assembly (26 steps, 33 images)17c6a98
- AlohaMini1/docs/hardware_assembly.md: Follower arms and Mobile Base Assembly (7 steps, 7 images)17c6a98
- AlohaMini2/docs/assembly_guide.md: AlohaMini2 Assembly Guide17c6a98
- AlohaMini2/docs/assembly_guide.md: 1. Build the Chassis17c6a98
metOSHW-compatible licenseApache-2.0 (from repository license)10/10
Quality tier 2 of 2
- LICENSE17c6a98
missingKnown reproductionsno verified builds yet0/10
Quality tier 0 of 2
Only build reports a maintainer or admin has reviewed count here.
Engine v3.1.1 at 17c6a98
- The engine could not tell what kind of robot this is from its sources.
Files and sim
- AlohaMini2/hardware/mobile_base2/stp/OB_Chassis_Segment_1of3_PrintOptimized.stp
- AlohaMini2/hardware/mobile_base2/stp/O_Main_Assembly_Post4.stp
- AlohaMini2/hardware/mobile_base2/stp/OB_Main_Assembly_Post3.stp
- AlohaMini2/hardware/mobile_base2/stl/OB_Chassis_Segment_1of3_PrintOptimized.stl
- AlohaMini2/hardware/mobile_base2/stl/O_Main_Assembly_Post4.stl
- AlohaMini2/urdf/alohamini2/urdf/alohamini2.urdf
- AlohaMini2/urdf/alohamini2pro/urdf/alohamini2pro.urdf
- AlohaMini2/docs/BOM.md
- AlohaMini2/docs/assembly_guide.md
- AlohaMini2/docs/print_guide.md
- AlohaMini2/docs/media/assembly/power-wiring.jpg
- am-arm200/stp/follower/OB_F_J3_Shoulder.stp
- am-arm200/bom.md
- src/lerobot/robots/alohamini/alohamini.py
Files stay in the upstream repository under their own licenses; these links open them there. The 3D model on this page is Motari's conversion of the file named under Simulation.
Simulation
Robot description files a simulator or CAD tool can load, linked at the commit they were found.
- URDFAlohaMini2/urdf/alohamini2/urdf/alohamini2.urdfliyiteng/AlohaMini
- URDFAlohaMini1/simulation/src/Aloha/urdf/Aloha.urdfliyiteng/AlohaMini
- URDFAlohaMini2/urdf/alohamini2pro/urdf/alohamini2pro.urdfliyiteng/AlohaMini
The 3D specimen on this page is converted from AlohaMini2/urdf/alohamini2/urdf/alohamini2.urdf at 17c6a98.
Builds
No reviewed builds of AlohaMini yet.
A build log records the evidence (photos, a video, your repository), what the build cost, how long it took and what you changed. Each one is checked by Motari (until a maintainer claims this page) before it shows here, and reviewed builds count toward the reproducibility score.
Sources
Where the facts come from
- Hardwaregithub.com/liyiteng/AlohaMini17c6a98
- Hardwaregithub.com/liyiteng/AM-ARM5b03af1
- Softwaregithub.com/liyiteng/lerobot_alohamini37bee81
- Bill of materialsgithub.com/liyiteng/AlohaMini/blob/main/AlohaMini2/docs/BOM.md17c6a98
- Build guidegithub.com/liyiteng/AlohaMini/blob/main/AlohaMini2/docs/asse...17c6a98
- Build guidegithub.com/liyiteng/AlohaMini/blob/main/AlohaMini2/docs/prin...17c6a98
- Build guidegithub.com/liyiteng/AM-ARM/tree/main/am-arm2005b03af1
- Simulationgithub.com/liyiteng/AlohaMini/tree/main/AlohaMini2/urdf17c6a98
- Storeitem.taobao.com/item.htm
Last push to liyiteng/AlohaMini: 2026-07-01 (checked 2026-10-02)
Related links
- LeRobot integrationliyiteng/lerobot_alohamini, AlohaMini 1/2/2 Pro workflow
- AlohaMini1 (previous version)SO-ARM arms, same repo
How this page was made
Assembled from public sources on 2026-09-30, not yet reviewed by the maintainer. Each figure links to where it is stated; a value the sources do not state reads "not published". Last source review: 2026-09-30 liyiteng/AlohaMini@17c6a98 README, LICENSE, tree.
Original files stay intact and separately licensed; Motari adds only the summary on this page. Maintainer? Request a correction or removal.
Robots like AlohaMini
Shares parts with
Robots whose bill of materials names the same parts, most shared first. Each part links to every robot that uses it.
- XLeRobotRaspberry PiSTS321589
- LeKiwiRaspberry PiSTS321580
- Open Duck MiniRaspberry PiSTS321563
- JPL Open Source RoverRaspberry Pi89
- SO-101STS321583
- SO-ARM100 / SO-ARM101 (Standard Open Arm)STS321583
Parts in this robot's BOM: Raspberry Pi (25 other robots), Feetech STS3215 servo (10 other robots)
Similar robots
The same type of robot, closest first by body plan, published cost and degrees of freedom. All mobile robots
Badge for the README
Maintain AlohaMini? Show its reproducibility score in the project's README. The badge links back to this page and updates with the score.

[](https://motari.io/r/alohamini)<a href="https://motari.io/r/alohamini"><img src="https://motari.io/api/v1/badge/alohamini" alt="Motari reproducibility score for AlohaMini" height="20"></a>Not fully met yet: wiring diagram (partial). The score is read from the project's own sources, so publishing what is missing is what raises it. A score of 90 or more needs a reviewed build. How the score is computed