
GELLO
Low-cost 3D-printed leader arms that mirror a target arm's kinematics for teleoperation.
- $272.18 in partsUR5 GELLO purchased parts in the BOM doc (6 XL330-M288-T, 1 XL330-M077-T, U2D2, power hub, 2 longer cables, power supply, rubber bands, springs); printed parts not priced. Same doc: Franka 287.20, xArm 278.18, YAM Passive 288.24, YAM Active 1349.47 USD. Doc note: prices are listed from the time of the making of this paper, source total
- 7 DoF
- MIThardware
- 73 / 100 reproducibilityPartial source coverage, unverified
What it is
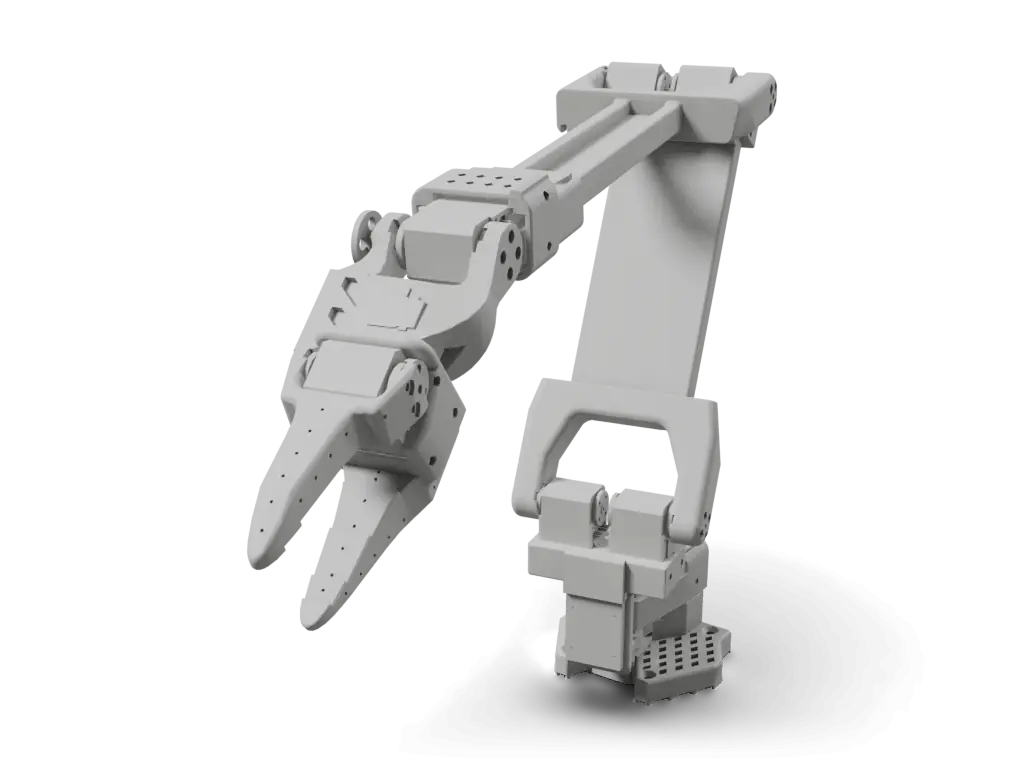
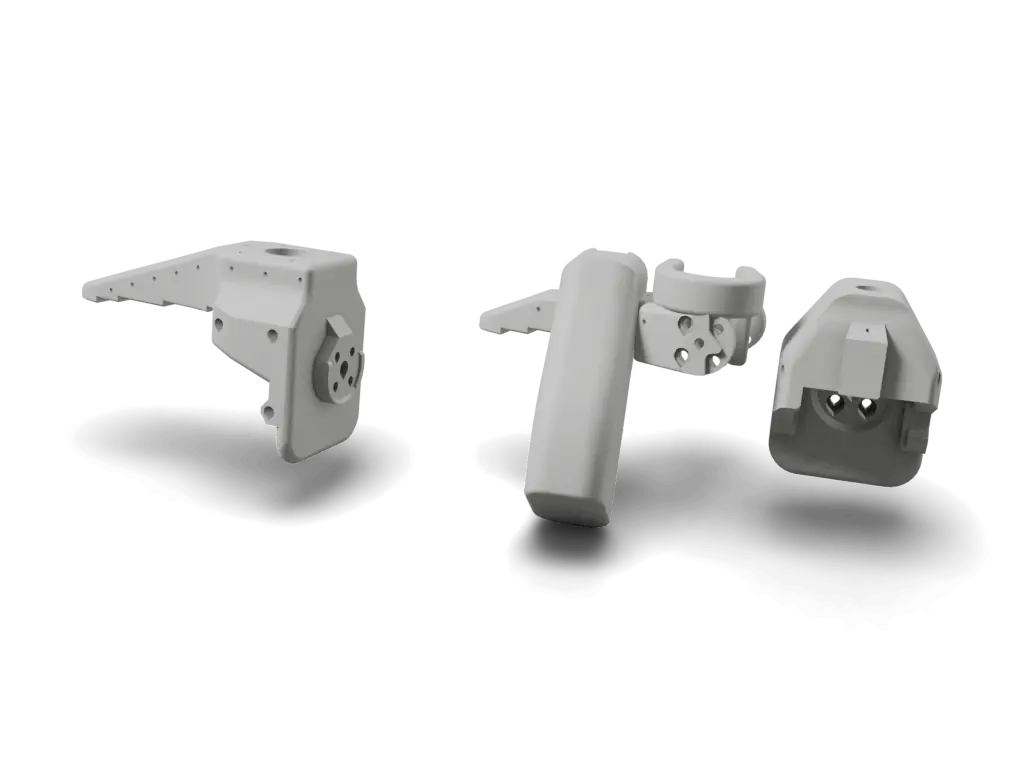
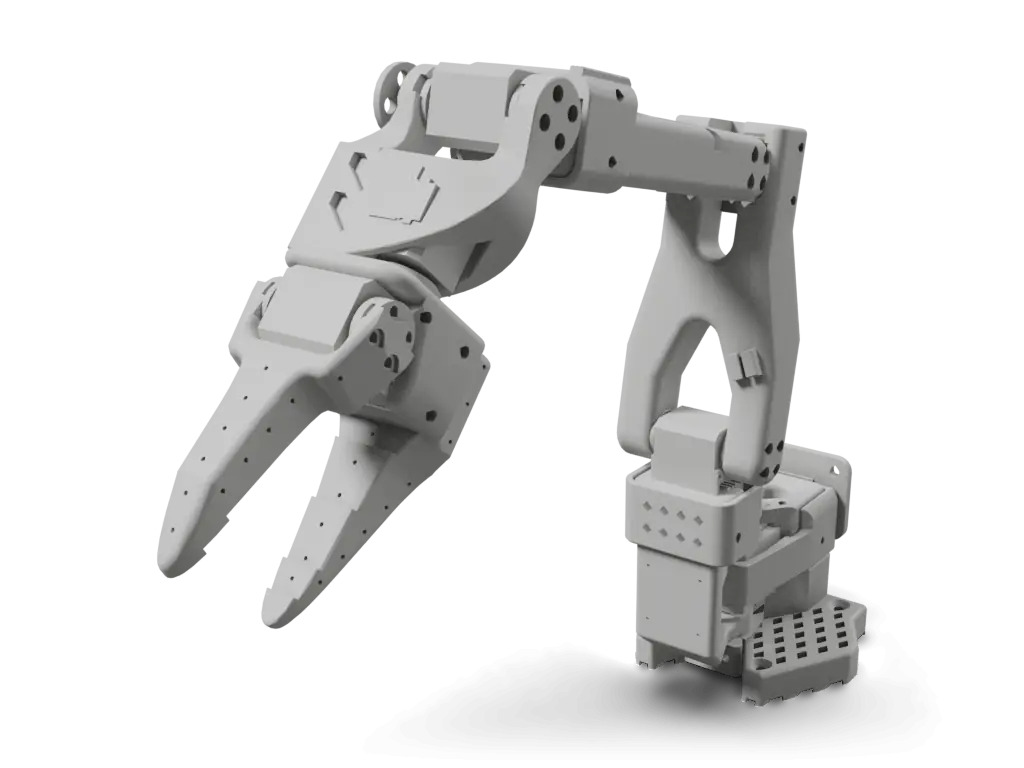
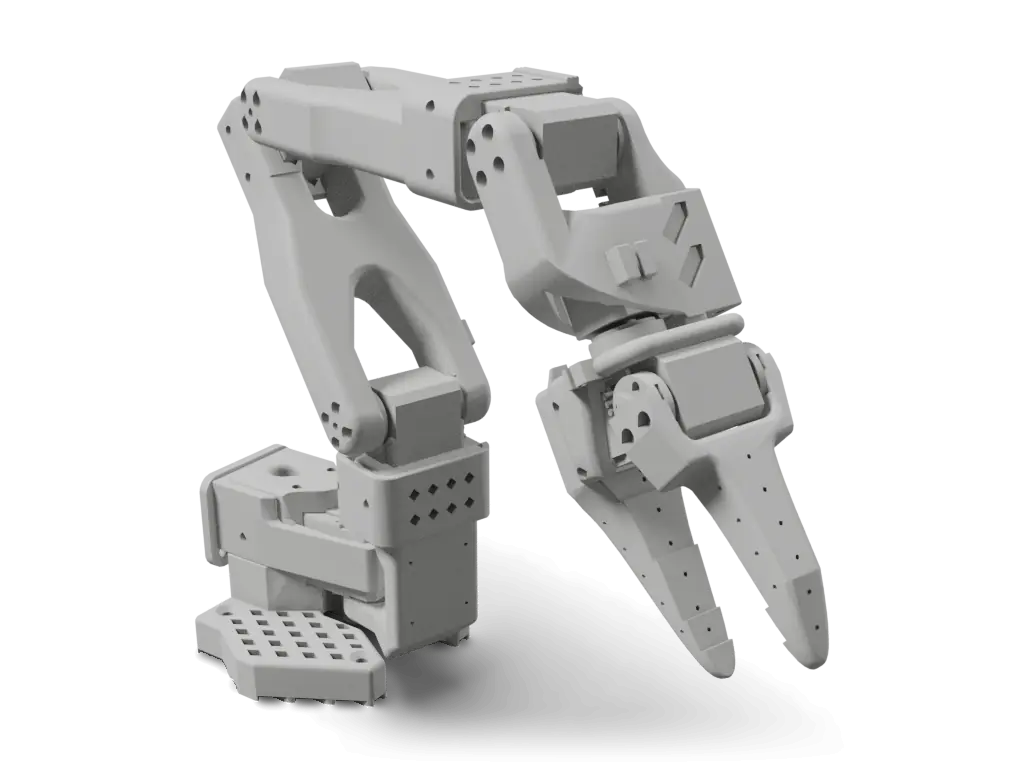
GELLO is a teleoperation framework from UC Berkeley (Philipp Wu, Pieter Abbeel and colleagues): for each target robot it builds a scaled, kinematically equivalent leader arm from 3D-printed links and Dynamixel XL330 servos that act as joint encoders, plus a spring-loaded gripper trigger. The gello_mechanical repo holds printable STLs for seven arm types (Franka FER, UR5 and xArm7 from the paper; YAM, Lite6, AR4 and Franka FR3 from contributors) and a Lite6 leader STEP, while editable CAD for the paper variants is only available by emailing the author. The BOM and assembly instructions live in a Google Doc linked from the README, with per-variant tables priced at the time of the paper. Software is the separate MIT-licensed gello_software repo (Python, DynamixelSDK, ZMQ, plus a ROS 2 stack for the Franka FR3 whose controller packages are Apache-2.0). This page describes the UR5 build: 7 servos (6 joints plus the gripper trigger); the Franka and xArm7 builds use 8. The 3D view shows the community Lite6 leader, the only GELLO with a published assembly.
Licenses
Degrees of freedom
7 DoF arm 6gripper 1
Serial armPassive leader armScaled kinematic replicasource
Auto-assembled, not yet reviewed
Source record
- Sources
- 342 stars, last push 2026-04-10
- HW license
- MIT
- Cost
- $272.18source total, UR5 GELLO purchased parts in the BOM doc (6 XL330-M288-T, 1 XL330-M077-T, U2D2, power hub, 2 longer cables, power supply, rubber bands, springs); printed parts not priced. Same doc: Franka 287.20, xArm 278.18, YAM Passive 288.24, YAM Active 1349.47 USD. Doc note: prices are listed from the time of the making of this paper
- Lifecycle
- Active
- Engine
- v3.1.1
- Checked
- Model
- leader_Lite6.step@8ea3f2erendered 2026-10-02
Maintain GELLO? Claim this page to correct it.
Parts and cost
Cost to build
- UR5 GELLO purchased parts in the BOM doc (6 XL330-M288-T, 1 XL330-M077-T, U2D2, power hub, 2 longer cables, power supply, rubber bands, springs); printed parts not priced. Same doc: Franka 287.20, xArm 278.18, YAM Passive 288.24, YAM Active 1349.47 USD. Doc note: prices are listed from the time of the making of this paper
In the source currency, as read on 2026-09-30. Not converted, and not checked against current vendor prices: none of these is a Motari-verified checkout total.
GELLO parts, as the source lists them. Prices are the source's, not checked against vendors.
| Part | Qty | Spec | Source | Confidence |
|---|---|---|---|---|
DYNAMIXEL XL330-M288-TArm joint servos for the UR5 variant (Franka and xArm tables list 7) | 6 | Robotis XL330 servo used as a joint encoder; $143.40 line total in source table | Robotis$23.90 eachwuphilipp/gello_mechanical README BOM link: Google Doc, Bill of Materials (UR5) table | high |
DYNAMIXEL XL330-M077-TGripper trigger servo | 1 | Robotis XL330 servo; the guide uses the 077-T for the gripper | Robotis$23.90wuphilipp/gello_mechanical README BOM link: Google Doc, Bill of Materials (UR5) table | high |
U2D2USB interface to the Dynamixel bus | 1 | Robotis U2D2 | Robotis$32.10wuphilipp/gello_mechanical README BOM link: Google Doc, Bill of Materials (UR5) table | high |
U2D2 Power Hub Board SetPower distribution for the servo bus | 1 | Robotis U2D2 Power Hub Board Set | Robotis$19.00wuphilipp/gello_mechanical README BOM link: Google Doc, Bill of Materials (UR5) table | high |
Longer CablesExtra-length servo cables for the UR5 variant | 2 | braided 3-pin 450 mm cable per the source link; $17.90 line total | Trossen$8.95 eachwuphilipp/gello_mechanical README BOM link: Google Doc, Bill of Materials (UR5) table | high |
Power SupplySupply for the servo bus | 1 | DC power supply (Amazon listing in source table) | Amazon$16.49wuphilipp/gello_mechanical README BOM link: Google Doc, Bill of Materials (UR5) table | high |
Rubber BandsPassive joint regularization; the guide attaches them to joints 2 and 4 on the UR build | 1 | rubber band pack (Amazon listing in source table) | Amazon$7.99wuphilipp/gello_mechanical README BOM link: Google Doc, Bill of Materials (UR5) table | high |
SpringsGripper trigger spring; same listing as the Springs (Gripper) row in the other variant tables | 1 | spring pack (Amazon listing in source table) | Amazon$11.40wuphilipp/gello_mechanical README BOM link: Google Doc, Bill of Materials (UR5) table | high |
3D-printed partsUR5 base and L1 to L5 plus the shared gripper handle and trigger; the guide suggests supports for most parts. Filament is not priced in the source total | 1 | STLs in ur5/ and gripper/ of gello_mechanical | 3D print yourselfnot listed in source BOMGoogle Doc 3D Printed Parts section; wuphilipp/gello_mechanical tree | high |
Rows from the source's own parts list 9
GELLO build doc, Bill of Materials (UR5)google_doc
| Source row | Qty | Price and vendor | Line |
|---|---|---|---|
DYNAMIXEL XL330-M288-T | 6 | robotis.us$143.40 | L428 |
DYNAMIXEL XL330-M077-T | 1 | robotis.us$23.90 | L435 |
U2D2 | 1 | robotis.us$32.10 | L442 |
U2D2 Power Hub Board Set | 1 | robotis.us$19.00 | L449 |
Longer Cables | 2 | L467 | |
Power Supply | 1 | amazon.com$16.49 | L485 |
Rubber Bands | 1 | amazon.com$7.99 | L492 |
Springs | 1 | amazon.com$11.40 | L499 |
1 more rows in GELLO build doc, Bill of Materials (UR5)
How to build
Upstream step marks a step taken from the linked guide.
Buy the parts for your target arm
Pick your robot in the Bill of Materials section of the build doc. The UR5 GELLO uses 6 Dynamixel XL330-M288-T joint servos, 1 XL330-M077-T gripper servo, a U2D2 with power hub, longer cables, a power supply, rubber bands and springs.
Upstream stepdocs.google.com/document/d/1bdvqPiW4jI5PJm6aIFizhcTuyVJZGEIg...Print the parts
Print the robot-specific STLs plus the gripper handle and trigger, which are shared across robots. The doc shows the suggested print orientation and suggests support for most parts.
Upstream stepdocs.google.com/document/d/1bdvqPiW4jI5PJm6aIFizhcTuyVJZGEIg...Build the arm
Attach the Dynamixels to the printed parts: long screws fix the motor bodies, short screws fix the motor horns. The screws strip easily, so use a well-fitting small Philips screwdriver.
Upstream stepdocs.google.com/document/d/1bdvqPiW4jI5PJm6aIFizhcTuyVJZGEIg...Attach the gripper
Mount the gripper base at the end of the arm, insert the spring into the trigger and attach the trigger to the 077-T Dynamixel.
Upstream stepdocs.google.com/document/d/1bdvqPiW4jI5PJm6aIFizhcTuyVJZGEIg...Wire the servos and controller
Connect the servo cables through the kinematic chain one by one, assemble the Dynamixel controller from its package instructions and attach it to the base.
Upstream stepdocs.google.com/document/d/1bdvqPiW4jI5PJm6aIFizhcTuyVJZGEIg...Add springs or rubber bands
Franka builds get springs on joints 2 and 4; UR and xArm builds get rubber bands on joints 2 and 4.
Upstream stepdocs.google.com/document/d/1bdvqPiW4jI5PJm6aIFizhcTuyVJZGEIg...Set IDs and offsets in software
In gello_software, give each motor a unique ID in Dynamixel Wizard (base to gripper), pose GELLO and the robot in a matching configuration, then run the offset script and add the offsets to your config.
Upstream stepgithub.com/wuphilipp/gello_software/blob/204f53a64bef89471a1...
Wiring, power and firmware are safety-relevant and shown for reference only. Check them against the source before building.
partialCAD / mesh presentonly 3 editable CAD parts against 70 printable parts, no assembly; not the design's CAD source10/20
Quality tier 2 of 3
- ar4/gello-ar4.scad8ea3f2e
- ar4/ring.scad8ea3f2e
- lite6/stp/leader_Lite6.step8ea3f2e
metBOM evidenceReviewedThe README-linked Google Doc's UR5 BOM lists 8 purchased items with vendor, unit cost, quantity, line cost and buy link each, and a 272.18 USD total at the paper's prices. The engine does not open Google Docs.20/20
Quality tier 5 of 5
Reviewed override, 2026-10-02
Evidence on docs.google.comEngine alone: partial at tier 1 (BOM on Google Sheets, not inspected by the engine)
partialWiring diagramReviewedThe Google Doc describes the wiring in text only: run the Dynamixel cables through the arm's kinematic chain, then fit the controller to the base. No diagram. The engine does not open Google Docs.7.5/15
Quality tier 1 of 3
Reviewed override, 2026-10-02
Evidence on docs.google.comEngine alone: missing at tier 0 (no wiring diagram found)
metFirmware linkedcontrol software linked (software source wuphilipp/gello_software)10/10
Quality tier 2 of 3
metBuild instructionsReviewedThe Google Doc gives five written assembly steps with photos of the parts and finished arms. Its build timelapse shows an xArm GELLO, not the UR5 build, so no video is counted. The engine does not open Google Docs.15/15
Quality tier 2 of 3
Reviewed override, 2026-10-02
Evidence on docs.google.comEngine alone: partial at tier 1 (build section in the docs, no step-by-step guide with images)
metOSHW-compatible licenseMIT (from repository license)10/10
Quality tier 2 of 2
- LICENSE8ea3f2e
missingKnown reproductionsno verified builds yet0/10
Quality tier 0 of 2
Only build reports a maintainer or admin has reviewed count here.
Engine v3.1.1 at 8ea3f2e, 3 items reviewed by hand
How this score is computedFiles and sim
- lite6/stp/leader_Lite6.step
- ar4/gello-ar4.scad
- ur5/base.STL
- ur5/L1.STL
- ur5/L2.STL
- ur5/L3.STL
- ur5/L4.STL
- ur5/L5.STL
- gripper/handle.STL
- gripper/trigger.STL
- lite6/README.md
- franka_fr3/README.md
- gello/agents/gello_agent.py
Files stay in the upstream repository under their own licenses; these links open them there. The 3D model on this page is Motari's conversion of the file named under Simulation.
Simulation
Robot description files a simulator or CAD tool can load, linked at the commit they were found.
No URDF, MJCF, SDF, USD or Onshape model has been found in the sources.
The 3D specimen on this page is converted from lite6/stp/leader_Lite6.step at 8ea3f2e.
Builds
No reviewed builds of GELLO yet.
A build log records the evidence (photos, a video, your repository), what the build cost, how long it took and what you changed. Each one is checked by Motari (until a maintainer claims this page) before it shows here, and reviewed builds count toward the reproducibility score.
Sources
Where the facts come from
- Hardwaregithub.com/wuphilipp/gello_mechanical8ea3f2e
- Softwaregithub.com/wuphilipp/gello_software204f53a
- Bill of materialsdocs.google.com/document/d/1bdvqPiW4jI5PJm6aIFizhcTuyVJZGEIg...
- Build guidedocs.google.com/document/d/1bdvqPiW4jI5PJm6aIFizhcTuyVJZGEIg...
- Build guidegithub.com/wuphilipp/gello_mechanical/blob/main/franka_fr3/R...8ea3f2e
- Documentationwuphilipp.github.io/gello_site
- Documentationarxiv.org/abs/2309.13037
Last push to wuphilipp/gello_mechanical: 2026-04-10 (checked 2026-10-02)
How this page was made
Assembled from public sources on 2026-09-30, not yet reviewed by the maintainer. Each figure links to where it is stated; a value the sources do not state reads "not published". Last source review: 2026-09-30 wuphilipp/gello_mechanical@8ea3f2e README, LICENSE, tree.
Original files stay intact and separately licensed; Motari adds only the summary on this page. Maintainer? Request a correction or removal.
Robots like GELLO
Shares parts with
Robots whose bill of materials names the same parts, most shared first. Each part links to every robot that uses it.
- Koch v1.1DynamixelXL33089
- Q8botDynamixelXL33080
- Stack-chanDynamixelXL33080
- TRLC-DK1DynamixelXL33065
- LEAP HandDynamixelXL33063
- RUKA HandDynamixelXL33063
Parts in this robot's BOM: ROBOTIS Dynamixel servos (16 other robots), Dynamixel XL330 servo (6 other robots)
Similar robots
The same type of robot, closest first by body plan, published cost and degrees of freedom. All robot arms
Badge for the README
Maintain GELLO? Show its reproducibility score in the project's README. The badge links back to this page and updates with the score.

[](https://motari.io/r/gello)<a href="https://motari.io/r/gello"><img src="https://motari.io/api/v1/badge/gello" alt="Motari reproducibility score for GELLO" height="20"></a>Not fully met yet: cad / mesh present (partial), wiring diagram (partial). The score is read from the project's own sources, so publishing what is missing is what raises it. A score of 90 or more needs a reviewed build. How the score is computed