
TRLC-DK1
Leader/follower arm dev kit: Damiao-motor follower, Dynamixel leader, LeRobot plugin.
- Cost unknownnot published by the source
- 7 DoF
- Apache-2.0hardware
- 65 / 100 reproducibilityPartial source coverage, unverified
What it is
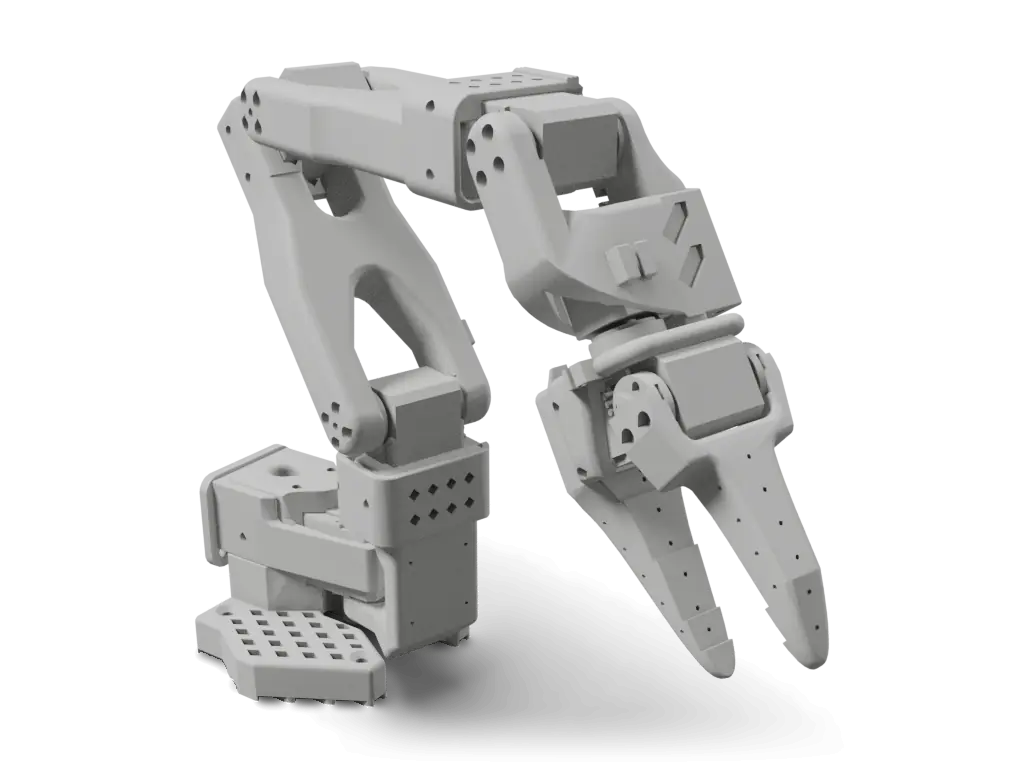
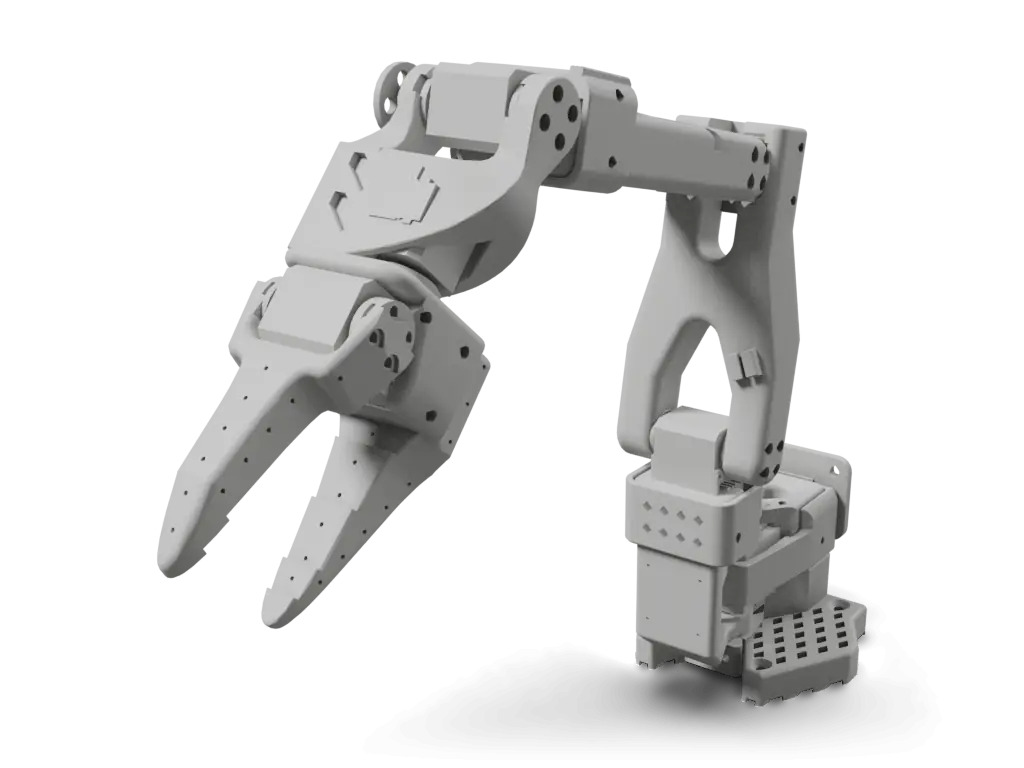
TRLC-DK1 is the open developer kit from The Robot Learning Company: a 6-joint follower arm with a parallel gripper (two prismatic fingers in the URDF), powered by Damiao DM4340 motors on joints 1 to 3 and DM4310 motors on joints 4 to 6 and the gripper over CAN, paired with a passive leader built from seven Dynamixel XL330-M077-T servos and a GELLO-style handle and trigger. The repo carries the v0.3.0 follower STEP assembly (about 42 MB), a follower URDF with GLB visual and STL collision meshes, leader, gripper-finger and framing STLs plus a Bambu Lab 3MF, and a Python package that plugs into LeRobot with position and impedance control and gravity compensation; the leader's v0.2.0 source CAD is only shared as an Autodesk viewer link. The docs site publishes a leader parts list and assembly guide but no follower BOM (the company ships kits fully assembled and calibrated), and no price appears on the repo, docs or company site. The whole repo is under an Apache-2.0 LICENSE, with vendored code credited to DM_Control_Python and GELLO (MIT) and LeRobot (Apache-2.0).
Licenses
- Hardware
- Apache-2.0
- Software
- Apache-2.0
- Docs
- Not published
Degrees of freedom
7 DoF arm 6gripper 1
Serial armLeader-follower pairsource
Auto-assembled, not yet reviewed
Source record
- Source
- 797 stars, last push 2026-07-13
- HW license
- Apache-2.0
- Cost
- not published
- Lifecycle
- Active
- Engine
- v3.1.1
- Checked
- Model
- TRLC-DK1-Follower_v0.3.0.step@12f5368rendered 2026-10-02
- Envelope
- 166 × 255 × 524 mmas modelled, default pose
Maintain TRLC-DK1? Claim this page to correct it.
Parts and cost
Cost to build
The sources do not publish a cost total. The rows below are what they list, without a sum.
TRLC-DK1 parts, as the source lists them. Prices are the source's, not checked against vendors.
| Part | Qty | Spec | Source | Confidence |
|---|---|---|---|---|
Dynamixel XL330-M077-TLeader arm: 6 joint servos plus the gripper trigger servo | 7 | Robotis XL330 servo, all seven leader motors are xl330-m077 in the leader driver | Robotisnot listed in source BOMrobot-learning-co docs, Leader Arm Assembly page, Components table | high |
Waveshare Serial Bus Servo Driver BoardLeader arm servo bus interface | 1 | Waveshare serial bus servo driver board | Amazonnot listed in source BOMrobot-learning-co docs, Leader Arm Assembly page, Components table | high |
3D-printed Links using PLA(-CF)Leader link set; the source table gives no quantity, the STLs and a Bambu Lab 3MF are in hardware/leader_STLs | 1 | PLA-CF recommended, 0.4 mm nozzle, 0.12 mm layers, 15% gyroid infill, supports on | Bambu Lab storenot listed in source BOMrobot-learning-co docs, Leader Arm Assembly page, Components table and 3D Printing section | high |
5V DC Power Supply (2 Pole or 5.5x2.1 Power Jack)Leader arm supply | 1 | 5 V DC, 2-pole or 5.5x2.1 jack | Amazonnot listed in source BOMrobot-learning-co docs, Leader Arm Assembly page, Components table | high |
M2x4 InsertsLeader arm threaded inserts | 4 | M2x4 inserts | Amazonnot listed in source BOMrobot-learning-co docs, Leader Arm Assembly page, Components table | high |
M2x5 Screws (e.g. ISO 4762)Leader arm screws; Dynamixel frame and horn screws come with the servos | 4 | M2x5 socket head, e.g. ISO 4762 | Amazonnot listed in source BOMrobot-learning-co docs, Leader Arm Assembly page, Components table | high |
Rows from the source's own parts list 6
Leader Arm Assembly, Components tablehtml
| Source row | Qty | Price and vendor | Line |
|---|---|---|---|
Dynamixel XL330-M077-T | 7 | en.robotis.comno price listed | L143 |
Waveshare Serial Bus Servo Driver Board | 1 | amazon.comno price listed | L143 |
3D-printed Links using PLA(-CF) | store.bambulab.comno price listed | L143 | |
5V DC Power Supply (2 Pole or 5.5x2.1 Power Jack) | 1 | amazon.comno price listed | L143 |
M2x4 Inserts | 4 | amazon.comno price listed | L143 |
M2x5 Screws (e.g. ISO 4762) | 4 | amazon.comno price listed | L143 |
How to build
Upstream step marks a step taken from the linked guide.
Mount the follower
Mount TRLC-DK1 with table clamps (WORKPRO quick-release clamps) or with M5 screws on 3060 or 4080 aluminium extrusion; the docs give measurements for custom mounts.
Upstream stepdocs.robot-learning.co/1_unboxing_and_setupConnect power and data
Connect the power supply (200 W solo, 450 W bimanual) and the leader and follower power cables. Every follower needs two USB cables, one for the CAN adapter and one for the wrist camera, and the host needs USB 3.0 ports.
Upstream stepdocs.robot-learning.co/1_unboxing_and_setupPrint the leader links
To build or repair a leader, print the leader STLs in PLA-CF with a 0.4 mm nozzle, 0.12 mm layers, 15% gyroid infill and supports on; a Bambu Lab 3MF project is provided.
Upstream stepdocs.robot-learning.co/guides/leaderAssemble the leader
Install the M2 inserts, then assemble every Dynamixel at its absolute zero mark with 4 long screws per frame and 4 short screws per output horn. Choose the regular wrist or the top-down wrist (link4-5-flipped), then mount the GELLO handle and the driver board.
Upstream stepdocs.robot-learning.co/guides/leaderSet up the leader motors
Run the LeRobot motor setup for the dk1_leader, connecting one motor at a time, then daisy-chain all motors.
Upstream stepdocs.robot-learning.co/guides/leaderInstall and teleoperate
Find the leader and follower ports with uv run lerobot-find-port, put leader and follower in the same configuration (a mismatch can cause a fast, aggressive jump), then run uv run lerobot-teleoperate with --robot.type=dk1_follower and --teleop.type=dk1_leader.
Upstream stepdocs.robot-learning.co/3_teleoperation
Wiring, power and firmware are safety-relevant and shown for reference only. Check them against the source before building.
metCAD / mesh present2 editable CAD files (STEP), including an assembly + 37 mesh files20/20
Quality tier 3 of 3
partialBOM evidenceBOM on docs.robot-learning.co, not inspected by the engine10/20
Quality tier 1 of 5
partialWiring diagramReviewedThe docs' Electrical Setup draws the external power wiring of a leader-follower pair (supply, converter, E-stop). The follower's internal CAN wiring is not published, so this is partial.7.5/15
Quality tier 1 of 3
Reviewed override, 2026-10-02
Evidence on docs.robot-learning.coEngine alone: missing at tier 0 (no wiring diagram found)
metFirmware linkedhost control code in the repo, no MCU firmware10/10
Quality tier 2 of 3
- pyproject.toml12f5368
partialBuild instructionsexternal build guide linked, not inspected by the engine7.5/15
Quality tier 1 of 3
metOSHW-compatible licenseApache-2.0 (from repository license)10/10
Quality tier 2 of 2
- LICENSE12f5368
missingKnown reproductionsno verified builds yet0/10
Quality tier 0 of 2
Only build reports a maintainer or admin has reviewed count here.
Engine v3.1.1 at 12f5368, 1 item reviewed by hand
How this score is computedFiles and sim
- urdf/follower/TRLC-DK1-Follower.urdf
- hardware/TRLC-DK1-Follower_v0.3.0.step
- urdf/follower/meshes/visual/base_link.glb
- urdf/follower/meshes/visual/link2-3.glb
- urdf/follower/meshes/collision/link2-3.stl
- hardware/leader_STLs/leader.3mf
- hardware/leader_STLs/link1-2_v0.1.0.stl
- hardware/leader_STLs/gello_handle_45deg.stl
- hardware/follower_gripper_STLs/finger_v0.4.stl
- lerobot_robot_trlc_dk1/follower.py
- lerobot_robot_trlc_dk1/leader.py
- trlc_dk1_control/config.py
Files stay in the upstream repository under their own licenses; these links open them there. The 3D model on this page is Motari's conversion of the file named under Simulation.
Simulation
Robot description files a simulator or CAD tool can load, linked at the commit they were found.
- URDFurdf/follower/TRLC-DK1-Follower.urdfrobot-learning-co/trlc-dk1
The 3D specimen on this page is converted from hardware/TRLC-DK1-Follower_v0.3.0.step at 12f5368.
Builds
No reviewed builds of TRLC-DK1 yet.
A build log records the evidence (photos, a video, your repository), what the build cost, how long it took and what you changed. Each one is checked by Motari (until a maintainer claims this page) before it shows here, and reviewed builds count toward the reproducibility score.
Sources
Where the facts come from
- Hardwaregithub.com/robot-learning-co/trlc-dk112f5368
- Softwaregithub.com/robot-learning-co/trlc-dk112f5368
- Simulationgithub.com/robot-learning-co/trlc-dk1/tree/main/urdf/follower12f5368
- Documentationdocs.robot-learning.co/0_index
- Build guidedocs.robot-learning.co/guides/leader
- Bill of materialsdocs.robot-learning.co/guides/leader
- Storerobot-learning.co
Last push to robot-learning-co/trlc-dk1: 2026-07-13 (checked 2026-10-02)
Related links
- Hardware CADLeader v0.2.0 CAD, Autodesk viewer
- LeRobot integrationLeRobot plugin conventions
- Based onGELLO leader handle, credited upstream
How this page was made
Assembled from public sources on 2026-09-30, not yet reviewed by the maintainer. Each figure links to where it is stated; a value the sources do not state reads "not published". Last source review: 2026-09-30 robot-learning-co/trlc-dk1@12f5368 README, LICENSE, tree.
Original files stay intact and separately licensed; Motari adds only the summary on this page. Maintainer? Request a correction or removal.
Robots like TRLC-DK1
Shares parts with
Robots whose bill of materials names the same parts, most shared first. Each part links to every robot that uses it.
- Koch v1.1DynamixelXL33089
- Q8botDynamixelXL33080
- Stack-chanDynamixelXL33080
- GELLODynamixelXL33073
- LEAP HandDynamixelXL33063
- RUKA HandDynamixelXL33063
Parts in this robot's BOM: ROBOTIS Dynamixel servos (16 other robots), Dynamixel XL330 servo (6 other robots)
Similar robots
The same type of robot, closest first by body plan, published cost and degrees of freedom. All robot arms
Badge for the README
Maintain TRLC-DK1? Show its reproducibility score in the project's README. The badge links back to this page and updates with the score.

[](https://motari.io/r/trlc-dk1)<a href="https://motari.io/r/trlc-dk1"><img src="https://motari.io/api/v1/badge/trlc-dk1" alt="Motari reproducibility score for TRLC-DK1" height="20"></a>Not fully met yet: bom evidence (partial), wiring diagram (partial), build instructions (partial). The score is read from the project's own sources, so publishing what is missing is what raises it. A score of 90 or more needs a reviewed build. How the score is computed