
Legolas (open-source biped)
Cassie-inspired mini hobby-servo biped for learning RL locomotion, with full SolidWorks CAD and STLs.
- Cost unknownnot published by the source
- 10 DoF
- MIThardware
- 65 / 100 reproducibilityPartial source coverage, unverified
What it is
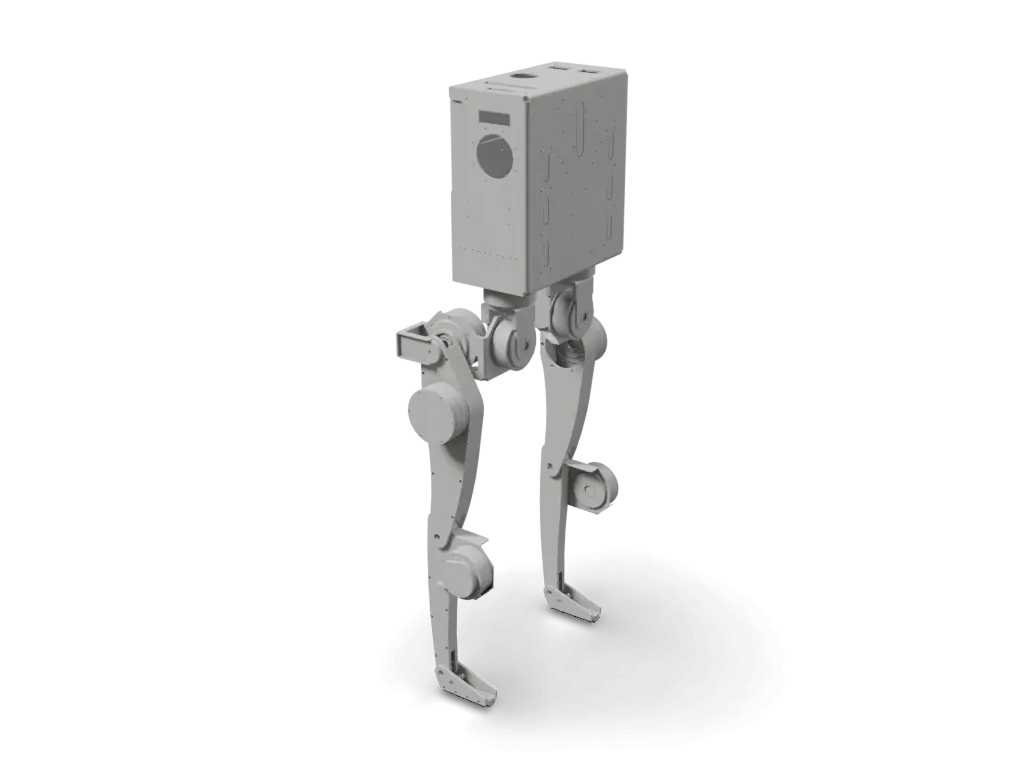
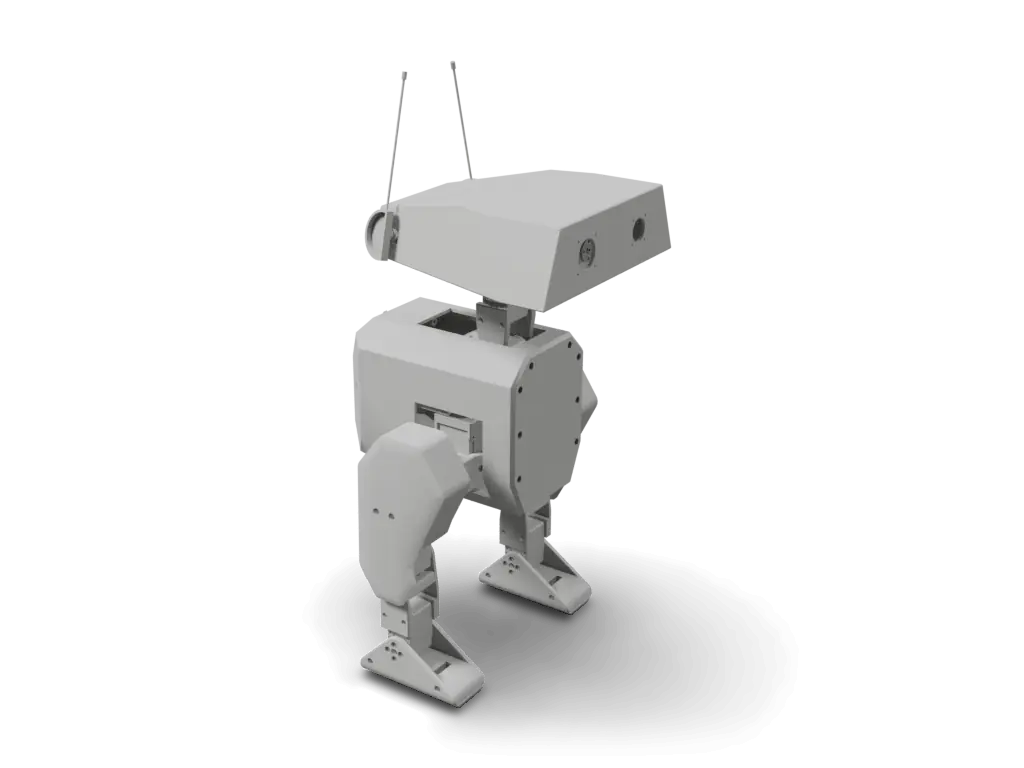
Legolas is a mini bipedal robot by David Doan, inspired by Agility Robotics' Cassie, intended as an open platform for learning and applying reinforcement learning to legged locomotion. The hardware repository contains the SolidWorks CAD (V1/V2/V3 iterations, including a redundant right-leg mirror and a test bench) plus a complete set of printable STLs for V2, and a MuJoCo model of an older version (the other XML file is Agility Robotics' Cassie reference model). Actuation is low-cost hobby servos (8x 40 kg-cm and 2x 80 kg-cm) driven by a PCA9685 board from a Raspberry Pi 4, with an MPU6050 IMU and three ADS1115 ADCs, M4 connecting-rod / ball-joint linkages, and thrust bearings. The BOM is provided as linked Amazon parts rather than a costed table, and step-by-step assembly instructions are noted as a future addition. The control code lives in a separate Legolas_Controller repository. The repo was last updated in May 2024 and the assembly instructions were never published.
Licenses
Degrees of freedom
10 DoF legs 10
Bipedsource
Auto-assembled, not yet reviewed
Source record
Maintain Legolas (open-source biped)? Claim this page to correct it.
Parts and cost
Cost to build
The sources do not publish a cost total. The rows below are what they list, without a sum.
Legolas (open-source biped) parts, as the source lists them. Prices are the source's, not checked against vendors.
| Part | Qty | Spec | Source | Confidence |
|---|---|---|---|---|
40 kg-cm hobby servomain leg actuators | 8 | high-torque digital servo, waterproof | Amazon (generic)price not listedREADME.md line 55 | high |
80 kg-cm hobby servohigh-load joints | 2 | digital high-torque servo | Amazon (GoolRC)price not listedREADME.md line 56 | high |
Raspberry Pi 4onboard controller | 1 | quad-core SBC | Amazonprice not listedREADME.md line 53 | high |
PCA9685 servo driver16-channel PWM driver | 1 | I2C PWM servo board | Amazonprice not listedREADME.md line 54 | high |
MPU6050 IMU6-axis accel/gyro | 1 | I2C IMU | Amazonprice not listedREADME.md line 57 | high |
ADS1115 ADCThe controller code reads the 10 servo potentiometers through three ADS1115 boards; the README gives no quantity | 3 | I2C 4-channel ADC | Amazonprice not listedREADME.md line 58 | high |
M4 ball-joint rod ends + threaded rodlinkage hardware | 1 | M4 rod ends, M4 threaded rod | Amazonprice not listedREADME.md lines 48-49 | med |
Thrust bearingsListed in the README; placement not stated upstream | 1 | thrust bearing set | Amazonprice not listedREADME.md line 47 | med |
3D printing filament + fastener kit1 kg filament + M2-M5 bolts/locknuts | 1 | 1 kg of 3D printing filament (material not named upstream); assorted metric hardware | Amazonprice not listedREADME.md lines 44-46 | med |
Jumper wireselectronics wiring | 1 | breadboard jumper wire assortment | Amazon / Elegooprice not listedREADME.md line 59 | med |
Power DIY connectorpower harness connector | 1 | DIY power connector | Amazonprice not listedREADME.md line 60 | med |
USB-C connectorelectronics connector | 1 | USB-C connector module | Amazonprice not listedREADME.md line 61 | med |
4-to-1 wire connectorelectronics connector | 1 | 4-to-1 wire connector | Amazonprice not listedREADME.md line 62 | med |
Rows from the source's own parts list 3
README.md@045709emarkdown
| Source row | Qty | Price and vendor | Line |
|---|---|---|---|
main body printed material and linkage hardware | 1 kg filament; other quantities not enumerated | Amazon-linked partsno price listed | L44 |
controller, servo driver, servos, IMU, and ADC | 8 40 kg servos; 2 80 kg servos; single linked boards unless otherwise noted | Amazon-linked partsno price listed | L53 |
electronics wiring and connector accessories | single linked line items; quantities not enumerated | Amazon-linked partsno price listed | L59 |
How to build
Steps marked Motari summary condense the linked source; follow the source for exact instructions. Upstream step marks a step taken from the linked guide.
Get the CAD or STLs
Clone the repo and either edit the SolidWorks V2/V3 parts or print the ready STLs in CAD/Legolas/V2/STLs.
Motari summarygithub.com/daviddoo02/Legolas-an-open-source-bipedPrint the structural parts
Print the STL files in CAD/Legolas/V2/STLs (thigh, foreleg, shin, foot, hip, main body, servo cover and shoe parts). The README lists 1 kg of 3D printing filament without naming a material. A V3 folder holds SolidWorks-only revisions of some parts.
Motari summarygithub.com/daviddoo02/Legolas-an-open-source-bipedSource electronics
Order the 8x 40 kg + 2x 80 kg servos, Raspberry Pi 4, PCA9685, MPU6050, ADS1115 and linkage hardware from the linked Amazon parts.
Upstream stepgithub.com/daviddoo02/Legolas-an-open-source-biped/blob/0457...Assemble the legs
No assembly instructions are published: the README says they will be added in future updates. Use the SolidWorks assemblies as the reference for building the linkages from the ball joint rod ends and M4 threaded rod and for mounting the servos.
Motari summarygithub.com/daviddoo02/Legolas-an-open-source-bipedRun the controller
Clone Legolas_Controller into a ROS Noetic workspace, build it with catkin_make and launch the walking gait demo, which plays a precomputed inverse-kinematics gait.
Motari summarygithub.com/daviddoo02/Legolas-an-open-source-biped
Wiring, power and firmware are safety-relevant and shown for reference only. Check them against the source before building.
metCAD / mesh present32 editable CAD files (SLDASM/SLDPRT), including an assembly + 59 mesh files20/20
Quality tier 3 of 3
partialBOM evidenceReviewedREADME "Required Materials" lists 16 parts, each with an Amazon link; only 3 give quantities and there are no prices or total. It is a Markdown list, so the engine missed it.10/20
Quality tier 2 of 5
partialWiring diagramwiring described in text only, no diagram7.5/15
Quality tier 1 of 3
metFirmware linkedcontrol software linked (software source daviddoo02/Legolas_Controller)10/10
partialBuild instructionsbuild section in the docs, no step-by-step guide with images7.5/15
Quality tier 1 of 3
metOSHW-compatible licenseMIT (from repository license)10/10
Quality tier 2 of 2
- LICENSE045709e
missingKnown reproductionsno verified builds yet0/10
Quality tier 0 of 2
Only build reports a maintainer or admin has reviewed count here.
Engine v3.1.1 at 045709e, 1 item reviewed by hand
How this score is computedFiles and sim
- CAD/Legolas/V1/Legolas_v1.SLDASM
- CAD/Legolas/V2/Full Assembly.SLDASM
- CAD/Legolas/V2/Legolas V2 Left Leg.SLDASM
- Mujoco xml/References/agility_cassie/assets/pelvis.obj
- CAD/Legolas/V2/STLs/Main body Wire Connector Container.STL
- CAD/Legolas/V2/STLs/Main body.STL
- README.md
- Mujoco xml/References/agility_cassie/README.md
Files stay in the upstream repository under their own licenses; these links open them there. The 3D model on this page is Motari's conversion of the file named under Simulation.
Simulation
Robot description files a simulator or CAD tool can load, linked at the commit they were found.
- MJCF (MuJoCo)Mujoco xml/Working Mk 5 - Old model - Demo only/CMU Mk 5.xmldaviddoo02/Legolas-an-open-source-biped
The 3D specimen on this page is converted from Mujoco xml/Working Mk 5 - Old model - Demo only/CMU Mk 5.xml at 045709e.
Builds
No reviewed builds of Legolas (open-source biped) yet.
A build log records the evidence (photos, a video, your repository), what the build cost, how long it took and what you changed. Each one is checked by Motari (until a maintainer claims this page) before it shows here, and reviewed builds count toward the reproducibility score.
Sources
Where the facts come from
- Hardwaregithub.com/daviddoo02/Legolas-an-open-source-biped045709e
- Softwaregithub.com/daviddoo02/Legolas_Controller3bfe2d7
Last push to daviddoo02/Legolas-an-open-source-biped: 2024-05-04 (checked 2026-10-01)
How this page was made
Assembled from public sources on 2026-06-04, not yet reviewed by the maintainer. Each figure links to where it is stated; a value the sources do not state reads "not published". Last source review: README 045709e source materials parsed.
Original files stay intact and separately licensed; Motari adds only the summary on this page. Maintainer? Request a correction or removal.
Robots like Legolas (open-source biped)
Shares parts with
Robots whose bill of materials names the same parts, most shared first. Each part links to every robot that uses it.
- JPL Open Source RoverRaspberry Pi89
- XLeRobotRaspberry Pi89
- AlohaMiniRaspberry Pi83
- UpkieRaspberry Pi83
- AndinoRaspberry Pi80
- Asimov 1Raspberry Pi80
Parts in this robot's BOM: Raspberry Pi (25 other robots)
Similar robots
The same type of robot, closest first by body plan, published cost and degrees of freedom. All humanoid robots
Badge for the README
Maintain Legolas (open-source biped)? Show its reproducibility score in the project's README. The badge links back to this page and updates with the score.

[](https://motari.io/r/legolas-biped)<a href="https://motari.io/r/legolas-biped"><img src="https://motari.io/api/v1/badge/legolas-biped" alt="Motari reproducibility score for Legolas (open-source biped)" height="20"></a>Not fully met yet: bom evidence (partial), wiring diagram (partial), build instructions (partial). The score is read from the project's own sources, so publishing what is missing is what raises it. A score of 90 or more needs a reviewed build. How the score is computed