
LEAP Hand v2 Advanced
CMU's 17-motor hybrid rigid-soft hand with a powered palm and printed TPU and PLA fingers; the simpler 8-motor LEAP Hand v2 is a separate design.
- $4,079.88 in partsprinted palm and gear parts, parts page as of Dec 2024, source total
- 17 DoF
- CC BY-NC-SA (version not stated)NChardware, non-commercial
- 73 / 100 reproducibilityPartial source coverage, unverified
What it is
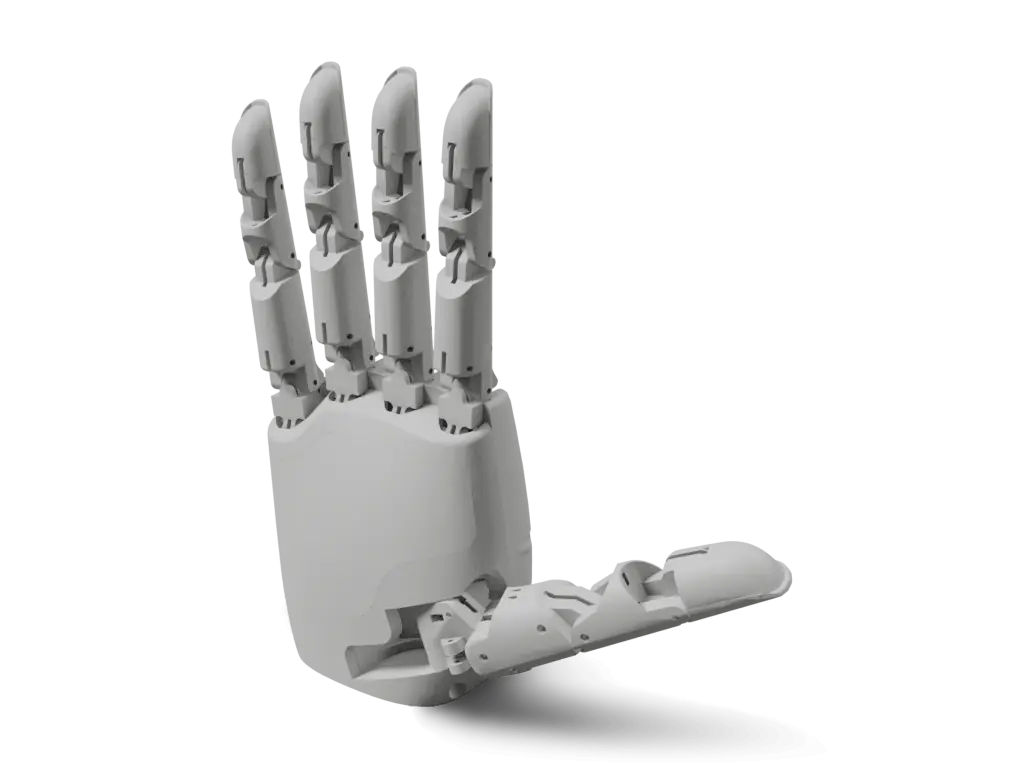
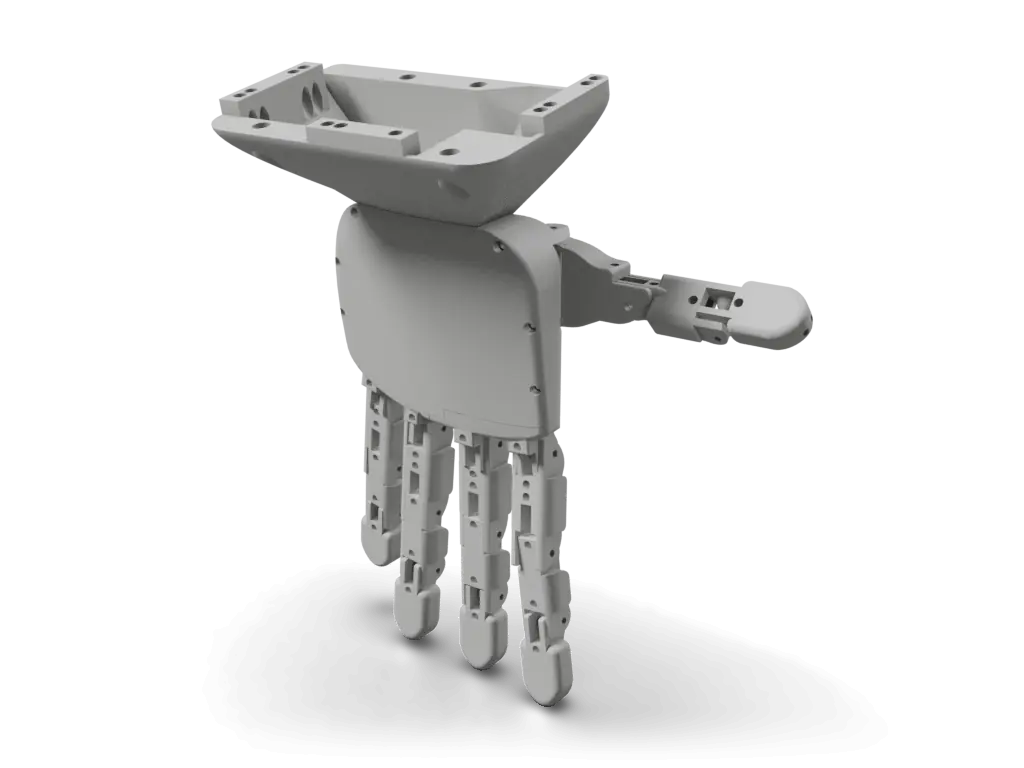
LEAP Hand v2 Advanced is a dexterous hand from Kenneth Shaw and Deepak Pathak at Carnegie Mellon University. Its fingers are multi-material prints, a soft TPU skin over a PLA bone structure, and 17 Dynamixel motors drive it: for each finger and the thumb an XC330 for the side-to-side MCP joint, an XM430-W210 for MCP flexion and an XM430-W350 that curls the coupled PIP and DIP joints through a tendon, plus two powered palm articulations (the project counts 21 DoF, 17 of them powered). The project site publishes left and right full-assembly STEP files, per-part STEP and 3MF print files, URDFs, a parts list totalling 4,079.88 USD with printed palm parts or 5,079.88 USD with the recommended aluminum parts (December 2024 prices) and an illustrated assembly guide; the LEAP_Hand_V2_Adv_API repository holds the ROS 2 control node, a tendon alignment script and the URDFs. The CAD is released under a non-commercial CC BY-NC-SA license. It is distinct from LEAP Hand v2, a simpler 8-motor hand of 200 to 300 USD whose CAD release page reads coming soon; leaphand.com calls v2 Advanced fully released and v2 a preview. The 3D view is the right-hand full-assembly STEP from the project site.
Licenses
- Hardware
- CC BY-NC-SA (version not stated)NC
- Software
- Apache-2.0
- Docs
- Not published
Degrees of freedom
17 DoF curl 5palm 2mcpSide 5mcpForward 5
Dexterous handAnthropomorphic handTendon-drivensource
Auto-assembled, not yet reviewed
Source record
- Source
- 13 stars, last push 2025-06-13
- HW license
- CC BY-NC-SA (version not stated)NC
- Cost
- $4,079.88source total, printed palm and gear parts, parts page as of Dec 2024
- Lifecycle
- Active
- Engine
- v3.1.1
- Checked
- Model
- README.md@a093619rendered 2026-10-02
- Envelope
- 246 × 222 × 199 mmas modelled, default pose
Maintain LEAP Hand v2 Advanced? Claim this page to correct it.
Parts and cost
Cost to build
- printed palm and gear parts, parts page as of Dec 2024
- with the PCBWay aluminum palm and gear parts (1000 USD), parts page as of Dec 2024
In the source currency, as read on 2026-10-02. Not converted, and not checked against current vendor prices: none of these is a Motari-verified checkout total.
LEAP Hand v2 Advanced parts, as the source lists them. Prices are the source's, not checked against vendors.
| Part | Qty | Spec | Source | Confidence |
|---|---|---|---|---|
DYNAMIXEL XM430-W210-TFive MCP forward motors (one per finger and thumb) plus one palm motor | 6 | Robotis XM430-W210-T; $1619.40 line total in source table | Robotis$269.90 eachv2-adv.leaphand.com Parts page table (prices as of Dec 2024) | high |
DYNAMIXEL XM430-W350-TFive tendon pulley motors plus one palm motor | 6 | Robotis XM430-W350-T; $1619.40 line total in source table | Robotis$269.90 eachv2-adv.leaphand.com Parts page table (prices as of Dec 2024) | high |
DYNAMIXEL XC330-T288-TMCP side motors, one per finger and thumb | 5 | Robotis XC330-T288-T; $449.95 line total in source table | Robotis$89.99 eachv2-adv.leaphand.com Parts page table (prices as of Dec 2024) | high |
DYNAMIXEL HN12-I101 SetPressed onto the two palm motors | 2 | Robotis HN12-I101 idler set; $35.60 line total in source table | Robotis$17.80 eachv2-adv.leaphand.com Parts page table (prices as of Dec 2024) | high |
DYNAMIXEL FPX330-H101Bought for its BHS M2.6x6 mm and M2x4 mm TAP screws | 1 | Robotis FPX330-H101 4-piece set | Robotis$9.80v2-adv.leaphand.com Parts page table (prices as of Dec 2024) | high |
DYNAMIXEL U2D2USB interface to the motor bus | 1 | Robotis U2D2 | Robotis$32.10v2-adv.leaphand.com Parts page table (prices as of Dec 2024) | high |
DYNAMIXEL Power HubThe page suggests the LEAP Power hub or a custom power cable instead | 1 | Robotis U2D2 Power Hub Board Set | Robotis$19.00v2-adv.leaphand.com Parts page table (prices as of Dec 2024) | high |
Long 180mm Dynamixel cableOne cable per MCP side motor | 1 | Robotis 180 mm X3P cable pack | Robotis$19.00v2-adv.leaphand.com Parts page table (prices as of Dec 2024) | high |
XT30 PigtailFor building your own power cable instead of the power hub | 1 | XT30 pigtail | Amazon$9.00v2-adv.leaphand.com Parts page table (prices as of Dec 2024) | high |
Berkley Trilene Big Game Monofilament Fishing LineTendons, about 60 cm per finger | 1 | 100 lb mono leader, 0.99 mm | Amazon$12.99v2-adv.leaphand.com Parts page table (prices as of Dec 2024) | high |
M3 22mmScrew gear screws | 1 | M3 22 mm screws | Amazon$8.99v2-adv.leaphand.com Parts page table (prices as of Dec 2024) | high |
M3 6mm 3D printer InsertsHeat-set inserts for the mounts and palm | 5 | M3 6 mm heat-set inserts, variety pack; $19.00 line total in source table | Amazon$19.00v2-adv.leaphand.com Parts page table (prices as of Dec 2024) | high |
6701-2RS Bearings 12mm x 18mm x 4mmOne per MCP holder inner and outer | 1 | 6701-2RS bearing, 10 pack | Amazon$9.39v2-adv.leaphand.com Parts page table (prices as of Dec 2024) | high |
Synthetic GreaseBetween each screw bushing and screw gear | 1 | synthetic grease | Amazon$8.41v2-adv.leaphand.com Parts page table (prices as of Dec 2024) | high |
High-Strength Threadlocker 271Red threadlocker on the screw gear screws | 1 | threadlocker 271 | Amazon$7.99v2-adv.leaphand.com Parts page table (prices as of Dec 2024) | high |
Polymaker PLA Pro 1 Black and 1 White Roll SetPLA for the rigid printed parts | 1 | PLA filament, two rolls | Amazon$47.99v2-adv.leaphand.com Parts page table (prices as of Dec 2024) | high |
Polymaker Polydissolve PLADissolvable support filament | 1 | PVA support filament | Amazon$59.99v2-adv.leaphand.com Parts page table (prices as of Dec 2024) | high |
Recreus Filaflex Foamy Natural 1.75mm 600gFoaming TPU for the soft finger and palm skin | 1 | Filaflex Foamy TPU, 1.75 mm, 600 g | Recreus$54.90v2-adv.leaphand.com Parts page table (prices as of Dec 2024) | high |
Power Supply (12v 20a)Supply for the motor bus | 1 | 12 V 20 A power supply | Amazon$19.99v2-adv.leaphand.com Parts page table (prices as of Dec 2024) | high |
Power Cable AC (Change for your Country)Mains cable for the supply | 1 | AC power cable | Amazon$7.00v2-adv.leaphand.com Parts page table (prices as of Dec 2024) | high |
14 AWG 5v CablePower wiring | 1 | 14 AWG cable | Amazon$9.99v2-adv.leaphand.com Parts page table (prices as of Dec 2024) | high |
Rows from the source's own parts list 23
partshtml
| Source row | Qty | Price and vendor | Line |
|---|---|---|---|
DYNAMIXEL XM430-W210-T | 6 | robotis.us$1619.40 | L170 |
DYNAMIXEL XM430-W350-T | 6 | robotis.us$1619.40 | L181 |
DYNAMIXEL XC330-T288-T | 5 | robotis.us$449.95 | L191 |
DYNAMIXEL HN12-I101 Set | 2 | robotis.us$35.60 | L202 |
DYNAMIXEL FPX330-H101 | 1 | robotis.us$9.80 | L215 |
DYNAMIXEL U2D2 | 1 | robotis.us$32.10 | L228 |
DYNAMIXEL Power Hub | 1 | robotis.us$19.00 | L239 |
Long 180mm Dynamixel cable | 1 | robotis.us$19.00 | L251 |
15 more rows in parts
How to build
Upstream step marks a step taken from the linked guide.
Buy the parts
Order the motors and parts on the parts page: 6 XM430-W210-T, 6 XM430-W350-T and 5 XC330-T288-T Dynamixels, two HN12-I101 sets, an FPX330-H101 set for its TAP screws, a U2D2 with a power hub, 180 mm cables, 100 lb fishing line for the tendons, M3 screws and inserts, 6701-2RS bearings, grease, threadlocker 271, PLA, dissolvable support, Filaflex Foamy TPU and a 12 V 20 A supply.
Upstream stepv2-adv.leaphand.com/partsPrint or order the parts
Have the palm, gear and MCP parts 3D printed in aluminum (the CAD page recommends PCBWay, about 1000 USD) or print the PLA versions. Print the fingers and upper palms in Filaflex Foamy TPU and PLA on a dual-nozzle Snapmaker J1S with a 0.2 mm nozzle for the PLA, from the provided 3MF projects, and the remaining PLA parts on any printer.
Upstream stepv2-adv.leaphand.com/leap_cadBuild the MCP holders
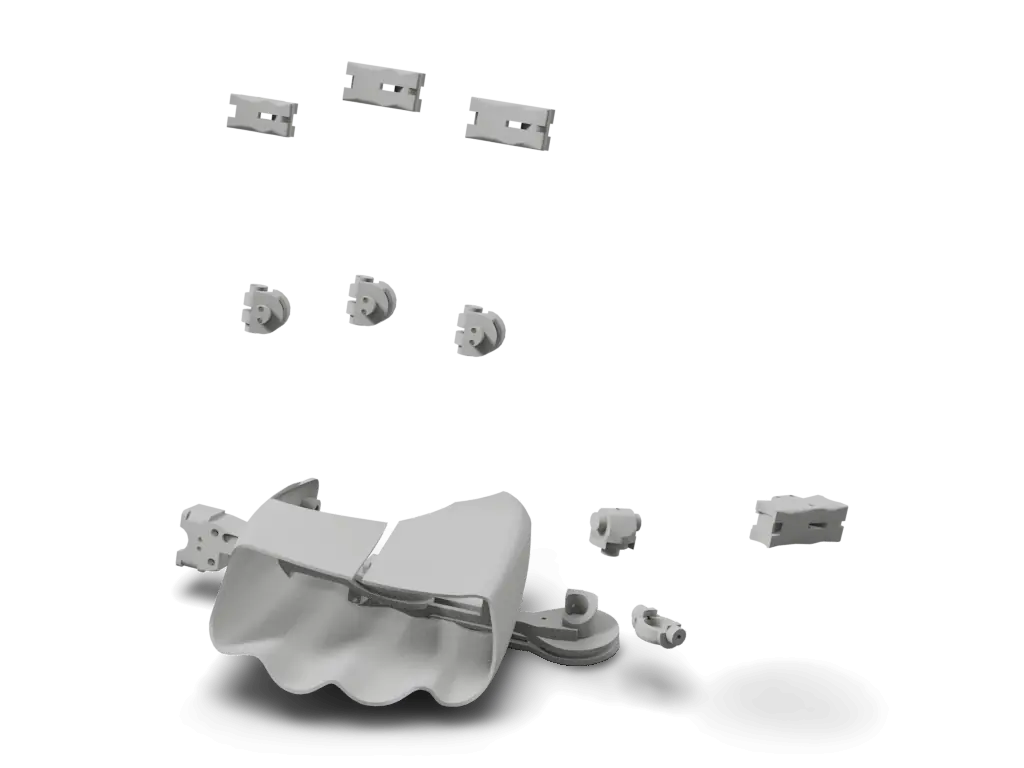
Press a bearing into each MCP holder inner and outer, pair them, fit an MCP forward between the bearings with an axle gear on the axle so the gears mesh and the tendon hole lines up with the holder's tendon channel, and fix each with an M2.5 20 mm bolt. Make three of one orientation and two mirrored, then fix them into the four-finger and thumb lower palms with two 20 mm bolts and two M2 6 mm screws each.
Upstream stepv2-adv.leaphand.com/assemblyFit the MCP motors and gears
Fasten a horn gear to each of the five XM430-W210-T motors with M2.5 10 mm screws (three normal, two mirrored). Replace one corner screw of each motor (toward the front of the hand for index and pinky, toward the back for middle and ring) with a screw bushing and screw gear, greased between them, and tighten it hard with an M2.5 22 mm screw and red Loctite, then fix the motors to the lower palms.
Upstream stepv2-adv.leaphand.com/assemblyBreak in the MCP gears
Check that the four M2 screws of each MCP forward assembly are tight and the motors are fastened securely. Connect one of the MCP motors to a 12V power source, a U2D2, and the Dynamixel Wizard software on your computer, scan for the motor and switch it to current control mode. Turn the torque on and move the MCP module forward and backward using the current control slider (if it does not move, push with your hands in the direction the motor pushes) until the motor and joint spin more smoothly. Repeat for the other four motors.
Upstream stepv2-adv.leaphand.com/assemblyFit the tendon motors
Fit the horns and pulleys on the five XM430-W350-T motors with a roughly 60 cm double-knotted fishing-line tendon in each pulley. Push each tendon through the bottom hole of its MCP forward and into the MCP holder's tendon channel, fix the motors to the lower palm, and slide the four-fingers bottom over the middle and ring finger motors without pinching any tendon.
Upstream stepv2-adv.leaphand.com/assemblyFit the MCP side motors and fingers
With each XC330-T288-T horn in its home position, insert the motors into the five MCP forwards with the M2 4 mm TAP screws, add the MCP spacers with M2.6 6 mm TAP screws and plug a long cable into each. Thread each tendon through the center channel of its finger, double-knot it, push the finger firmly onto its motor and fix it with four M2 8 mm TAP screws.
Upstream stepv2-adv.leaphand.com/assemblyJoin the palm and mount the hand
Press an HN12-I101 onto the palm XM430-W350-T and XM430-W210-T, join the three lower palms through them, slot on the three upper palms with M3 6 mm screws, fit the U2D2 under its cover on brass inserts, and mount the hand to the arm through the four-fingers bottom mount with M3 screws to the hand and M6 screws to the arm.
Upstream stepv2-adv.leaphand.com/assemblySet IDs and wire the bus
Program the motor IDs as for LEAP Hand v1: index 0 to 2, middle 3 to 5, ring 6 to 8, pinky 9 to 11, thumb 12 to 14, palm thumb 15 and palm four fingers 16. Chain the bus from a central eight-way power splitter with the MCP side and palm motors as the end points, and zip-tie the MCP side cables to the front of the fingers, in front of the logo bar: the guide warns that MCP side cables pulled out or caught in the gears as the MCP moves can damage the motors.
Upstream stepv2-adv.leaphand.com/assemblyPower on and tension the tendons
When powering on the hand for the first time and running the tensioning script, make sure the tendons sit in the pulley grooves: index and pinky wrap toward the front of the hand, middle and ring toward the back. The LEAP Hand v2 Advanced API covers the software.
Upstream stepv2-adv.leaphand.com/assembly
Wiring, power and firmware are safety-relevant and shown for reference only. Check them against the source before building.
metCAD / mesh presentReviewedThe CAD page serves left and right full-assembly STEP files, per-part STEP and 3MF print files and URDFs after a short form; the right-hand STEP was downloaded and opened. The engine does not open leaphand.com.20/20
Quality tier 3 of 3
Reviewed override, 2026-10-02
Evidence on v2-adv.leaphand.comEngine alone: partial at tier 1 (hardware files on v2-adv.leaphand.com, not inspected by the engine)
metBOM evidenceReviewedThe parts page lists 21 items with quantity, unit price, line total and buy link, and totals of 4,079.88 USD (printed parts) and 5,079.88 USD (metal parts) as of December 2024. The engine does not open leaphand.com.20/20
Quality tier 5 of 5
Reviewed override, 2026-10-02
Evidence on v2-adv.leaphand.comEngine alone: partial at tier 1 (BOM on v2-adv.leaphand.com, not inspected by the engine)
partialWiring diagramReviewedThe assembly page describes the wiring in text only: a central eight-way power splitter, the bus chained out to the MCP side and palm motors, the U2D2, and an ID table. Its only wiring image is a photo.7.5/15
Quality tier 1 of 3
Reviewed override, 2026-10-02
Evidence on v2-adv.leaphand.comEngine alone: missing at tier 0 (no wiring diagram found)
metFirmware linkedcontrol software linked (software source leap-hand/LEAP_Hand_V2_Adv_API)10/10
metBuild instructionsReviewedThe assembly page is a written step-by-step guide with photos for every stage, from the MCP holders and gears through tendons, fingers, palm, mounts and IDs. No build video. The engine does not open leaphand.com.15/15
Quality tier 2 of 3
Reviewed override, 2026-10-02
Evidence on v2-adv.leaphand.comEngine alone: partial at tier 1 (external build guide linked, not inspected by the engine)
missingOSHW-compatible licenseno hardware license detected0/10
Quality tier 0 of 2
The engine found nothing to point at for this item.
missingKnown reproductionsno verified builds yet0/10
Quality tier 0 of 2
Only build reports a maintainer or admin has reviewed count here.
Engine v3.1.1 at a093619, 4 items reviewed by hand
- The engine found no license file for the hardware in the hardware source.
Files and sim
- v2-adv.leaphand.com/static/cad/full_hand/leap_v2_full_assembly_right.stp
- v2-adv.leaphand.com/static/cad/full_hand/leap_v2_full_assembly_left.stp
- v2-adv.leaphand.com/static/cad/leap_v2_adv_right.zip
- v2-adv.leaphand.com/static/cad/leap_v2_adv_left.zip
- v2-adv.leaphand.com/static/cad/pcbway_cad/pcbway_right.stp
- v2-adv.leaphand.com/static/cad/palm_parts/four_fingers_lower_palm_pla.stp
- v2-adv.leaphand.com/static/cad/palm_upper/four_fingers_upper_palm.3mf
- v2-adv.leaphand.com/static/cad/fingers/finger.stp
- v2-adv.leaphand.com/static/cad/fingers/finger.3mf
- v2-adv.leaphand.com/static/cad/fingers/thumb.3mf
- v2-adv.leaphand.com/static/cad/pla_parts/pulley.stp
- v2-adv.leaphand.com/static/cad/pla_parts/4fingers_bottom_right.stp
- v2-adv.leaphand.com/static/cad/pla_parts/4_fingers_mount.stp
- v2-adv.leaphand.com/static/cad/pla_parts/u2d2_holder.stp
- leap_v2/leap_v2/leap_v2_right/robot.urdf
- leap_v2/leap_v2/leapv2_node.py
- leap_v2/aligner/realign.py
- telekinesis/telekinesis/leap_v2_ik.py
Files stay in the upstream repository under their own licenses; these links open them there. The 3D model on this page is Motari's conversion of the file named under Simulation.
Simulation
Robot description files a simulator or CAD tool can load, linked at the commit they were found.
- URDFleap_v2/leap_v2/leap_v2_left/robot.urdfleap-hand/LEAP_Hand_V2_Adv_API
- URDFleap_v2/leap_v2/leap_v2_right/robot.urdfleap-hand/LEAP_Hand_V2_Adv_API
The 3D specimen on this page is converted from README.md at a093619.
Builds
No reviewed builds of LEAP Hand v2 Advanced yet.
A build log records the evidence (photos, a video, your repository), what the build cost, how long it took and what you changed. Each one is checked by Motari (until a maintainer claims this page) before it shows here, and reviewed builds count toward the reproducibility score.
Sources
Where the facts come from
- Softwaregithub.com/leap-hand/LEAP_Hand_V2_Adv_APIa093619
- Documentationgithub.com/leap-hand/LEAP_Hand_V2_Adv_API/blob/main/README.mda093619
- Simulationgithub.com/leap-hand/LEAP_Hand_V2_Adv_API/tree/main/leap_v2/...a093619
- Hardwarev2-adv.leaphand.com/leap_cad
- Bill of materialsv2-adv.leaphand.com/parts
- Build guidev2-adv.leaphand.com/assembly
- Documentationv2-adv.leaphand.com
Last push to leap-hand/LEAP_Hand_V2_Adv_API: 2025-06-13 (checked 2026-10-02)
Related links
- LEAP Power hubleap-hand/LEAP_Power (optional power distribution board)
- LEAP Hand v2v2.leaphand.com, the separate 8-motor design
How this page was made
Assembled from public sources on 2026-10-02, not yet reviewed by the maintainer. Each figure links to where it is stated; a value the sources do not state reads "not published". Last source review: 2026-10-02 leap-hand/LEAP_Hand_V2_Adv_API@a093619 README, LICENSE, tree; v2-adv.leaphand.com parts, CAD and assembly pages.
Original files stay intact and separately licensed; Motari adds only the summary on this page. Maintainer? Request a correction or removal.
Robots like LEAP Hand v2 Advanced
Lineage
- Supersedes
- LEAP Hand
Shares parts with
Robots whose bill of materials names the same parts, most shared first. Each part links to every robot that uses it.
- ToddlerBotDynamixelXM430XC33070
- ORCA HandDynamixelXC33073
- ROBOTIS OpenManipulator-XDynamixelXM43065
- Yale OpenHand ProjectDynamixelXM43065
- LEAP HandDynamixelXC33063
- TurtleBot3DynamixelXM43063
Parts in this robot's BOM: ROBOTIS Dynamixel servos (16 other robots), Dynamixel XM430 servo (4 other robots), Dynamixel XC330 servo (3 other robots)
Similar robots
The same type of robot, closest first by body plan, published cost and degrees of freedom. All grippers and robot hands
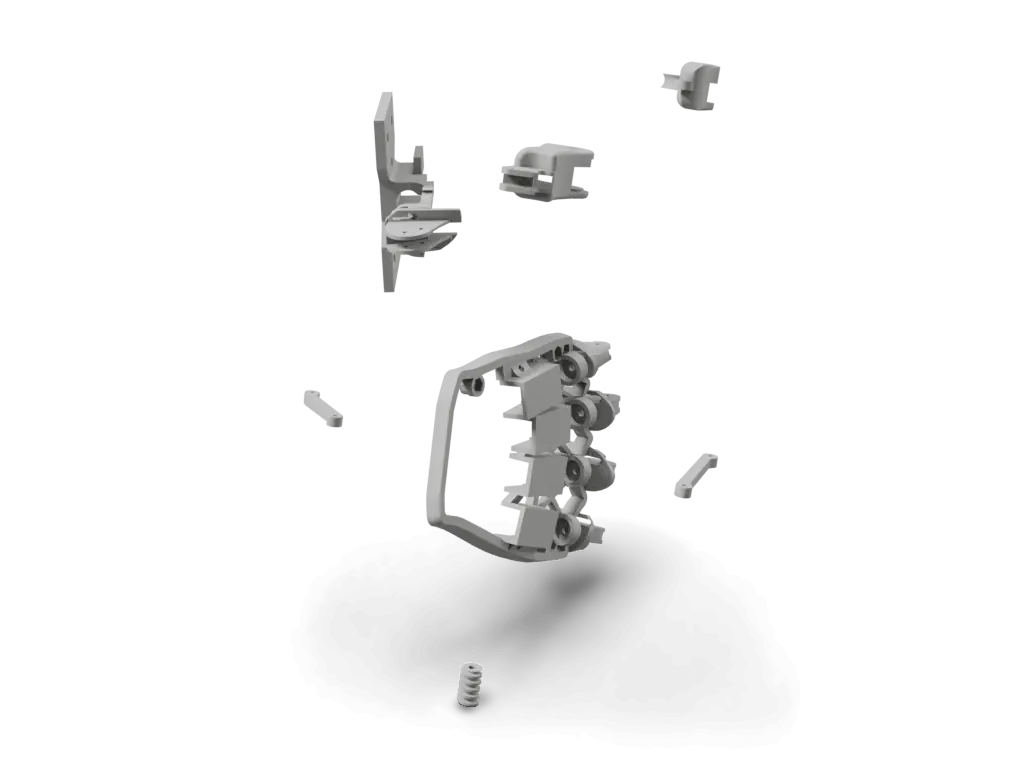
Badge for the README
Maintain LEAP Hand v2 Advanced? Show its reproducibility score in the project's README. The badge links back to this page and updates with the score.

[](https://motari.io/r/leap-hand-v2-advanced)<a href="https://motari.io/r/leap-hand-v2-advanced"><img src="https://motari.io/api/v1/badge/leap-hand-v2-advanced" alt="Motari reproducibility score for LEAP Hand v2 Advanced" height="20"></a>Not fully met yet: wiring diagram (partial), oshw-compatible license. The score is read from the project's own sources, so publishing what is missing is what raises it. A score of 90 or more needs a reviewed build. How the score is computed