
Yale OpenHand Project
Family of 3D-printed underactuated adaptive robot hands from Yale GRAB Lab.
- Cost unknownnot published by the source
- 4 DoF
- CC-BY-NC-3.0NChardware, non-commercial
- 65 / 100 reproducibilityPartial source coverage, unverified
What it is
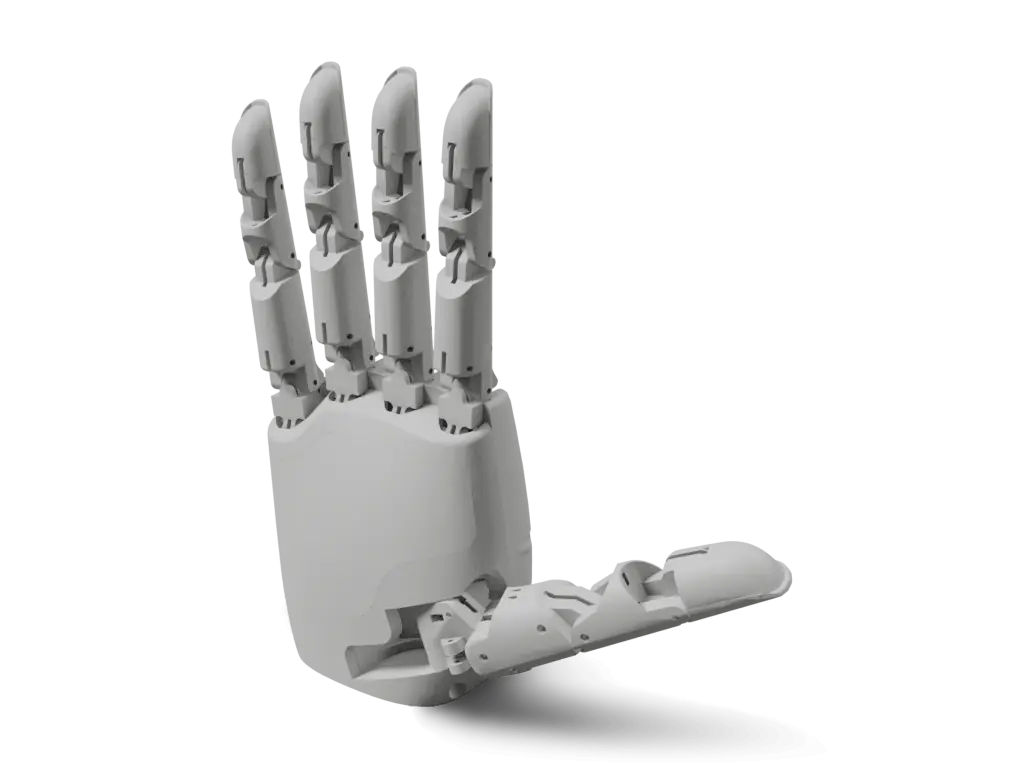
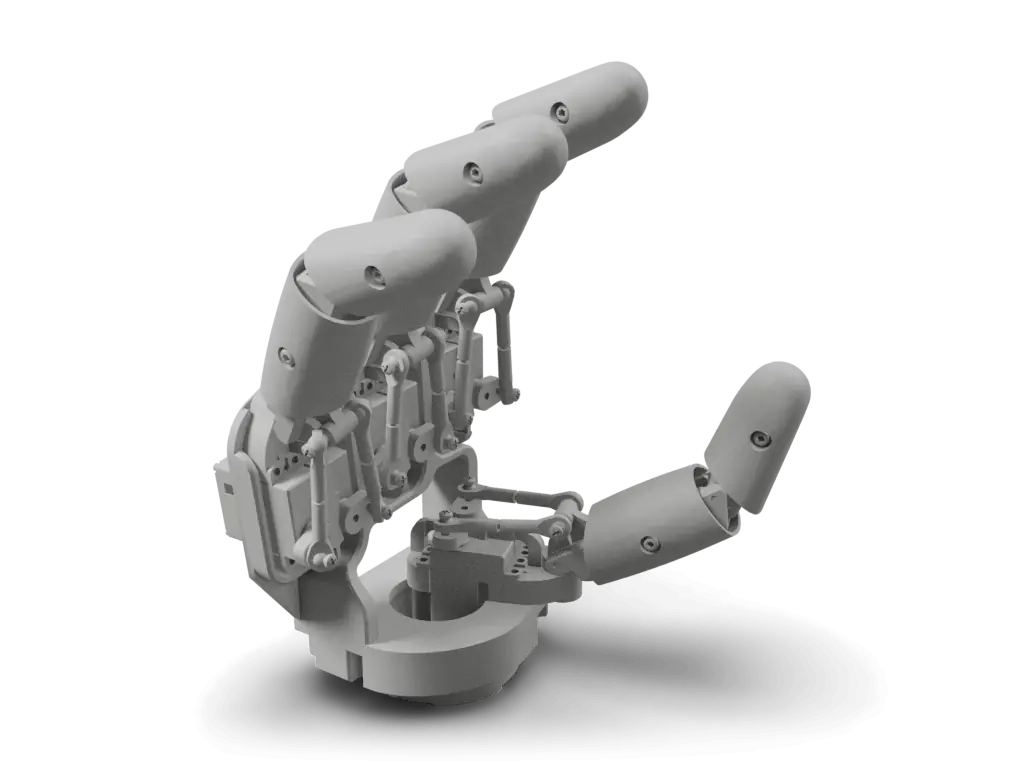
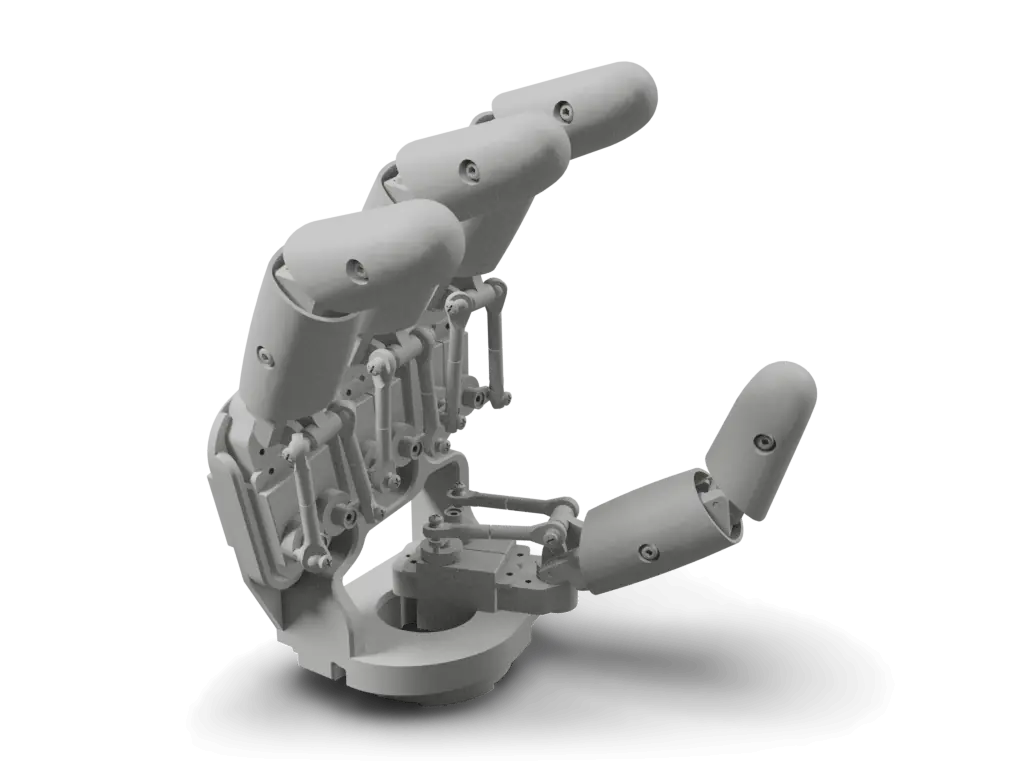
The Yale OpenHand Project is an open-source initiative from the Yale GRAB Lab (Raymond Ma, Lael Odhner, Aaron Dollar) to advance rapid-prototyped, underactuated robot hands. This repository holds the mechanical CAD (SolidWorks SLDPRT plus STL meshes) for a family of designs: the single-actuator four-finger Model T, the two-actuator Model T42, the modular Model M2, the variable-friction Model VF, the four-actuator anthropomorphic Model O, the finger-gaiting Model Q, the Stewart hand, and others. The hands use Dynamixel servos and tendon-driven flexure joints made with hybrid deposition manufacturing and Smooth-On urethane. The Model F3 assembly guide includes a BOM for that model, without prices, listing XM430 actuators, Spectra tendon, Smooth-On urethanes, McMaster fasteners/bearings/pins, a C920x webcam, and printed STL parts. Assembly instructions and ROS control code live on the project website; the CAD here is released under a non-commercial CC BY-NC 3.0 license.
Licenses
- Hardware
- CC-BY-NC-3.0NC
- Software
- Not published
- Docs
- CC-BY-NC-3.0NC
Degrees of freedom
4 DoF
No per-group breakdown has been sourced yet.
Underactuated handsource
Auto-assembled, not yet reviewed
Source record
- Sources
- 236 stars, last push 2025-03-25
- HW license
- CC-BY-NC-3.0NC
- Cost
- not published
- Lifecycle
- Maintained
- Engine
- v3.1.1
- Checked
- Model
- a1_part1.STL@b10197dsource parts laid out, not the assembled robotrendered 2026-06-08
Maintain Yale OpenHand Project? Claim this page to correct it.
Parts and cost
Cost to build
The sources do not publish a cost total. The rows below are what they list, without a sum.
Yale OpenHand Project parts, as the source lists them. Prices are the source's, not checked against vendors.
| Part | Qty | Spec | Source | Confidence |
|---|---|---|---|---|
Power Pro Spectra tendon lineModel F3 BOM lists one tendon item. | 1 | Tendon line; unit length/spool size not specified | Amazon link from the projectprice not listedModel F3 Assembly Guide 1.0.pdf, Bill of Materials / Printed Parts List | high |
PMC-780 urethaneModel F3 BOM lists one PMC-780 urethane item. | 1 | Finger joint urethane; amount not specified | Smooth-Onprice not listedModel F3 Assembly Guide 1.0.pdf, Bill of Materials / Printed Parts List | high |
Dragon Skin 10 siliconeModel F3 BOM lists one Dragon Skin 10 item. | 1 | Finger pad urethane/silicone; amount not specified | Smooth-Onprice not listedModel F3 Assembly Guide 1.0.pdf, Bill of Materials / Printed Parts List | high |
1/4 in diameter, 1-1/2 in long 8-32 female standoffModel F3 BOM lists four support standoffs. | 4 | Zinc-plated support standoff | McMaster 93330A482price not listedModel F3 Assembly Guide 1.0.pdf, Bill of Materials / Printed Parts List | high |
3 mm x 32 mm dowel pinModel F3 BOM lists eight joint pins. | 8 | Joint pin | McMaster 91595A138price not listedModel F3 Assembly Guide 1.0.pdf, Bill of Materials / Printed Parts List | high |
3 mm shaft shielded stainless steel ball bearingModel F3 BOM lists eight joint ball bearings. | 8 | Joint ball bearing for reducing tendon friction | McMaster 7804K126price not listedModel F3 Assembly Guide 1.0.pdf, Bill of Materials / Printed Parts List | high |
8-32 x 3/4 in countersunk boltModel F3 BOM lists eight support bolts. | 8 | Support bolt | McMaster 92210A197price not listedModel F3 Assembly Guide 1.0.pdf, Bill of Materials / Printed Parts List | high |
M2.5 x 8 mm boltModel F3 BOM lists two center bolts. | 2 | Center bolt for Dynamixel; guide notes included with Dynamixel | McMaster 91292A012 / included with Dynamixelprice not listedModel F3 Assembly Guide 1.0.pdf, Bill of Materials / Printed Parts List | high |
M2 x 5 mm boltModel F3 BOM lists four mounting bolts. | 4 | Dynamixel mounting bolt | McMaster 91290A012price not listedModel F3 Assembly Guide 1.0.pdf, Bill of Materials / Printed Parts List | high |
4-40 x 0.135 in heat-set insertModel F3 BOM lists four heat-set inserts. | 4 | Bolt-anchor insert | McMaster 93365A120price not listedModel F3 Assembly Guide 1.0.pdf, Bill of Materials / Printed Parts List | high |
4-40 x 1/4 in countersunk screwModel F3 BOM lists four tendon/spring anchor screws. | 4 | Tendon/spring anchor screw | McMaster 91253A106price not listedModel F3 Assembly Guide 1.0.pdf, Bill of Materials / Printed Parts List | high |
Dynamixel XM430 actuatorModel F3 BOM lists two Dynamixel XM430 actuators. | 2 | Servo actuator; exact XM430 variant not specified in the F3 table | Robotis / various vendorsprice not listedModel F3 Assembly Guide 1.0.pdf, Bill of Materials / Printed Parts List | high |
Logitech C920x HD Pro WebcamModel F3 BOM lists one Logitech C920x HD Pro Webcam. | 1 | RGB camera for Model F3 force-estimation setup | Amazon link from the projectprice not listedModel F3 Assembly Guide 1.0.pdf, Bill of Materials / Printed Parts List | high |
F3 finger thin-wall moldPrinted Parts List gives two F3 finger thin-wall mold parts. | 2 | Printable mold/finger item from F3_finger_mold.STL | make yourself from the project's STL meshprice not listedModel F3 Assembly Guide 1.0.pdf, Bill of Materials / Printed Parts List | high |
a1 part 1Printed Parts List gives one a1 part 1. | 1 | Finger base with camera mount, a1_part1.STL | make yourself from the project's STL meshprice not listedModel F3 Assembly Guide 1.0.pdf, Bill of Materials / Printed Parts List | high |
a1 part 2Printed Parts List gives one a1 part 2. | 1 | Extended camera mount, a1_part2.STL | make yourself from the project's STL meshprice not listedModel F3 Assembly Guide 1.0.pdf, Bill of Materials / Printed Parts List | high |
a2 motor fixture topPrinted Parts List gives one a2. | 1 | Motor fixture top, a2.STL | make yourself from the project's STL meshprice not listedModel F3 Assembly Guide 1.0.pdf, Bill of Materials / Printed Parts List | high |
a3 motor fixture bottomPrinted Parts List gives one a3. | 1 | Motor fixture bottom, a3.STL | make yourself from the project's STL meshprice not listedModel F3 Assembly Guide 1.0.pdf, Bill of Materials / Printed Parts List | high |
a4 robot-arm mountPrinted Parts List gives one a4. | 1 | Mount to robot arm, a4.STL | make yourself from the project's STL meshprice not listedModel F3 Assembly Guide 1.0.pdf, Bill of Materials / Printed Parts List | high |
b1 motor tendon-routing partPrinted Parts List gives two b1 parts. | 2 | Tendon routing for motors, b1_xm_f3.STL | make yourself from the project's STL meshprice not listedModel F3 Assembly Guide 1.0.pdf, Bill of Materials / Printed Parts List | high |
d1 casePrinted Parts List gives two d1 parts. | 2 | Case part, d1.STL | make yourself from the project's STL meshprice not listedModel F3 Assembly Guide 1.0.pdf, Bill of Materials / Printed Parts List | high |
Bearing sleevePrinted Parts List gives eight bearing sleeves. | 8 | Sleeve for ball bearings to prevent tendon slipping, bearing_sleeve.STL | make yourself from the project's STL meshprice not listedModel F3 Assembly Guide 1.0.pdf, Bill of Materials / Printed Parts List | high |
Rows from the source's own parts list 3
README.md@b10197dmarkdown
| Source row | Qty | Price and vendor | Line |
|---|---|---|---|
OpenHand hardware source structure and flexure-material context | Yale OpenHand hardware READMEno price listed | L6 |
model f3 (forces-for-free hand)/Model F3 Assembly Guide 1.0.pdf@b10197dpdf
| Source row | Qty | Price and vendor | Line |
|---|---|---|---|
Model F3 itemized unpriced bill of materials | Source PDF quantities: 1 tendon, 1 PMC-780, 1 Dragon Skin 10, 4 standoffs, 8 dowel pins, 8 bearings, 8 support bolts, 2 M2.5 bolts, 4 M2 bolts, 4 inserts, 4 4-40 screws, 2 XM430 actuators, 1 C920x webcam | Model F3 Assembly Guide 1.0.pdfno price listed | L20 |
Model F3 printed STL parts list | F3_finger_mold x2, a1_part1 x1, a1_part2 x1, a2 x1, a3 x1, a4 x1, b1_xm_f3 x2, d1 x2, bearing_sleeve x8 | Model F3 Assembly Guide 1.0.pdfno price listed | L149 |
How to build
Steps marked Motari summary condense the linked source; follow the source for exact instructions. Upstream step marks a step taken from the linked guide.
Pick a hand model
Choose a design from the repo (Model T, T42, M2, O, Q, VF, Stewart, etc.) based on the number of actuators and grasp behavior you need.
Upstream stepgithub.com/grablab/openhand-hardware/blob/b10197dcd79e7bcfa9...Print the structural parts
3D-print the finger, palm, and pulley parts from the provided STL meshes; SolidWorks SLDPRT sources are included for editing.
Motari summarygithub.com/grablab/openhand-hardware/blob/master/model%20f3%...Cast the flexure joints
Make the compliant flexure joints with Smooth-On urethane using the hybrid deposition manufacturing approach described on the project site.
Upstream stepgithub.com/grablab/openhand-hardware/blob/b10197dcd79e7bcfa9...Source hardware and assemble
Source the hardware listed in the chosen model's assembly guide (the Model F3 guide lists Dynamixel XM430 actuators, tendon line, Smooth-On urethanes, pins, bearings and fasteners), then assemble and route the tendons per that guide.
Motari summarygithub.com/grablab/openhand-hardware/blob/master/model%20f3%...Wire and control
Connect the Dynamixel servos (the Model F3 guide daisy-chains its two XM430s) and use the control code and ROS node in grablab/openhand_node, which covers Model T, T42 and O.
Motari summarygithub.com/grablab/openhand-hardware/blob/master/model%20f3%...
Wiring, power and firmware are safety-relevant and shown for reference only. Check them against the source before building.
metCAD / mesh present417 editable CAD files (SLDPRT/SLDASM/STEP) for 396 parts, including an assembly + 368 mesh files20/20
Quality tier 3 of 3
metBOM evidenceReviewedModel F3 only: its assembly guide has a BOM table of 12 line items with quantities and vendor links (McMaster, Smooth-On, Amazon, ROBOTIS); the engine does not parse PDF tables.20/20
Quality tier 3 of 5
missingWiring diagramno wiring diagram found0/15
Quality tier 0 of 3
The engine found nothing to point at for this item.
metFirmware linkedcontrol software linked (software source grablab/openhand_node)10/10
Quality tier 2 of 3
metBuild instructionsstep-by-step guide with images15/15
missingOSHW-compatible licenseCC-BY-NC-3.0 (non-commercial, not OSHW-compatible; from repository LICENSE file)0/10
Quality tier 0 of 2
- LICENSE.mdb10197d
missingKnown reproductionsno verified builds yet0/10
Quality tier 0 of 2
Only build reports a maintainer or admin has reviewed count here.
Engine v3.1.1 at b10197d, 1 item reviewed by hand
- The engine found no joint model or stated figure to count degrees of freedom from.
Files and sim
- stewart hand/Solidworks Files/Yale OpenHand Model C.SLDASM
- stewart hand/Solidworks Files/Finger/Actuator Swept Shape (for reference).sldprt
- stewart hand/Solidworks Files/Finger/Finger Assembly.SLDASM
- stewart hand/STLs and DXFs/p8.STL
- stewart hand/STLs and DXFs/p5.STL
- stewart hand/STLs and DXFs/p13.STL
- stewart hand/Stewart Hand v1.0.pdf
- model f3 (forces-for-free hand)/Model F3 Assembly Guide 1.0.pdf
- sphinx hand/code/aruco/aruco_object.pdf
Files stay in the upstream repository under their own licenses; these links open them there. The 3D model on this page is Motari's conversion of the file named under Simulation.
Simulation
Robot description files a simulator or CAD tool can load, linked at the commit they were found.
No URDF, MJCF, SDF, USD or Onshape model has been found in the sources.
The 3D specimen on this page is converted from model f3 (forces-for-free hand)/stl/a1_part1.STL at b10197d, with the parts laid out side by side because the source has no assembly.
Builds
No reviewed builds of Yale OpenHand Project yet.
A build log records the evidence (photos, a video, your repository), what the build cost, how long it took and what you changed. Each one is checked by Motari (until a maintainer claims this page) before it shows here, and reviewed builds count toward the reproducibility score.
Sources
Where the facts come from
- Hardwaregithub.com/grablab/openhand-hardwareb10197d
- Documentationeng.yale.edu/grablab/openhand
- Softwaregithub.com/grablab/openhand_nodea7feecf
- Build guidegithub.com/grablab/openhand-hardware/blob/master/model%20f3%...b10197d
Last push to grablab/openhand-hardware: 2025-03-25 (checked 2026-10-01)
Related links
- Yale GRAB Labgrablab.org
How this page was made
Assembled from public sources on 2026-06-04, not yet reviewed by the maintainer. Each figure links to where it is stated; a value the sources do not state reads "not published". Last source review: source-reviewed 2026-06-08.
Original files stay intact and separately licensed; Motari adds only the summary on this page. Maintainer? Request a correction or removal.
Robots like Yale OpenHand Project
Shares parts with
Robots whose bill of materials names the same parts, most shared first. Each part links to every robot that uses it.
- LEAP Hand v2 AdvancedDynamixelXM43073
- ToddlerBotDynamixelXM43070
- ROBOTIS OpenManipulator-XDynamixelXM43065
- TurtleBot3DynamixelXM43063
- Koch v1.1Dynamixel89
- Poppy HumanoidDynamixel80
Parts in this robot's BOM: ROBOTIS Dynamixel servos (16 other robots), Dynamixel XM430 servo (4 other robots)
Similar robots
The same type of robot, closest first by body plan, published cost and degrees of freedom. All grippers and robot hands
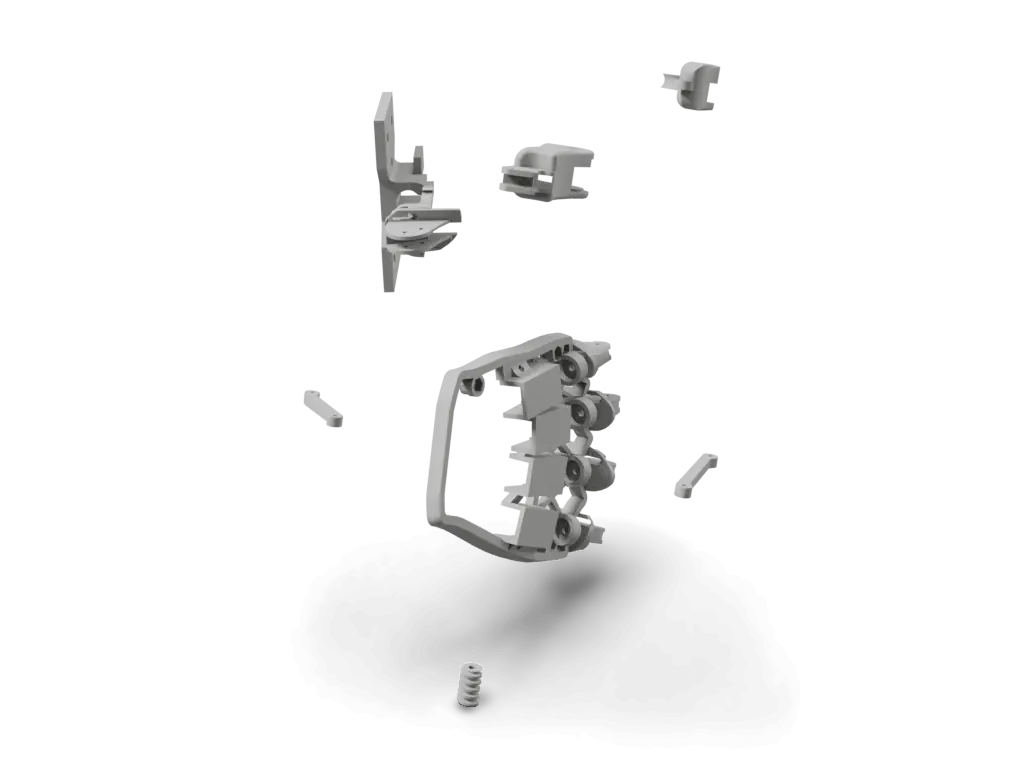
Badge for the README
Maintain Yale OpenHand Project? Show its reproducibility score in the project's README. The badge links back to this page and updates with the score.

[](https://motari.io/r/yale-openhand)<a href="https://motari.io/r/yale-openhand"><img src="https://motari.io/api/v1/badge/yale-openhand" alt="Motari reproducibility score for Yale OpenHand Project" height="20"></a>Not fully met yet: wiring diagram, oshw-compatible license. The score is read from the project's own sources, so publishing what is missing is what raises it. A score of 90 or more needs a reviewed build. How the score is computed