
DonkeyCar
Raspberry Pi self-driving RC car with a minimalist Python autopilot.
- $244.77sum of upstream Approximate Cost rows for the Raspberry Pi build, excluding 3D printed roll cage and top plate, estimate
- 2 DoF
- No hardware license statedhardware
- 63 / 100 reproducibilityPartial source coverage, unverified
What it is
DonkeyCar is an open-source software platform for building small-scale self-driving cars from off-the-shelf RC chassis; the software is MIT licensed and no hardware license is stated upstream. A Raspberry Pi (or Jetson Nano) drives an off-the-shelf RC chassis through a PCA9685 servo driver, with a camera for vision and a modular Python library for behavioral-cloning autopilots. It has an active community, hosted build and software docs, and supports cameras, lidar, GPS, and game controllers.
Licenses
- Hardware
- No hardware license statedMIT covers the donkeycar software only; no roll cage or top plate CAD is published
- Software
- MIT
- Docs
- Not published
Degrees of freedom
2 DoF drive 1steering 1
Ackermann steeringRC carsource
Auto-assembled, not yet reviewed
Source record
- Sources
- 3.5k stars, last push 2026-09-19
- HW license
- No hardware license stated
- Cost
- $244.77estimate, sum of upstream Approximate Cost rows for the Raspberry Pi build, excluding 3D printed roll cage and top plate
- Lifecycle
- Active
- Engine
- v3.1.1
- Checked
- Model
- build_hardware.md@e3c9327rendered 2026-06-07
Maintain DonkeyCar? Claim this page to correct it.
Parts and cost
Cost to build
- sum of upstream Approximate Cost rows for the Raspberry Pi build, excluding 3D printed roll cage and top plate
In the source currency, as read on 2026-09-30. Not converted, and not checked against current vendor prices: none of these is a Motari-verified checkout total.
DonkeyCar parts, as the source lists them. Prices are the source's, not checked against vendors.
| Part | Qty | Spec | Source | Confidence |
|---|---|---|---|---|
RC car chassisMagnet Car or compatible supported chassis | 1 | Magnet / HSP 94186 class RC chassis or alternative from supported cars | Magnet / supported RC chassis vendors$92DonkeyCar hardware guide parts table | high |
M2x6 screwseight screws for printed/chassis assembly | 8 | M2x6 | Amazon / generic$4.89DonkeyCar hardware guide parts table | high |
M3x10 screwsthree screws for printed/chassis assembly | 3 | M3x10 | Amazon / generic$7.89DonkeyCar hardware guide parts table | high |
Raspberry Pi 5 (8 GB)onboard compute | 1 | quad-core ARM | Raspberry Pi$60DonkeyCar hardware guide parts table | high |
PCA9685 servo driverPWM control board | 1 | 16-channel PWM, I2C | Adafruit / generic$12DonkeyCar hardware guide parts table | high |
Wide-angle cameraRaspberry Pi camera | 1 | CSI wide-angle | Raspberry Pi / generic$16DonkeyCar hardware guide parts table | high |
MicroSD cardOS + software | 1 | 64 GB | generic$18.99DonkeyCar hardware guide parts table | high |
USB power bankpowers the Pi | 1 | 10,000 mAh | generic$26DonkeyCar hardware guide parts table | high |
Female-to-female jumper wirewires between Raspberry Pi, PCA9685, servo, and ESC | 1 | female-to-female jumper wire set | Amazon / generic$7DonkeyCar hardware guide parts table | high |
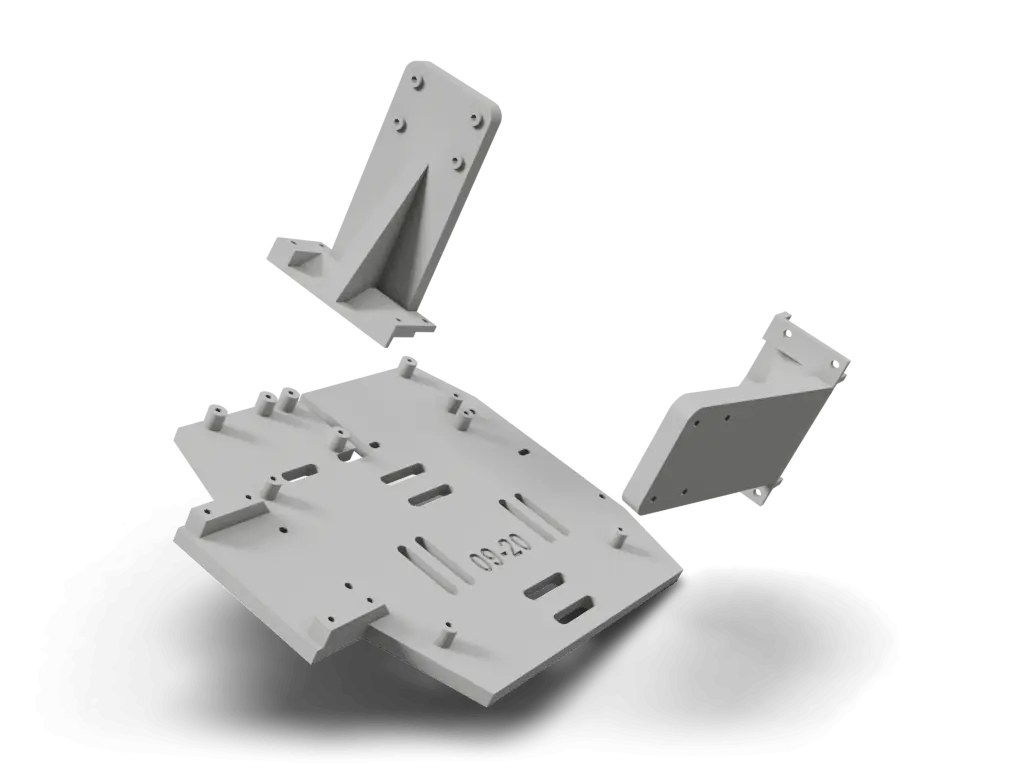
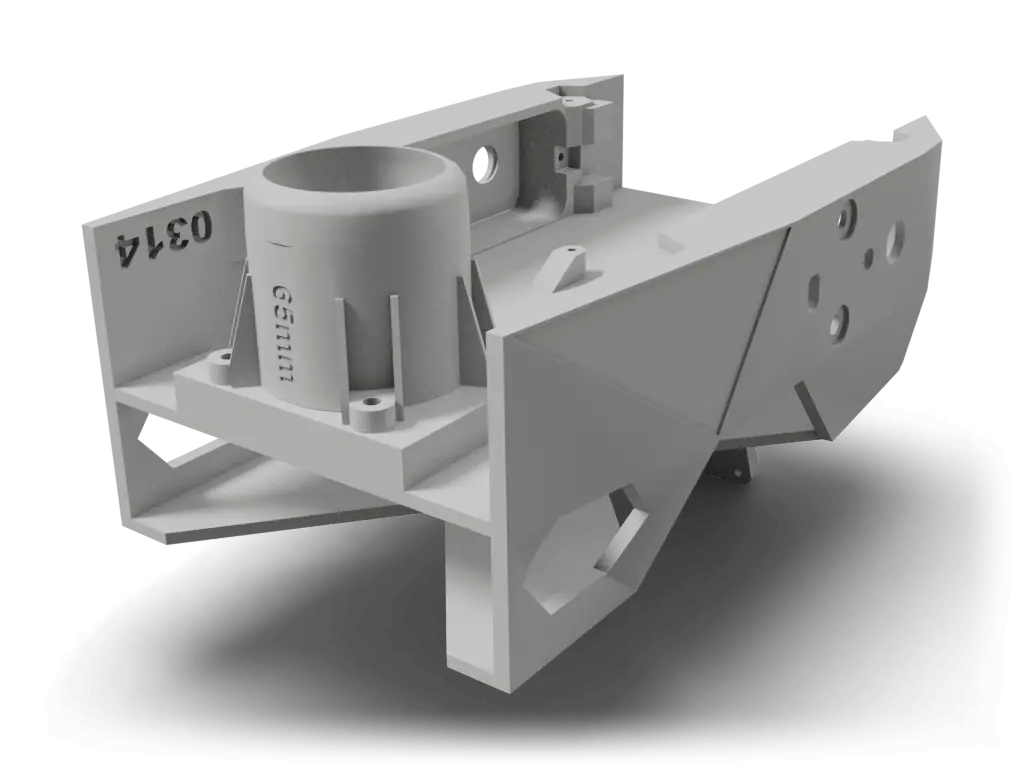
3D printed roll cage and top plateprint in PLA or use a third-party print service | 1 | DonkeyCar printed roll cage and top plate | 3D print yourself / third-party printprice not listedDonkeyCar hardware guide print-parts section | med |
Rows from the source's own parts list 3
docs/guide/build_hardware.md@e3c9327markdown
docs/cars/supported_cars.md@e3c9327markdown
| Source row | Qty | Price and vendor | Line |
|---|---|---|---|
supported RC chassis | 1 chassis | Magnet / HSP / Exceedno price listed | L3 |
How to build
Steps marked Motari summary condense the linked source; follow the source for exact instructions. Upstream step marks a step taken from the linked guide.
Assemble the RC chassis
Build the recommended 1/16-scale RC car chassis (e.g. WL Toys 144010) and 3D-print the compute/camera mount.
Motari summarydocs.donkeycar.com/guide/build_hardwareMount the Raspberry Pi and camera
Fix the Raspberry Pi and wide-angle camera to the printed deck on top of the chassis.
Motari summarydocs.donkeycar.com/guide/build_hardwareWire the PCA9685 driver
Connect the PCA9685 servo driver to the Pi over I2C and to the steering servo and ESC throttle.
Upstream stepdocs.donkeycar.com/guide/build_hardwareFlash and configure DonkeyCar
Flash Raspberry Pi OS to the microSD card, install the donkeycar package with the pi extras, create a car application with donkey createcar, and calibrate steering and throttle.
Motari summarydocs.donkeycar.com/guide/build_hardwareDrive, record, and train
Drive manually to record data, train a behavioral-cloning model, then run it as an autopilot.
Upstream stepdocs.donkeycar.com/guide/train_autopilot
Wiring, power and firmware are safety-relevant and shown for reference only. Check them against the source before building.
partialCAD / mesh presenthardware files on Thingiverse, not inspected by the engine10/20
Quality tier 1 of 3
metBOM evidencedocs/guide/build_hardware.md table (Parts Needed): 10 line items, priced (USD), vendor links20/20
Quality tier 3 of 5
partialWiring diagramwiring described in text only, no diagram7.5/15
Quality tier 1 of 3
metFirmware linkedfirmware source in the repo (Arduino)10/10
Quality tier 3 of 3
metBuild instructionsstep-by-step guide with images15/15
missingOSHW-compatible licenseno hardware license detected0/10
Quality tier 0 of 2
The engine found nothing to point at for this item.
missingKnown reproductionsno verified builds yet0/10
Quality tier 0 of 2
Only build reports a maintainer or admin has reviewed count here.
Engine v3.1.1 at ba25266
- The engine found no joint model or stated figure to count degrees of freedom from.
- The engine found no license file for the hardware in the hardware source.
Files and sim
- arduino/quadrature_encoder/quadrature_encoder.ino
- arduino/mono_encoder/mono_encoder.ino
- setup.cfg
- .github/workflows/python-package-conda.yml
- .github/workflows/superlinter.yml
- README.md
- donkeycar/utilities/TrackSpeedPlanner/README.md
- CONTRIBUTING.md
- docs/guide/build_hardware.md
- docs/cars/supported_cars.md
- docs/assets/build_hardware/DonkeycarWiring_bb.png
Files stay in the upstream repository under their own licenses; these links open them there. The 3D model on this page is Motari's conversion of the file named under Simulation.
Simulation
Robot description files a simulator or CAD tool can load, linked at the commit they were found.
No URDF, MJCF, SDF, USD or Onshape model has been found in the sources.
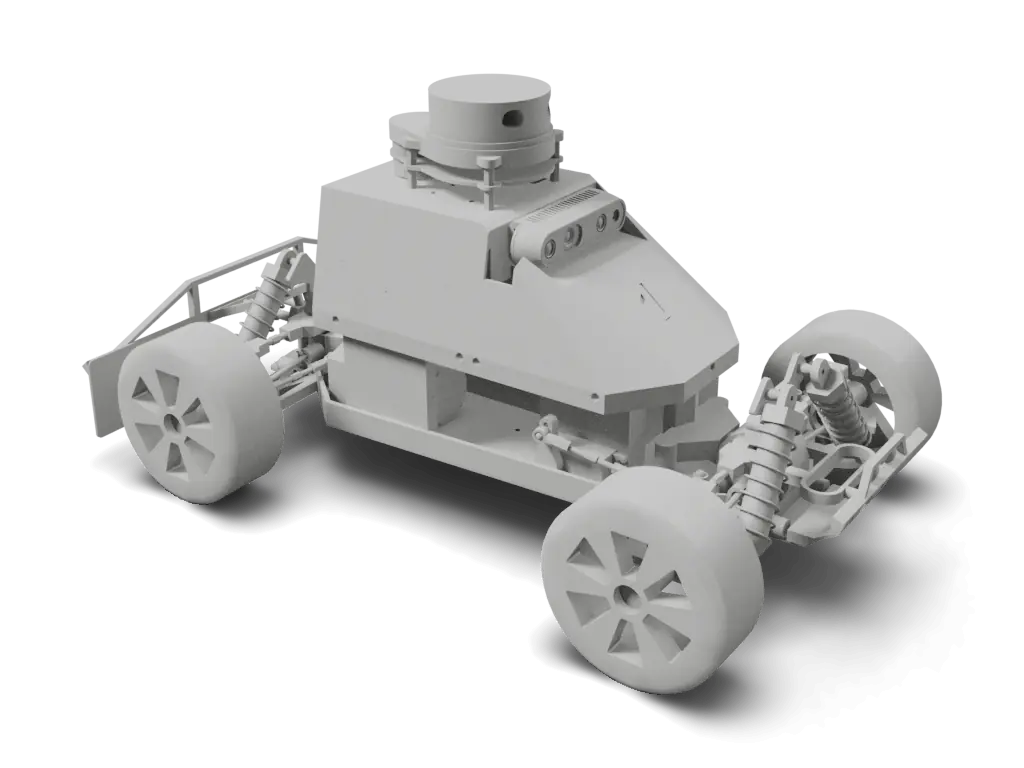
The 3D specimen on this page is converted from docs/guide/build_hardware.md at e3c9327.
Builds
No reviewed builds of DonkeyCar yet.
A build log records the evidence (photos, a video, your repository), what the build cost, how long it took and what you changed. Each one is checked by Motari (until a maintainer claims this page) before it shows here, and reviewed builds count toward the reproducibility score.
Sources
Where the facts come from
- Softwaregithub.com/autorope/donkeycarba25266
- Build guidedocs.donkeycar.com/guide/build_hardware
- Bill of materialsgithub.com/autorope/donkeydocs/blob/master/docs/guide/build_...e3c9327
- Storedonkeycar-701334.square.site
Last push to autorope/donkeycar: 2026-09-19 (checked 2026-10-01)
Related links
- Build + software docsdocs.donkeycar.com
- Community sitediyrobocars.com (donkeycar.com redirects here)
How this page was made
Assembled from public sources on 2026-06-04, not yet reviewed by the maintainer. Each figure links to where it is stated; a value the sources do not state reads "not published". Last source review: donkeydocs e3c9327, 2026-06-07.
Original files stay intact and separately licensed; Motari adds only the summary on this page. Maintainer? Request a correction or removal.
Robots like DonkeyCar
Shares parts with
Robots whose bill of materials names the same parts, most shared first. Each part links to every robot that uses it.
- JPL Open Source RoverRaspberry Pi89
- XLeRobotRaspberry Pi89
- AlohaMiniRaspberry Pi83
- UpkieRaspberry Pi83
- AndinoRaspberry Pi80
- Asimov 1Raspberry Pi80
Parts in this robot's BOM: Raspberry Pi (25 other robots)
Similar robots
The same type of robot, closest first by body plan, published cost and degrees of freedom. All mobile robots
Badge for the README
Maintain DonkeyCar? Show its reproducibility score in the project's README. The badge links back to this page and updates with the score.

[](https://motari.io/r/donkeycar)<a href="https://motari.io/r/donkeycar"><img src="https://motari.io/api/v1/badge/donkeycar" alt="Motari reproducibility score for DonkeyCar" height="20"></a>Not fully met yet: cad / mesh present (partial), wiring diagram (partial), oshw-compatible license. The score is read from the project's own sources, so publishing what is missing is what raises it. A score of 90 or more needs a reviewed build. How the score is computed