
Faze4 Robotic arm
3D-printed 6-axis stepper arm with printed cycloidal reducers and internal wiring.
- $1,000Whole arm, rough upstream figure with no priced BOM behind it. README: 'It is cheap <1000 dollars.' Docs: 'Total cost of the arm is around 1000 - 1500 dollars.' Hackaday: 'The total cost of the arm is around 1000 dollars', estimate
- 6 DoF
- CERN-OHL-S-2.0hardware
- 70 / 100 reproducibilityPartial source coverage, unverified
What it is
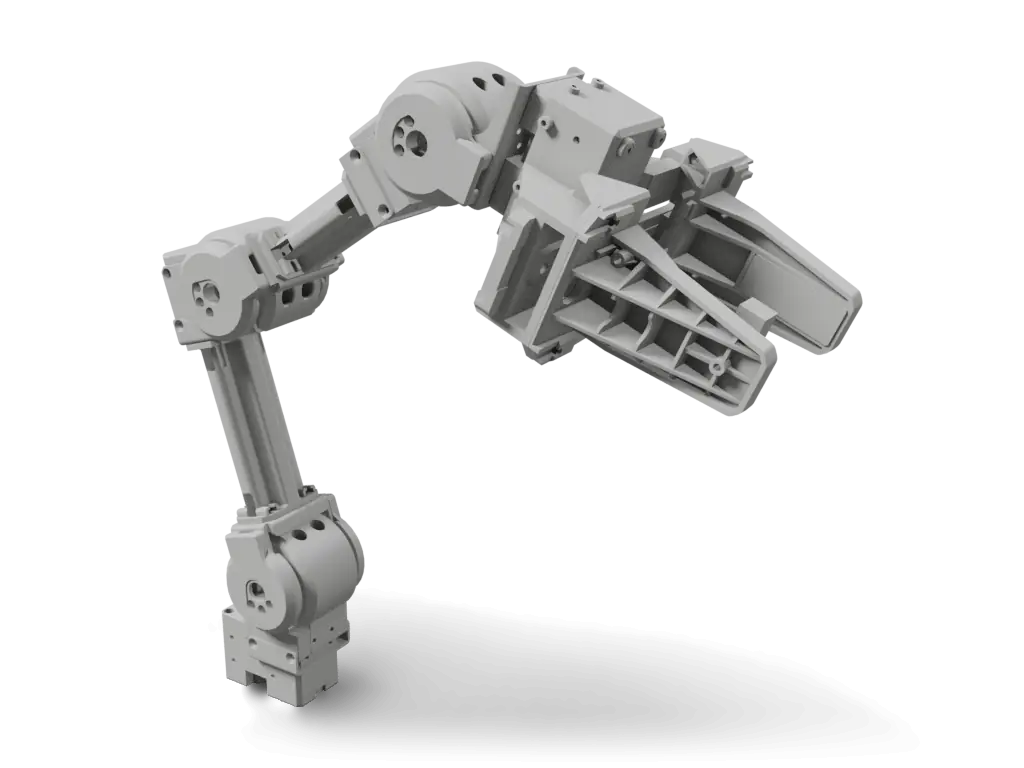
Faze4 is a 3D-printable 6-axis arm by Petar Crnjak, now published under Source Robotics, the maker of PAROL6. Six steppers (three NEMA 23, two NEMA 17 and a NEMA 14 with a 19:1 gearbox) drive printed cycloidal reducers on joints 1 to 5, with belts on joints 1, 4 and 5 and a planetary gearbox on joint 6, and all wiring runs inside an arm styled after the FANUC LR Mate 200iD. The repo holds zipped STLs, cycloidal-disc STEPs, a URDF with meshes, an xlsx BOM without prices, an 80-page assembly PDF, an electronics setup PDF, distribution PCB Gerbers and v2 board files, Teensy 3.5 Arduino code and Matlab kinematics; the full per-part STEP files are sold separately and are not open source. The LICENSE file was switched from MIT to CERN-OHL-S-2.0 in September 2025, while the README and the store page still describe the project as MIT. Upstream cost figures are rough (README under $1,000, docs around $1,000 to $1,500), hardware files were last changed between 2020 and 2023, and several docs pages are empty stubs.
Licenses
- Hardware
- CERN-OHL-S-2.0
- Software
- CERN-OHL-S-2.0
- Docs
- Not published
Degrees of freedom
6 DoF arm 6
Serial armSpherical wristCycloidal reducerssource
Auto-assembled, not yet reviewed
Source record
- Source
- 903 stars, last push 2025-12-28
- HW license
- CERN-OHL-S-2.0
- Cost
- $1,000estimate, Whole arm, rough upstream figure with no priced BOM behind it. README: 'It is cheap <1000 dollars.' Docs: 'Total cost of the arm is around 1000 - 1500 dollars.' Hackaday: 'The total cost of the arm is around 1000 dollars'
- Lifecycle
- Maintained
- Engine
- v3.1.1
- Checked
- Model
- Final_light_assembly_URDF.urdf@674f46crendered 2026-10-02
- Envelope
- 241 × 669 × 458 mmas modelled, default pose
Maintain Faze4 Robotic arm? Claim this page to correct it.
Parts and cost
Cost to build
- Whole arm, rough upstream figure with no priced BOM behind it. README: 'It is cheap <1000 dollars.' Docs: 'Total cost of the arm is around 1000 - 1500 dollars.' Hackaday: 'The total cost of the arm is around 1000 dollars'
In the source currency, as read on 2026-09-30. Not converted, and not checked against current vendor prices: none of these is a Motari-verified checkout total.
Faze4 Robotic arm parts, as the source lists them. Prices are the source's, not checked against vendors.
| Part | Qty | Spec | Source | Confidence |
|---|---|---|---|---|
Nema 23 Bipolar 1.5A 5.4V 57x57x56mmStepper used in the base assembly (assembly PDF, Base Assembly Step1) | 1 | NEMA 23, 1.5 A, 5.4 V, 57x57x56 mm | StepperOnline (link from the project)not listed in source BOMSource-Robotics/Faze4-Robotic-arm BOM_7_11_2023.xlsx Sheet1 row 58 | high |
Nema 23 Bipolar 4A 2.26V 57x57x84mmStepper used in the joint 2 cycloidal reducer (assembly PDF, Joint 2 cyclo Assembly Step1) | 1 | NEMA 23, 4 A, 2.26 V, 57x57x84 mm; the source link points to a dual-shaft model | StepperOnline (link from the project)not listed in source BOMSource-Robotics/Faze4-Robotic-arm BOM_7_11_2023.xlsx Sheet1 row 54 | high |
Nema 23 Bipolar 0.9deg 2.8A 2.5V 57x57x56mmStepper used in the elbow assembly (assembly PDF, Elbow Assembly Step4) | 1 | NEMA 23, 0.9 deg, 2.8 A, 2.5 V, 57x57x56 mm | StepperOnline (link from the project)not listed in source BOMSource-Robotics/Faze4-Robotic-arm BOM_7_11_2023.xlsx Sheet1 row 52 | high |
Nema 17 Bipolar 12V 42x42x40mmSteppers used in the elbow and forearm assemblies | 2 | NEMA 17, 42x42x40 mm | StepperOnline (link from the project)not listed in source BOMSource-Robotics/Faze4-Robotic-arm BOM_7_11_2023.xlsx Sheet1 row 46 | high |
Nema 14 L=33mm w/19:1 gearboxWrist stepper with planetary gearbox; the docs list joint 6 as a 19.19:1 planetary reducer | 1 | NEMA 14, 33 mm body, 19:1 planetary gearbox | StepperOnline (link from the project)not listed in source BOMSource-Robotics/Faze4-Robotic-arm BOM_7_11_2023.xlsx Sheet1 row 45 | high |
HTD 5M 490 mm timing belt 10 mm wideJoint 1 belt per the docs, tensioned with bearings | 1 | HTD 5M, 490 mm, 10 mm wide | not linked in source BOMnot listed in source BOMSource-Robotics/Faze4-Robotic-arm BOM_7_11_2023.xlsx Sheet1 row 59 | high |
HTD 5M 430 mm timing belt 10 mm wideJoint 4 belt per the docs | 1 | HTD 5M, 430 mm, 10 mm wide | not linked in source BOMnot listed in source BOMSource-Robotics/Faze4-Robotic-arm BOM_7_11_2023.xlsx Sheet1 row 51 | high |
J4 beltv = HTD belt 5M 285 10mm wideLabelled J4 in the BOM, while the docs assign the 285 mm belt to joint 5 | 1 | HTD 5M, 285 mm, 10 mm wide | not linked in source BOMnot listed in source BOMSource-Robotics/Faze4-Robotic-arm BOM_7_11_2023.xlsx Sheet1 row 53 | high |
Inductive sensorHoming sensors; Hackaday says joints 1 and 6 home on inductive sensors | 2 | inductive proximity sensor with M8 nuts | AliExpress (source affiliate link)not listed in source BOMSource-Robotics/Faze4-Robotic-arm BOM_7_11_2023.xlsx Sheet1 row 43 | high |
Micro limit switchHoming switches for the other joints | 3 | micro limit switch | not linked in source BOMnot listed in source BOMSource-Robotics/Faze4-Robotic-arm BOM_7_11_2023.xlsx Sheet1 row 50 | high |
Roller limit switchesHoming switches | 2 | roller-lever limit switch | not linked in source BOMnot listed in source BOMSource-Robotics/Faze4-Robotic-arm BOM_7_11_2023.xlsx Sheet1 row 57 | high |
Ball bearing 3x8x4Bearings section; the cycloidal reducers use many small bearings | 200 | 3x8x4 mm | AliExpress (source affiliate link)not listed in source BOMSource-Robotics/Faze4-Robotic-arm BOM_7_11_2023.xlsx Sheet1 row 29 | high |
Ball bearing 3x10x4Bearings section | 40 | 3x10x4 mm | AliExpress (source affiliate link)not listed in source BOMSource-Robotics/Faze4-Robotic-arm BOM_7_11_2023.xlsx Sheet1 row 32 | high |
Ball bearing 5x10x4Bearings section | 32 | 5x10x4 mm | AliExpress (source affiliate link)not listed in source BOMSource-Robotics/Faze4-Robotic-arm BOM_7_11_2023.xlsx Sheet1 row 34 | high |
Ball bearing 5x16x5Bearings section | 13 | 5x16x5 mm | AliExpress (source affiliate link)not listed in source BOMSource-Robotics/Faze4-Robotic-arm BOM_7_11_2023.xlsx Sheet1 row 35 | high |
Ball bearing 35x47x7Bearings section | 8 | 35x47x7 mm | AliExpress (source affiliate link)not listed in source BOMSource-Robotics/Faze4-Robotic-arm BOM_7_11_2023.xlsx Sheet1 row 28 | high |
Ball bearing 50x65x7Bearings section | 8 | 50x65x7 mm | AliExpress (source affiliate link)not listed in source BOMSource-Robotics/Faze4-Robotic-arm BOM_7_11_2023.xlsx Sheet1 row 33 | high |
Ball baering 15x28x7Bearings section (spelling as in source); no vendor link | 6 | 15x28x7 mm | not linked in source BOMnot listed in source BOMSource-Robotics/Faze4-Robotic-arm BOM_7_11_2023.xlsx Sheet1 row 31 | high |
Ball bearing 17x23x4Bearings section | 4 | 17x23x4 mm | AliExpress (source affiliate link)not listed in source BOMSource-Robotics/Faze4-Robotic-arm BOM_7_11_2023.xlsx Sheet1 row 30 | high |
Ball bearing 20x27x4Bearings section | 2 | 20x27x4 mm | AliExpress (source affiliate link)not listed in source BOMSource-Robotics/Faze4-Robotic-arm BOM_7_11_2023.xlsx Sheet1 row 36 | high |
3D printed partsPrinted-parts column of the BOM (cases, cycloidal discs, eccentric shafts, spacers, pulleys, covers); STLs in STL_V2.zip. Screws, nuts, inserts and pneumatic fittings are listed upstream | 197 | upstream printed-parts total; docs recommend PETG | 3D print yourselfnot listed in source BOMSource-Robotics/Faze4-Robotic-arm BOM_7_11_2023.xlsx Sheet1 rows 7 to 66 and total row 65 | high |
Rows from the source's own parts list 23
BOM_7_11_2023.xlsx@674f46cxlsx
| Source row | Qty | Price and vendor | Line |
|---|---|---|---|
Nema 23 Bipolar 1.5A 5.4V 57x57x56mm | 1 | vendor not listedno price listed | L58 |
Nema 23 Bipolar 4A 2.26V 57x57x84mm | 1 | vendor not listedno price listed | L54 |
Nema 23 Bipolar 0.9deg 2.8A 2.5V 57x57x56mm | 1 | vendor not listedno price listed | L52 |
Nema 17 Bipolar 12V 42x42x40mm | 2 | vendor not listedno price listed | L46 |
Nema 14 L=33mm w/19:1 gearbox | 1 | vendor not listedno price listed | L45 |
HTD 5M 490 mm timing belt 10 mm wide | 1 | vendor not listedno price listed | L59 |
HTD 5M 430 mm timing belt 10 mm wide | 1 | vendor not listedno price listed | L51 |
J4 beltv = HTD belt 5M 285 10mm wide | 1 | vendor not listedno price listed | L53 |
15 more rows in BOM_7_11_2023.xlsx
How to build
Steps marked Motari summary condense the linked source; follow the source for exact instructions. Upstream step marks a step taken from the linked guide.
Print the parts
The docs recommend PETG and a printer with a 250x210x200 build volume (parts were designed for a Prusa MK2S). Upstream printed small parts at 0.15 mm and large parts at 0.35 mm layers, 25 to 30% infill, 3 perimeters, 7 top and 5 bottom layers; print large parts slowly.
Upstream stepgithub.com/Source-Robotics/Faze4-Robotic-arm/blob/674f46cb60...Source the BOM
Order the parts in BOM_7_11_2023.xlsx (the arm has around 1000 parts including screws and bearings); upstream suggests buying spare bearings and screws. Before starting, extend every wire by about 1.5 m (less for wires near the base).
Motari summarygithub.com/Source-Robotics/Faze4-Robotic-arm/blob/674f46cb60...Build the arm segments
Follow the assembly PDF in order: wrist, forearm, elbow and lower arm. The wrist uses a Nema 14 motor with a 19:1 gearbox; the forearm and elbow are built around printed cycloidal reducers (11:1 discs for joints 5 and 4, 15:1 for joint 3); the lower arm adds the joint 4 pulleys and belt. Cycloidal discs should be tight, but not so tight that they cannot be rotated.
Upstream stepgithub.com/Source-Robotics/Faze4-Robotic-arm/blob/674f46cb60...Join the arm and base
Continue with the arm, the joint 2 cycloidal reducer, the rotating base and the base, routing all wires through the arm and the joint 1 output shaft. If the 490 mm base belt is not tight enough, add ball bearings where the guide shows, then fit the lids.
Upstream stepgithub.com/Source-Robotics/Faze4-Robotic-arm/blob/674f46cb60...Wire the electronics
Wire the stepper drivers per the electronics setup PDF, which lists microstep, current, voltage, limit-switch direction and enable level for each joint. The docs describe the distribution PCB and warn that PCB v1 has errors.
Motari summarygithub.com/Source-Robotics/Faze4-Robotic-arm/blob/674f46cb60...Load the control code
Low-level code runs on a Teensy 3.5 (Arduino sketches in the repo); high-level kinematics and trajectories are Matlab live scripts.
Motari summarygithub.com/Source-Robotics/Faze4-Robotic-arm/blob/674f46cb60...
Wiring, power and firmware are safety-relevant and shown for reference only. Check them against the source before building.
partialCAD / mesh presentonly 3 editable CAD parts against 74 printable parts, no assembly; not the design's CAD source10/20
partialBOM evidenceBOM_7_11_2023.xlsx (Sheet1): 60 line items10/20
Quality tier 1 of 5
metWiring diagram1 wiring/schematic diagram (image or PDF)15/15
Quality tier 2 of 3
metFirmware linkedfirmware source in the repo (Arduino)10/10
metBuild instructionsstep-by-step guide with images15/15
Quality tier 2 of 3
- Assembly instructions 3.1.pdf674f46c
- docs/C_Building.rst: Building674f46c
- docs/C_Building.rst674f46c
metOSHW-compatible licenseCERN-OHL-S-2.0 (from repository license)10/10
Quality tier 2 of 2
- LICENSE674f46c
missingKnown reproductionsno verified builds yet0/10
Quality tier 0 of 2
Only build reports a maintainer or admin has reviewed count here.
Engine v3.1.1 at 674f46c
How this score is computedFiles and sim
- URDF_FAZE4/urdf/Final_light_assembly_URDF.urdf
- URDF_FAZE4/meshes/base_link.STL
- URDF_FAZE4/meshes/nadlaktica.STL
- URDF_FAZE4/meshes/podlaktica.STL
- STL_V2.zip
- cyclo_disk_STEP_files.zip
- Distribution_PCB.zip
- Faze4_DIST_board_v2_files/Schematic.PDF
- FAZE4 Robotic arm electronics setup.pdf
- BOM_7_11_2023.xlsx
- Assembly instructions 3.1.pdf
- Faze4_test_code_1.0/Faze4_test_code_1.0.ino
- Software1/Low_Level_Arduino/Robot_Arduino_trajectory/Robot_Arduino_trajectory.ino
Files stay in the upstream repository under their own licenses; these links open them there. The 3D model on this page is Motari's conversion of the file named under Simulation.
Simulation
Robot description files a simulator or CAD tool can load, linked at the commit they were found.
- URDFURDF_FAZE4/urdf/Final_light_assembly_URDF.urdfSource-Robotics/Faze4-Robotic-arm
The 3D specimen on this page is converted from URDF_FAZE4/urdf/Final_light_assembly_URDF.urdf at 674f46c.
Builds
No reviewed builds of Faze4 Robotic arm yet.
A build log records the evidence (photos, a video, your repository), what the build cost, how long it took and what you changed. Each one is checked by Motari (until a maintainer claims this page) before it shows here, and reviewed builds count toward the reproducibility score.
Sources
Where the facts come from
- Hardwaregithub.com/Source-Robotics/Faze4-Robotic-arm674f46c
- Bill of materialsgithub.com/Source-Robotics/Faze4-Robotic-arm/blob/master/BOM...674f46c
- Build guidegithub.com/Source-Robotics/Faze4-Robotic-arm/blob/master/Ass...674f46c
- Documentationfaze4-robotic-arm-docs.readthedocs.io/en/latest
- Documentationhackaday.io/project/167247-faze4-robotic-arm
- Simulationgithub.com/Source-Robotics/Faze4-Robotic-arm/tree/master/URD...674f46c
- Storesource-robotics.com/products/faze4-step-files
Last push to Source-Robotics/Faze4-Robotic-arm: 2025-12-28 (checked 2026-10-02)
Related links
- Sibling projectPAROL6 by the same maker
How this page was made
Assembled from public sources on 2026-09-30, not yet reviewed by the maintainer. Each figure links to where it is stated; a value the sources do not state reads "not published". Last source review: 2026-09-30 Source-Robotics/Faze4-Robotic-arm@674f46c README, LICENSE, tree.
Original files stay intact and separately licensed; Motari adds only the summary on this page. Maintainer? Request a correction or removal.
Robots like Faze4 Robotic arm
Shares parts with
Robots whose bill of materials names the same parts, most shared first. Each part links to every robot that uses it.
- SmallRobotArm (Skyentific)NEMA 1780
- PAROL6 Desktop Robot ArmNEMA 1773
- BCN3D MoveoNEMA 1765
- AR4 (Annin Robotics)NEMA 1760
Parts in this robot's BOM: NEMA 17 stepper motor (4 other robots)
Similar robots
The same type of robot, closest first by body plan, published cost and degrees of freedom. All robot arms
Badge for the README
Maintain Faze4 Robotic arm? Show its reproducibility score in the project's README. The badge links back to this page and updates with the score.

[](https://motari.io/r/faze4)<a href="https://motari.io/r/faze4"><img src="https://motari.io/api/v1/badge/faze4" alt="Motari reproducibility score for Faze4 Robotic arm" height="20"></a>Not fully met yet: cad / mesh present (partial), bom evidence (partial). The score is read from the project's own sources, so publishing what is missing is what raises it. A score of 90 or more needs a reviewed build. How the score is computed