
Bob The Hexapod
Cheap 3D-printed 18-servo hexapod on a Raspberry Pi Pico with a custom PCB.
- Cost unknownnot published by the source
- 18 DoF
- MIThardware
- 73 / 100 reproducibilityPartial source coverage, unverified
What it is
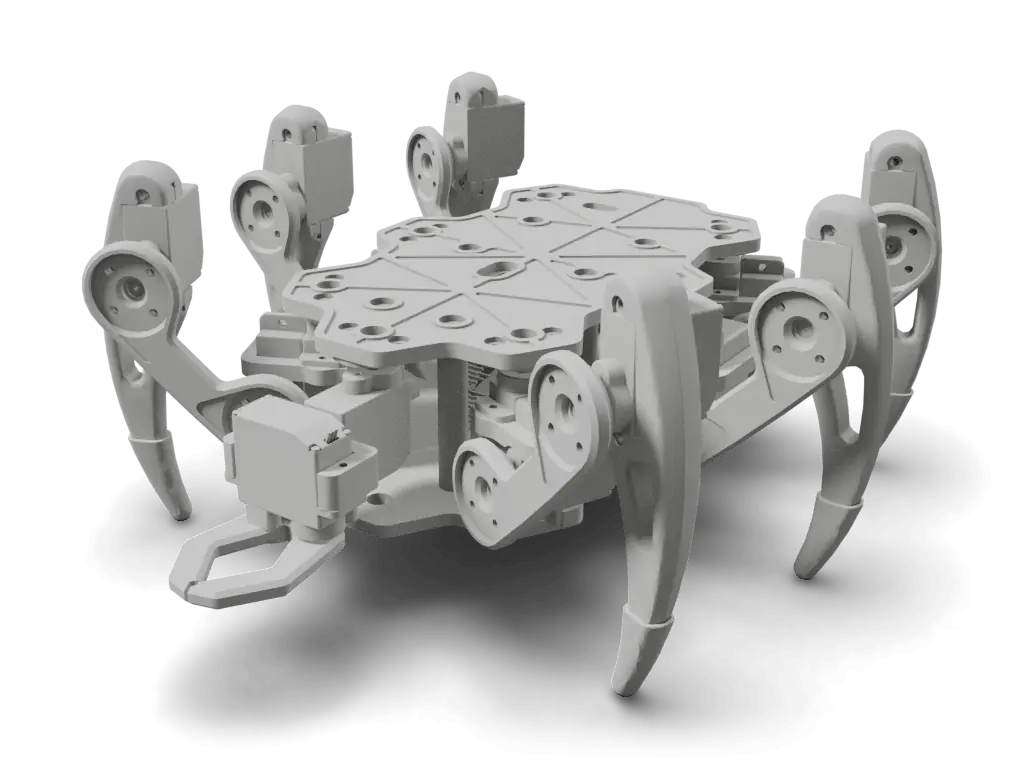
Bob The Hexapod is an open-source hexapod platform built from cheap, widely available parts. Leg motion is handled by 18 SG90 servos driven by a Raspberry Pi Pico, with most components centralized on a custom PCB and powered by a DIY 2S li-ion pack. The repo ships STEP CAD, PCB Gerbers and BOM, and PlatformIO firmware with inverse kinematics, controlled over Bluetooth from an Android phone.
Licenses
- Hardware
- MIT
- Software
- Not published
- Docs
- Not published
Degrees of freedom
18 DoF legs 18
Hexapodsource
Auto-assembled, not yet reviewed
Source record
Maintain Bob The Hexapod? Claim this page to correct it.
Parts and cost
Cost to build
The sources do not publish a cost total. The rows below are what they list, without a sum.
Bob The Hexapod parts, as the source lists them (read 2026-06-07). Prices are the source's, not checked against vendors.
| Part | Qty | Spec | Source | Confidence |
|---|---|---|---|---|
SG90 servo motorsLeg actuators, 3 per leg | 18 | 9 g SG90 micro servos | genericprice not listedPapouc/Bob-The-Hexapod readme.md lines 24-28 | high |
Raspberry Pi PicoRP2040 control board running locomotion and inverse kinematics | 1 | Raspberry Pi Pico / RP2040 | Raspberry Piprice not listedreadme.md line 25 and docs/Parts/BOM.csv line 2 | high |
HC-05 Bluetooth moduleAndroid Bluetooth serial control link | 1 | HC-05 module | genericprice not listedreadme.md line 26 and docs/Parts/BOM.csv line 32 | high |
XL4015 buck converter ICPower-supply regulator stage | 1 | XL4015E1 step-down converter | electronics from the project's BOMprice not listedreadme.md line 28 and docs/Parts/BOM.csv line 31 | high |
Custom 2-layer control PCB and BOM componentsGerbers, schematic and PCB BOM are published in docs | 1 | 2-layer, 1.6 mm PCB with passives, diodes, servo headers and connector | self-order / electronics from the project's BOMprice not listedreadme.md lines 34-36 and docs/Parts/BOM.csv lines 2-33 | high |
2S li-ion battery packDIY pack with protection and XT30 outputs | 1 | 2 Sony US18650VTC5 cells in series, 2S BMS, pair of XT30 connectors | genericprice not listedPapouc/Bob-The-Hexapod readme.md line 16 | high |
3D-printed structurePrintable mechanical body and leg parts | 1 | 58 FDM printed parts; PLA+ used by upstream author; non-flexible filament acceptable | 3D print yourselfprice not listedPapouc/Bob-The-Hexapod readme.md lines 11-13 and docs/3D/Assembly.step | high |
Rows from the source's own parts list 36
docs/Parts/BOM.csv@9145ea2csv
| Source row | Qty | Price and vendor | Line |
|---|---|---|---|
1 RASPBERRY-PI-PICO 1 RASPBERRYPIPICO 1 | 1 RASPBERRY-PI-PICO 1 RASPBERRYPIPICO 1 | vendor not listedno price listed | L2 |
2 220uF C1 CAP-TH_BD10.0-P5.00-D1.0-FD 1 | 2 220uF C1 CAP-TH_BD10.0-P5.00-D1.0-FD 1 | vendor not listedno price listed | L3 |
3 330uF C2 CAP-TH_BD8.0-P3.50-D0.6-FD 1 | 3 330uF C2 CAP-TH_BD8.0-P3.50-D0.6-FD 1 | vendor not listedno price listed | L4 |
4 1uF C3,C4,C5 CAP-TH_L5.5-W3.5-P5.00-D1.2 3 | 4 1uF C3,C4,C5 CAP-TH_L5.5-W3.5-P5.00-D1.2 3 | vendor not listedno price listed | L5 |
5 SB540_C268686 D1 DO-201AD_BD5.3-L8.4-P12.50-D1.4-RD 1 | 5 SB540_C268686 D1 DO-201AD_BD5.3-L8.4-P12.50-D1.4-RD 1 | vendor not listedno price listed | L6 |
6 1N5819_C84620 D2 DO-41_BD2.4-L4.7-P8.70-D0.9-RD 1 | 6 1N5819_C84620 D2 DO-41_BD2.4-L4.7-P8.70-D0.9-RD 1 | vendor not listedno price listed | L7 |
7 SERVO_0 J1 HDR-M-2.54_1X3 1 | 7 SERVO_0 J1 HDR-M-2.54_1X3 1 | vendor not listedno price listed | L8 |
8 SERVO_1 J2 HDR-M-2.54_1X3 1 | 8 SERVO_1 J2 HDR-M-2.54_1X3 1 | vendor not listedno price listed | L9 |
24 more rows in docs/Parts/BOM.csv
readme.md@9145ea2markdown
| Source row | Qty | Price and vendor | Line |
|---|---|---|---|
Bob robot-level hardware and printed parts | 18 servos; 58 printed parts | vendor not listedno price listed | L7 |
Bob battery pack and XL4015 power supply | 2 cells plus 2S BMS; one XL4015 power stage | vendor not listedno price listed | L16 |
Bob basic electronics parts list | Pico x1; HC-05 x1; SG90 x18; XL4015 x1; US18650VTC5 x2 | vendor not listedno price listed | L20 |
Bob custom control PCB fabrication note | one 2-layer 1.6mm PCB | vendor not listedno price listed | L34 |
How to build
Steps marked Motari summary condense the linked source; follow the source for exact instructions. Upstream step marks a step taken from the linked guide.
Print the parts
Print the 58 printed parts in a non-flexible filament such as PLA+ on an FDM printer. docs/3D holds a single Assembly.step with all parts, so export each part from it.
Motari summarygithub.com/Papouc/Bob-The-HexapodOrder and populate the PCB
Fabricate the 2-layer control board from the Gerbers in docs/Gerber and solder the parts listed in docs/Parts/BOM.csv (XL4015, HC-05, headers).
Motari summarygithub.com/Papouc/Bob-The-HexapodBuild the battery pack
Assemble a 2S li-ion pack from two 18650 cells with a 2S BMS and XT30 connectors as described in the README.
Upstream stepgithub.com/Papouc/Bob-The-Hexapod/blob/9145ea287a3538356e419...Mount the 18 servos
Install three SG90 servos per leg and wire each to the servo headers on the control board.
Motari summarygithub.com/Papouc/Bob-The-HexapodFlash and control
Build the PlatformIO project (Arduino-Pico core) and upload to the Pico, then drive the robot over Bluetooth from an Android phone.
Upstream stepgithub.com/Papouc/Bob-The-Hexapod/blob/9145ea287a3538356e419...
Wiring, power and firmware are safety-relevant and shown for reference only. Check them against the source before building.
metCAD / mesh present1 editable CAD files (STEP), including an assembly20/20
Quality tier 3 of 3
- docs/3D/Assembly.step9145ea2
partialBOM evidencedocs/Parts/BOM.csv present, contents not parseable10/20
Quality tier 1 of 5
- docs/Parts/BOM.csv9145ea2
metWiring diagram1 wiring/schematic diagram (image or PDF)15/15
Quality tier 2 of 3
- docs/Gerber/Schematic.pdf9145ea2
metFirmware linkedfirmware source in the repo (PlatformIO)10/10
Quality tier 3 of 3
- platformio.ini9145ea2
partialBuild instructionsReviewedREADME Hardware section gives fabrication notes (58 PLA+ printed parts, 2-layer 1.6 mm PCB, 2S battery pack with BMS and XT30) but no assembly steps.7.5/15
Quality tier 1 of 3
Reviewed override, 2026-09-30
Evidence on github.comEngine alone: missing at tier 0 (no build instructions found)
metOSHW-compatible licenseMIT (from repository license)10/10
Quality tier 2 of 2
- LICENSE.txt9145ea2
missingKnown reproductionsno verified builds yet0/10
Quality tier 0 of 2
Only build reports a maintainer or admin has reviewed count here.
Engine v3.1.1 at 9145ea2, 1 item reviewed by hand
- The engine found no joint model or stated figure to count degrees of freedom from.
Files and sim
Files stay in the upstream repository under their own licenses; these links open them there. The 3D model on this page is Motari's conversion of the file named under Simulation.
Simulation
Robot description files a simulator or CAD tool can load, linked at the commit they were found.
No URDF, MJCF, SDF, USD or Onshape model has been found in the sources.
The 3D specimen on this page is converted from docs/3D/Assembly.step at 9145ea2.
Builds
No reviewed builds of Bob The Hexapod yet.
A build log records the evidence (photos, a video, your repository), what the build cost, how long it took and what you changed. Each one is checked by Motari (until a maintainer claims this page) before it shows here, and reviewed builds count toward the reproducibility score.
Sources
Where the facts come from
- Hardwaregithub.com/Papouc/Bob-The-Hexapod9145ea2
- Bill of materialsgithub.com/Papouc/Bob-The-Hexapod/blob/main/docs/Parts/BOM.csv9145ea2
Last push to Papouc/Bob-The-Hexapod: 2023-09-19 (checked 2026-10-01)
Related links
- PCB Gerbersdocs/Gerber
- CAD + BOMdocs/3D and docs/Parts
How this page was made
Assembled from public sources on 2026-06-04, not yet reviewed by the maintainer. Each figure links to where it is stated; a value the sources do not state reads "not published". Last source review: 2026-06-07 Papouc/Bob-The-Hexapod source BOM.
Original files stay intact and separately licensed; Motari adds only the summary on this page. Maintainer? Request a correction or removal.
Robots like Bob The Hexapod
None of the parts in this bill of materials is tracked across robots yet. See the parts robots have in common.
Similar robots
The same type of robot, closest first by body plan, published cost and degrees of freedom. All legged robots
Badge for the README
Maintain Bob The Hexapod? Show its reproducibility score in the project's README. The badge links back to this page and updates with the score.

[](https://motari.io/r/bob-the-hexapod)<a href="https://motari.io/r/bob-the-hexapod"><img src="https://motari.io/api/v1/badge/bob-the-hexapod" alt="Motari reproducibility score for Bob The Hexapod" height="20"></a>Not fully met yet: bom evidence (partial), build instructions (partial). The score is read from the project's own sources, so publishing what is missing is what raises it. A score of 90 or more needs a reviewed build. How the score is computed