
Amazing Hand Enhanced
The Amazing Hand rebuilt around Feetech STS3032 servos: an 8-DoF, four-finger, 3D-printed hand with all motors inside.
- €287 in partsone hand with the Waveshare serial bus driver board, incl. 15 EUR of printed parts; the sheet lists an external 6V supply without a price, source total
- 8 DoF
- CC-BY-4.0hardware
- 78 / 100 reproducibilityPartial source coverage, unverified
What it is
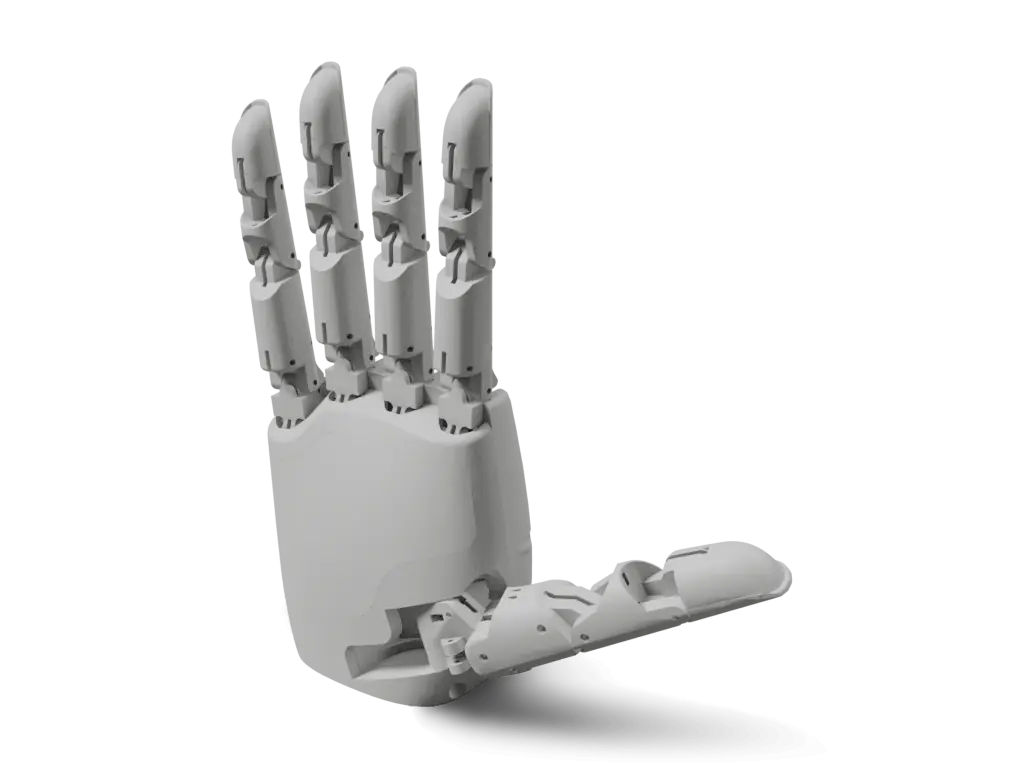
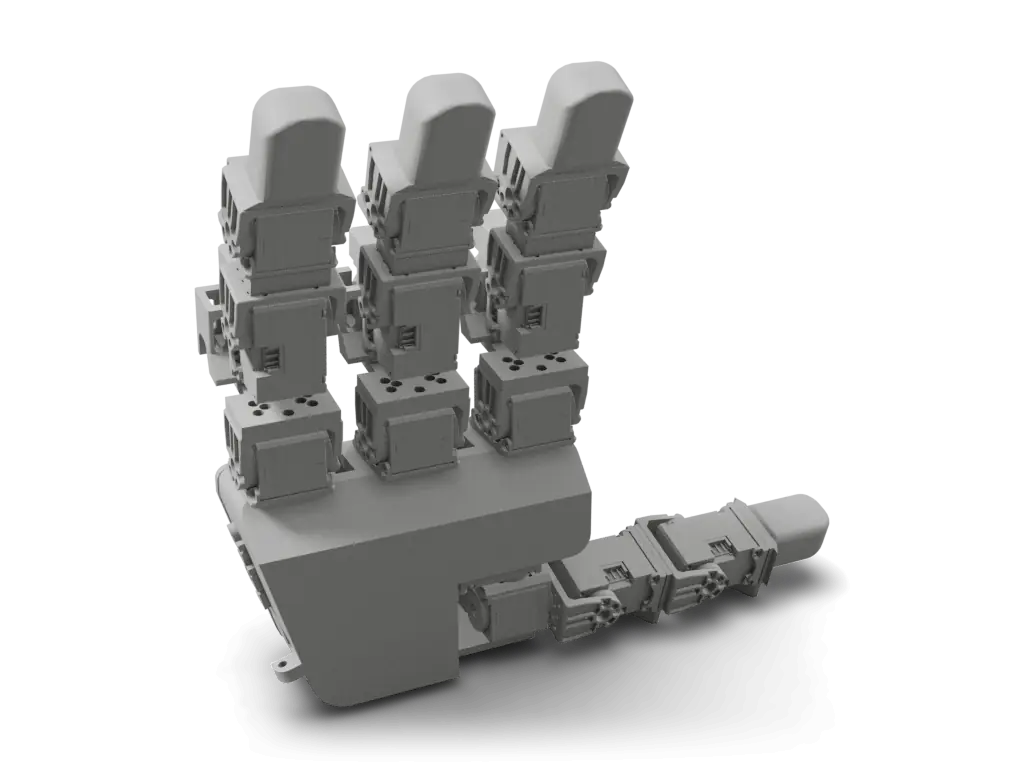
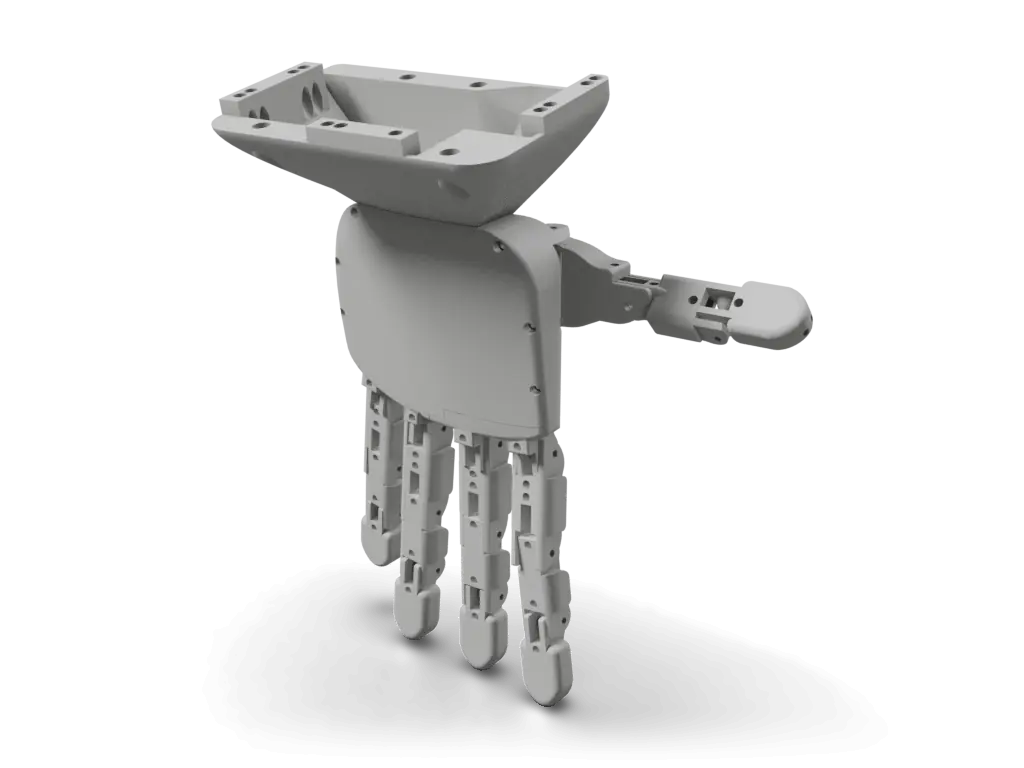
Amazing Hand Enhanced is Pollen Robotics' update of the Amazing Hand, published on the repository's Amazing-Hand-Enhanced branch. It swaps the eight Feetech SCS0009 servos for Feetech STS3032 servos, which the README says give full backdrivability, better accuracy and more torque and speed in the same overall volume. The finger parts (proximal, distal, gimbal, link and finger shells) are shared with the original; the finger frame becomes one part, a custom servo horn is printed, and the hand plate, wrist interface and shells change to fit the thicker servos. The branch publishes STEP and STL files for the changed parts, a 33-page assembly PDF and Python calibration and demo scripts, and links a public Onshape document and a Google Sheets BOM that totals 287.00 EUR per hand with a Waveshare serial bus driver (the root README puts the Enhanced hand under 350 EUR). The mechanical design is CC BY 4.0 and the code Apache-2.0. The 3D view is the right-hand MuJoCo model from the AH-Enhanced-Demo branch, a simulation model generated from the Onshape assembly; the README lists the advanced demo as still to be released.
Licenses
- Hardware
- CC-BY-4.0
- Software
- Apache-2.0
- Docs
- Not published
Degrees of freedom
8 DoF ring 2index 2thumb 2middle 2
Dexterous handFour fingerParallel mechanism fingerssource
Auto-assembled, not yet reviewed
Source record
- Source
- 2.4k stars, last push 2026-04-23
- HW license
- CC-BY-4.0
- Cost
- €287source total, one hand with the Waveshare serial bus driver board, incl. 15 EUR of printed parts; the sheet lists an external 6V supply without a price
- Lifecycle
- Active
- Engine
- v3.1.1
- Checked
- Model
- robot.xml@eb78a9dthe project's simulation model in pollen-robotics/AmazingHand, not its build CADrendered 2026-10-02
- Envelope
- 129 × 178 × 121 mmas in the simulation model, default pose
Maintain Amazing Hand Enhanced? Claim this page to correct it.
Parts and cost
Cost to build
- one hand with the Waveshare serial bus driver board, incl. 15 EUR of printed parts; the sheet lists an external 6V supply without a price
In the source currency, as read on 2026-10-02. Not converted, and not checked against current vendor prices: none of these is a Motari-verified checkout total.
Amazing Hand Enhanced parts, as the source lists them. Prices are the source's, not checked against vendors.
| Part | Qty | Spec | Source | Confidence |
|---|---|---|---|---|
Feetech STS3032 ServosEight servos, two per finger; the README swaps them in for the original's SCS0009 | 8 | Feetech STS3032 serial bus servo; 215.92 EUR line total in the source sheet | AliExpress26.99 EUR eachpollen-robotics/AmazingHand Amazing-Hand-Enhanced README BOM link: Google Sheet, BOM tab | high |
Ball joint M2 x L19Four per finger; the assembly guide cuts their M2x12 screws to 10 mm | 16 | M2 ball joint, 19 mm; 17.60 EUR line total in the source sheet | Amazon.fr1.10 EUR eachpollen-robotics/AmazingHand Amazing-Hand-Enhanced README BOM link: Google Sheet, BOM tab | high |
M2 threaded rod L300mmCut into the finger rods during preparation | 1 | M2 threaded rod, 300 mm | AliExpress1.71 EURpollen-robotics/AmazingHand Amazing-Hand-Enhanced README BOM link: Google Sheet, BOM tab | high |
Axis D2x10Finger pivot pins | 8 | 2 mm pin, 10 mm long; 4.00 EUR line total in the source sheet | AliExpress0.50 EUR eachpollen-robotics/AmazingHand Amazing-Hand-Enhanced README BOM link: Google Sheet, BOM tab | high |
Axis D2x16Finger pivot pins | 8 | 2 mm pin, 16 mm long; 6.40 EUR line total in the source sheet | AliExpress0.80 EUR eachpollen-robotics/AmazingHand Amazing-Hand-Enhanced README BOM link: Google Sheet, BOM tab | high |
Bushing Dinterior 6mm / Dexterior 8mm (GFM 0608-04)Two per finger frame, for abduction and adduction | 8 | GFM 0608-04 plain bushing, 6 mm bore, 8 mm outside; 12.80 EUR line total in the source sheet | AliExpress1.60 EUR eachpollen-robotics/AmazingHand Amazing-Hand-Enhanced README BOM link: Google Sheet, BOM tab | high |
Thermoplastic screws 2.5x6Finger shell screws | 16 | 2.5x6 mm screw for plastics; 0.16 EUR line total in the source sheet | AliExpress0.01 EUR eachpollen-robotics/AmazingHand Amazing-Hand-Enhanced README BOM link: Google Sheet, BOM tab | high |
Thermoplastic screws 2.5x8Finger, hand plate and shell screws | 30 | 2.5x8 mm screw for plastics; 0.30 EUR line total in the source sheet | AliExpress0.01 EUR eachpollen-robotics/AmazingHand Amazing-Hand-Enhanced README BOM link: Google Sheet, BOM tab | high |
Washer M2.5 Dexterior 8mm (large serie)One per finger, under the gimbal screw | 4 | M2.5 large washer, 8 mm outside; 1.72 EUR line total in the source sheet | Amazon.fr0.43 EUR eachpollen-robotics/AmazingHand Amazing-Hand-Enhanced README BOM link: Google Sheet, BOM tab | high |
3D printed partsEnhanced-specific parts plus the finger parts shared with the original; the sheet's 3D Printing parts tab lists PLA and Filaflex 82A or eSun TPE 83A | 1 | printed hand set | 3D print yourself15.00 EURpollen-robotics/AmazingHand Amazing-Hand-Enhanced README BOM link: Google Sheet, BOM tab | high |
WaveShare serial bus servo driver boardController and serial bus driver section of the sheet | 1 | Waveshare serial bus servo driver board | Amazon.fr11.39 EURpollen-robotics/AmazingHand Amazing-Hand-Enhanced README BOM link: Google Sheet, BOM tab | high |
Rows from the source's own parts list 13
AmazingHand_Enhanced BOM sheet, BOM tabgoogle_sheet
| Source row | Qty | Price and vendor | Line |
|---|---|---|---|
Feetech STS3032 Servos | 8 | fr.aliexpress.com215.92 EUR | L3 |
Ball joint M2 x L19 | 16 | amazon.fr17.60 EUR | L5 |
M2 threaded rod L300mm | 1 | fr.aliexpress.com1.71 EUR | L7 |
Axis D2x10 | 8 | fr.aliexpress.com4.00 EUR | L8 |
Axis D2x16 | 8 | fr.aliexpress.com6.40 EUR | L9 |
Bushing Dinterior 6mm / Dexterior 8mm (GFM 0608-04) | 8 | fr.aliexpress.com12.80 EUR | L10 |
Thermoplastic screws 2.5x6 | 16 | fr.aliexpress.com0.16 EUR | L11 |
Thermoplastic screws 2.5x8 | 30 | fr.aliexpress.com0.30 EUR | L12 |
5 more rows in AmazingHand_Enhanced BOM sheet, BOM tab
How to build
Upstream step marks a step taken from the linked guide.
Buy the parts
Order the Enhanced BOM: 8 Feetech STS3032 servos, 16 M2 ball joints, a 300 mm M2 threaded rod, 8 D2x10 and 8 D2x16 pins, 8 GFM 0608-04 bushings, 2.5x6 and 2.5x8 thermoplastic screws, 4 large M2.5 washers and a Waveshare serial bus driver board.
Upstream stepdocs.google.com/spreadsheets/d/180ta_jQhF-YGHinabTnSPGtvGcQO...Print the parts
Print the parts specific to the Enhanced hand (the one-piece finger frame, the custom servo horn, the hand plate, wrist interface, palm shell and top shell) from AmazingHand_Enhanced/cad, and the finger parts shared with the original hand (proximal, distal, gimbal, link and finger shells) from cad/.
Upstream stepgithub.com/pollen-robotics/AmazingHand/blob/31bfc548270a3068...Prepare the components
Cut the M2 threaded rod into 4 rods of 26 to 28 mm and 8 rods of 14 to 16 mm, and cut 8 of the ball joints' M2x12 screws to 10 mm. Drill each custom servo horn hole at 1.5 mm and tap an M2 thread. Drill the 2 mm pivot holes of the printed finger parts so some slide and the others hold tight, and clean the supported surfaces.
Upstream stepgithub.com/pollen-robotics/AmazingHand/blob/31bfc548270a3068...Build the finger mechanism
Set each ball joint rod to length on the printed length tooling, turn one ball joint 90 degrees, and screw the rod to a custom servo horn with an M2x10 screw and nut. Pin the link and gimbal into the distal part with the D2x10 axes, then the distal sub-assembly into the proximal part with the D2x16 axes, check that flexion is smooth, and add the 25 mm threaded rod and the two shells with 2.5x6 screws, without overtightening.
Upstream stepgithub.com/pollen-robotics/AmazingHand/blob/31bfc548270a3068...Fit the servos and finish each finger
Press the two bushings into the finger frame, insert two STS3032 servos diagonally under the crossbar and fix them with eight 2x7 screws. Mount the finger mechanism in the bushings with the large washer and a 2.5x8 screw, tight enough to remove play but free to move, then attach the ball joint rods to the link's threaded rod with M2 nuts.
Upstream stepgithub.com/pollen-robotics/AmazingHand/blob/31bfc548270a3068...Set IDs and calibrate each finger
Connect the Waveshare serial bus driver, open Feetech's FD software at 1000000 baud and give each servo its ID: index 1 and 2, middle 3 and 4, ring 5 and 6, thumb 7 and 8. Run AmazingHand-Enhanced_FingerMiddlePos.py, fit the servo horns at the middle position with the M2x4 screws, then run AmazingHand-Enhanced_FingerTest.py and adjust each middle position until the closed finger brings the horns against the frame's crossbar. Save the values.
Upstream stepgithub.com/pollen-robotics/AmazingHand/blob/31bfc548270a3068...Mount the fingers and close the hand
Pass the wires through the hand plate and fix the index, middle and ring fingers with three 2.5x8 screws each, fix the thumb on the wrist interface the same way, and join the wrist interface and hand plate with four screws. Link all servos on one bus with the small three-connector boards that come with the STS servos, then fit the soft palm shell and the top shell with 2.5x8 screws.
Upstream stepgithub.com/pollen-robotics/AmazingHand/blob/31bfc548270a3068...Run the demo
Run the Python demo in AmazingHand_Enhanced/PythonExample. The README says an external 6V / 2A power supply can be used for these motors.
Upstream stepgithub.com/pollen-robotics/AmazingHand/blob/31bfc548270a3068...
Wiring, power and firmware are safety-relevant and shown for reference only. Check them against the source before building.
metCAD / mesh present10 editable CAD files (STEP) + 10 mesh files20/20
Quality tier 3 of 3
metBOM evidenceReviewedThe README-linked Google Sheet lists 11 purchased lines with unit price, quantity, line price and buy link, totalling 275.61 EUR, or 287.00 EUR with the driver; the 6V supply is unpriced. The engine does not open Google Sheets.20/20
Quality tier 4 of 5
Reviewed override, 2026-10-02
Evidence on docs.google.comEngine alone: partial at tier 1 (BOM spreadsheet linked, not inspected by the engine)
partialWiring diagramReviewedThe assembly PDF describes the wiring in text only: both finger servos on one serial bus to the Waveshare driver, then all eight linked through the three-connector boards that come with the STS servos. No diagram.7.5/15
Quality tier 1 of 3
Reviewed override, 2026-10-02
Evidence on github.comEngine alone: missing at tier 0 (no wiring diagram found)
partialFirmware linkedfirmware mentioned, no source or link5/10
Quality tier 1 of 3
metBuild instructionsstep-by-step guide with images15/15
Quality tier 2 of 3
metOSHW-compatible licenseCC-BY-4.0 (from README license statement)10/10
Quality tier 2 of 2
missingKnown reproductionsno verified builds yet0/10
Quality tier 0 of 2
Only build reports a maintainer or admin has reviewed count here.
Engine v3.1.1 at 31bfc54, 2 items reviewed by hand
How this score is computedFiles and sim
- AmazingHand_Enhanced/cad/Step/Amazing Hand Enhanced Parts - Finger_Frame.step
- AmazingHand_Enhanced/cad/Step/Servo Horn - Custom_Servo-Horn.step
- AmazingHand_Enhanced/cad/Step/Amazing Hand Enhanced Parts - R-Hand_Plate.step
- AmazingHand_Enhanced/cad/Step/Amazing Hand Enhanced Parts - R-Wrist_Interface.step
- AmazingHand_Enhanced/cad/Step/Amazing Hand Enhanced Parts - R-Palm_Shell.step
- AmazingHand_Enhanced/cad/Step/Amazing Hand Enhanced Parts - R-Top_Shell.step
- AmazingHand_Enhanced/cad/Step/Amazing Hand Enhanced Parts - L-Hand_Plate.step
- AmazingHand_Enhanced/cad/Step/Amazing Hand Enhanced Parts - L-Wrist_Interface.step
- AmazingHand_Enhanced/cad/Step/Amazing Hand Enhanced Parts - L-Palm_Shell.step
- AmazingHand_Enhanced/cad/Step/Amazing Hand Enhanced Parts - L-Top_Shell.step
- AmazingHand_Enhanced/cad/Stl/Amazing Hand Enhanced Parts - Finger_Frame.stl
- AmazingHand_Enhanced/cad/Stl/Servo horn - Custom_Servo-Horn.stl
- cad/step/Amazing Hand Parts - Proximal.step
- cad/step/Amazing Hand Parts - Distal.step
- cad/step/Amazing Hand Parts - Gimbal.step
- cad/step/Amazing Hand Parts - Link.step
- cad/step/Amazing Hand Parts - Proximal_Shell.step
- cad/step/Amazing Hand Parts - Distal_Shell.step
- AmazingHand_Enhanced/Docs/AmazingHand-Enhanced_Assembly.pdf
- docs/AmazingHand_3DprintingTips.pdf
- AmazingHand_Enhanced/PythonExample/AmazingHand-Enhanced_FingerMiddlePos.py
- AmazingHand_Enhanced/PythonExample/AmazingHand-Enhanced_FingerTest.py
- AmazingHand_Enhanced/PythonExample/AmazingHand-Enhanced_Demo_R.py
- AmazingHand_Enhanced/Demo/AHSimulation/AHSimulation/AH_Right/mjcf/robot.xml
Files stay in the upstream repository under their own licenses; these links open them there. The 3D model on this page is Motari's conversion of the file named under Simulation.
Simulation
Robot description files a simulator or CAD tool can load, linked at the commit they were found.
- MJCF (MuJoCo)AmazingHand_Enhanced/Demo/AHSimulation/AHSimulation/AH_Right/mjcf/robot.xmlpollen-robotics/AmazingHand
- Onshapecad.onshape.com/documents/430ff184cf3dd9557aaff2be/w/b018c00...
The 3D specimen on this page is converted from AmazingHand_Enhanced/Demo/AHSimulation/AHSimulation/AH_Right/mjcf/robot.xml at eb78a9d, the project's simulation model in pollen-robotics/AmazingHand, not its build CAD.
Builds
No reviewed builds of Amazing Hand Enhanced yet.
A build log records the evidence (photos, a video, your repository), what the build cost, how long it took and what you changed. Each one is checked by Motari (until a maintainer claims this page) before it shows here, and reviewed builds count toward the reproducibility score.
Sources
Where the facts come from
- Hardwaregithub.com/pollen-robotics/AmazingHand/tree/Amazing-Hand-Enh...31bfc54
- Bill of materialsdocs.google.com/spreadsheets/d/180ta_jQhF-YGHinabTnSPGtvGcQO...
- Build guidegithub.com/pollen-robotics/AmazingHand/blob/Amazing-Hand-Enh...31bfc54
- Simulationgithub.com/pollen-robotics/AmazingHand/tree/AH-Enhanced-Demo...eb78a9d
Last push to pollen-robotics/AmazingHand: 2026-04-23 (checked 2026-10-02)
Related links
- Source repositorypollen-robotics/AmazingHand, Amazing-Hand-Enhanced branch
- Onshape CADpublic document, Enhanced workspace
- Assembly guideAmazingHand-Enhanced_Assembly.pdf
- MuJoCo modelAH-Enhanced-Demo branch, right and left hands
How this page was made
Assembled from public sources on 2026-10-02, not yet reviewed by the maintainer. Each figure links to where it is stated; a value the sources do not state reads "not published". Last source review: 2026-10-02 pollen-robotics/AmazingHand@31bfc54 (Amazing-Hand-Enhanced) README, LICENSE, tree, assembly PDF; BOM sheet.
Original files stay intact and separately licensed; Motari adds only the summary on this page. Maintainer? Request a correction or removal.
Robots like Amazing Hand Enhanced
Lineage
- Supersedes
- Amazing Hand
None of the parts in this bill of materials is tracked across robots yet. See the parts robots have in common.
Similar robots
The same type of robot, closest first by body plan, published cost and degrees of freedom. All grippers and robot hands
Badge for the README
Maintain Amazing Hand Enhanced? Show its reproducibility score in the project's README. The badge links back to this page and updates with the score.

[](https://motari.io/r/amazing-hand-enhanced)<a href="https://motari.io/r/amazing-hand-enhanced"><img src="https://motari.io/api/v1/badge/amazing-hand-enhanced" alt="Motari reproducibility score for Amazing Hand Enhanced" height="20"></a>Not fully met yet: wiring diagram (partial), firmware linked (partial). The score is read from the project's own sources, so publishing what is missing is what raises it. A score of 90 or more needs a reviewed build. How the score is computed