
Pedro 2.0
OSHWA-certified 4-axis 3D-printed educational robotic arm.
- Cost unknownnot published by the source
- 4 DoF
- Apache-2.0hardware
- 63 / 100 reproducibilityPartial source coverage, unverified
What it is
Pedro 2.0 is a fully open-source, 3D-printable 4-axis robotic arm designed in France for STEM education. The Pedro3DFiles repository publishes the STL files for the snap-together chassis (assembly steps are in the Pedro STEM lessons), while PedroBoard publishes Gerber files, PCB layouts and BOM CSVs for the ATmega32U4 controller board. The README lists four 360-degree mini servos, two 8x22x7 mm bearing balls, a 7.4 V battery, a micro USB cable and the Pedro Board as the core hardware. The 3D view places the ARM, BASE, GEAR and SERVO parts as static STL files; upstream publishes no URDF or assembly file.
Licenses
- Hardware
- Apache-2.0
- Software
- Apache-2.0
- Docs
- CC BY-SA (version not stated)per the OSHWA certification record
Degrees of freedom
4 DoF arm 3gripper 1
Serial armsource
Auto-assembled, not yet reviewed
Source record
- Sources
- 158 stars, last push 2026-09-22
- HW license
- Apache-2.0
- Cost
- not published
- Lifecycle
- Active
- Engine
- v3.1.1
- Checked
- Model
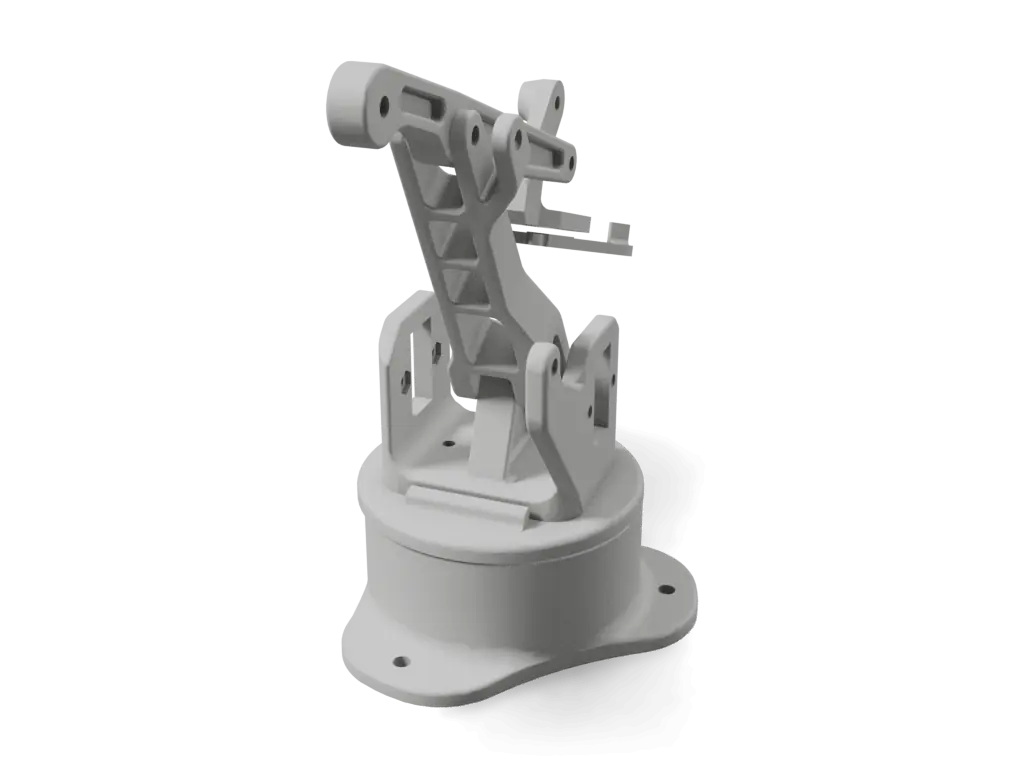
- ARM.stl@ed960b1source parts laid out, not the assembled robotrendered 2026-06-06
Maintain Pedro 2.0? Claim this page to correct it.
Parts and cost
Cost to build
The sources do not publish a cost total. The rows below are what they list, without a sum.
Pedro 2.0 parts, as the source lists them (read 2026-09-30). Prices are the source's, not checked against vendors.
| Part | Qty | Spec | Source | Confidence |
|---|---|---|---|---|
Mini servo motor 360 degfour project drive servos | 4 | 360 degree mini servo motors | generic / Pedro-compatibleprice not listedPedro README features list lines 32-35 | high |
Bearing ball 8x22x7 mmbearing balls for smooth rotation | 2 | 8x22x7 mm bearing balls | genericprice not listedPedro README features list line 34 | high |
Pedro Board controllerproject-specific controller PCB | 1 | ATmega32U4 controller board; Rev3 adds ESP8266-01 and HC-05 options | make yourself from PedroBoard Gerbers/BOMBOM CSV published, full assembled board cost not totalledPedro README lines 23-25 and PedroBoard README lines 31-45 / BOM.csv | high |
7.4V rechargeable batteryrobot power source | 1 | 7.4 V USB-rechargeable battery pack | genericprice not listedPedro README features list line 36 | high |
Micro USB cablecharging, firmware upload and serial data | 1 | Micro USB cable | genericprice not listedPedro README features list line 37 | high |
3D printed chassis partsARM, BASE, GEAR and SERVO STL files | 1 | PLA or ABS, 0.2 mm layer height | 3D print yourselfsource files published; local material cost not pricedPedro README lines 23, 32, 46-49 and repository STL paths | high |
NRF24L01 moduleIncluded in the Pedro kit; used for radio control mode | 1 | 2.4 GHz radio module | Pedro kit / genericprice not listedPedro robot kit contents on pedrobot.com | high |
OLED 128x64 displayIncluded in the Pedro kit; inserted into the Pedro board in STEM Lesson 3 | 1 | 128x64 OLED | Pedro kit / genericprice not listedPedro robot kit contents on pedrobot.com | high |
Bluetooth HC-05 moduleIncluded in the Pedro kit; used for Bluetooth control mode | 1 | HC-05 Bluetooth serial module | Pedro kit / genericprice not listedPedro robot kit contents on pedrobot.com | high |
Rows from the source's own parts list 6
README.md@ed960b1markdown
| Source row | Qty | Price and vendor | Line |
|---|---|---|---|
Pedro project source repositories | project source set | github.comno price listed | L20 |
Pedro main robot parts list | 4 servos; 2 bearings; one board; one battery; one cable; printed chassis | Pedro / generic componentsno price listed | L30 |
3D printed chassis material guidance | one printed chassis set | self-printno price listed | L46 |
Tool-free photo assembly instructions | one assembly guide | Pedrono price listed | L63 |
README.md@cc199c6markdown
| Source row | Qty | Price and vendor | Line |
|---|---|---|---|
Pedro Board fabrication and bootloader requirements | one controller board | PedroBoard / self-fabricateno price listed | L31 |
gerber_files/PedroBoard_Rev3.1/BOM.csv@cc199c6csv
| Source row | Qty | Price and vendor | Line |
|---|---|---|---|
PedroBoard Rev3.1 electronic BOM | 58 CSV lines including header | PedroBoard / LCSC/JLCPCB component datano price listed | L1 |
How to build
Steps marked Motari summary condense the linked source; follow the source for exact instructions. Upstream step marks a step taken from the linked guide.
Print the structural parts
Print ARM.stl, BASE.stl, GEAR.stl and SERVO.stl at 40% infill with the support settings given in the Pedro3DFiles README.
Upstream stepgithub.com/almtzr/Pedro3DFiles/blob/7c332950d9a3d5aa56f00984...Assemble the chassis
Snap the printed parts together without tools, following the base, gripper and arm assembly steps in Pedro STEM Lesson 3.
Motari summaryalmtzr.github.io/PedroSTEMLessons/stem_lessons/Pedro_Lesson_...Mount the servos and bearings
Install the four 360-degree mini servos and the two 8x22x7 mm bearing balls.
Motari summaryalmtzr.github.io/PedroSTEMLessons/stem_lessons/Pedro_Lesson_...Wire the Pedro Board
Connect the servos and 7.4V battery to the Pedro controller board (PedroBoard repo).
Motari summaryalmtzr.github.io/PedroSTEMLessons/stem_lessons/Pedro_Lesson_...Flash and control
Install the PedroRobot library in the Arduino IDE, select Arduino Micro, upload the Pedro example sketch, then use manual, record and replay, radio, Bluetooth or USB serial control.
Upstream stepgithub.com/almtzr/PedroFirmware/blob/56c125d1595b02adb40bd4b...
Wiring, power and firmware are safety-relevant and shown for reference only. Check them against the source before building.
partialCAD / mesh present4 mesh files; no editable CAD source in the repo10/20
Quality tier 2 of 3
- stl/ARM.stl7c33295
- stl/BASE.stl7c33295
partialBOM evidencegerber_files/PedroBoard_Rev3.1/BOM.csv present, contents not parseable10/20
Quality tier 1 of 5
partialWiring diagramPCB fabrication files only (Gerbers), no schematic or wiring diagram7.5/15
Quality tier 1 of 3
metFirmware linkedfirmware source in the repo (Arduino)10/10
Quality tier 3 of 3
metBuild instructionsReviewedLesson 3 PDF is an illustrated assembly guide: parts check, then STEP 1 Base, STEP 2 Gripper, STEP 3 Arm over 8 pages of exploded renders; the engine does not open linked PDFs.15/15
Quality tier 2 of 3
Reviewed override, 2026-09-30
Evidence on almtzr.github.ioEngine alone: partial at tier 1 (external build guide linked, not inspected by the engine)
metOSHW-compatible licenseApache-2.0 (from repository license)10/10
Quality tier 2 of 2
- LICENSE7c33295
missingKnown reproductionsno verified builds yet0/10
Quality tier 0 of 2
Only build reports a maintainer or admin has reviewed count here.
Engine v3.1.1 at 7c33295, 1 item reviewed by hand
- The engine found no joint model or stated figure to count degrees of freedom from.
- The engine could not tell what kind of robot this is from its sources.
Files and sim
Files stay in the upstream repository under their own licenses; these links open them there. The 3D model on this page is Motari's conversion of the file named under Simulation.
Simulation
Robot description files a simulator or CAD tool can load, linked at the commit they were found.
No URDF, MJCF, SDF, USD or Onshape model has been found in the sources.
The 3D specimen on this page is converted from stl/ARM.stl at ed960b1, with the parts laid out side by side because the source has no assembly.
Builds
No reviewed builds of Pedro 2.0 yet.
A build log records the evidence (photos, a video, your repository), what the build cost, how long it took and what you changed. Each one is checked by Motari (until a maintainer claims this page) before it shows here, and reviewed builds count toward the reproducibility score.
Sources
Where the facts come from
- Hardwaregithub.com/almtzr/Pedro3DFiles7c33295
- Hardwaregithub.com/almtzr/PedroBoardcc199c6
- Softwaregithub.com/almtzr/PedroFirmware56c125d
- Build guidealmtzr.github.io/PedroSTEMLessons/stem_lessons/Pedro_Lesson_...
- Documentationgithub.com/almtzr/PedroSTEMLessonsfce57e9
- Storepedrobot.com/Store.html
Last push to almtzr/Pedro3DFiles: 2026-09-22 (checked 2026-10-01)
Related links
- Project sitepedrobot.com
How this page was made
Assembled from public sources on 2026-06-04, not yet reviewed by the maintainer. Each figure links to where it is stated; a value the sources do not state reads "not published". Last source review: 2026-06-07 Pedro README + PedroBoard BOM CSV.
Original files stay intact and separately licensed; Motari adds only the summary on this page. Maintainer? Request a correction or removal.
Robots like Pedro 2.0
None of the parts in this bill of materials is tracked across robots yet. See the parts robots have in common.
Similar robots
The same type of robot, closest first by body plan, published cost and degrees of freedom. All robot arms
Badge for the README
Maintain Pedro 2.0? Show its reproducibility score in the project's README. The badge links back to this page and updates with the score.

[](https://motari.io/r/pedro-arm)<a href="https://motari.io/r/pedro-arm"><img src="https://motari.io/api/v1/badge/pedro-arm" alt="Motari reproducibility score for Pedro 2.0" height="20"></a>Not fully met yet: cad / mesh present (partial), bom evidence (partial), wiring diagram (partial). The score is read from the project's own sources, so publishing what is missing is what raises it. A score of 90 or more needs a reviewed build. How the score is computed