
Actuated UMI Gripper
3D-printable, belt-driven actuated version of the UMI gripper on a Dynamixel servo.
- Cost unknownnot published by the source
- 1 DoF
- MIThardware
- 68 / 100 reproducibilityPartial source coverage, unverified
What it is
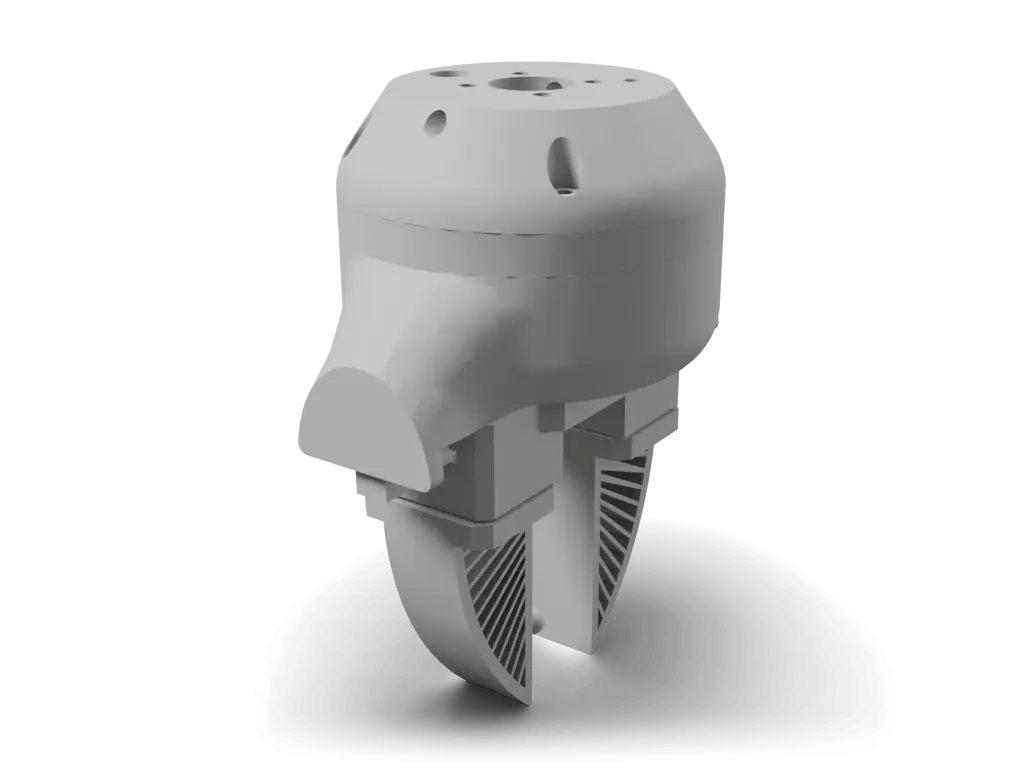
The Actuated UMI Gripper is an open-source, 3D-printable parallel-jaw gripper that adds powered actuation to the Universal Manipulation Interface (UMI) hand-held gripper. A single DYNAMIXEL XL430-W250-T servo drives the jaws through a flat belt and twin MGN7C linear rails, with two constant-force springs. The repo provides v1 and v2 STL part sets, STEP assembly files, and an assembly guide, with optional GelSight Mini tactile mounts in v2.
Licenses
Degrees of freedom
1 DoF gripper 1
Parallel grippersource
Auto-assembled, not yet reviewed
Source record
Maintain Actuated UMI Gripper? Claim this page to correct it.
Parts and cost
Cost to build
The sources do not publish a cost total. The rows below are what they list, without a sum.
Actuated UMI Gripper parts, as the source lists them. Prices are the source's, not checked against vendors.
| Part | Qty | Spec | Source | Confidence |
|---|---|---|---|---|
DYNAMIXEL XL430-W250-T servosmart actuator for powered jaw motion | 1 | DYNAMIXEL XL430-W250-T | MyBotShop / ROBOTIS channelprice not listedREADME source BOM line 72 | high |
ROBOTIS DYNAMIXEL U2D2USB-to-Dynamixel interface | 1 | U2D2 interface | MyBotShop / ROBOTIS channelprice not listedREADME source BOM line 73 | high |
ROBOTIS DYNAMIXEL U2D2 Power HubDynamixel bus power distribution | 1 | U2D2 Power Hub | MyBotShop / ROBOTIS channelprice not listedREADME source BOM line 74 | high |
Constant Force SpringListed in the README BOM | 2 | 0.1 x 8 x 110 | AliExpress listing linked by the projectprice not listedREADME source BOM line 75 | high |
Linear rail and carriagejaw guidance rails | 2 | 80 mm MGN7C | AliExpress listing linked by the projectprice not listedREADME source BOM line 76 | high |
Flat beltjaw drive belt | 1 | 5 mm width, 1 mm thickness, 300 mm length | KeilriemenExpressprice not listedREADME source BOM line 77 | high |
Heat-set insertsthreaded inserts for printed parts | 1 | assorted heat-set insert kit | Amazon listing linked by the projectprice not listedREADME source BOM line 78 | high |
M3 cylindrical head screws and nutsprimary fasteners | 1 | M3 screw/nut assortment | Amazon listing linked by the projectprice not listedREADME source BOM line 79 | high |
M2 flat head screwssmall fasteners | 1 | M2 flat-head screw assortment | Amazon listing linked by the projectprice not listedREADME source BOM line 80 | high |
3D-printed gripper parts setstructure, jaws, idler, pulley, fingers and Franka mount | 1 | PLA/FDM print settings listed per part; TPU fingers defer to UMI guide | 3D print yourselfprice not listedREADME print table lines 90-97 | high |
Rows from the source's own parts list 17
README.md@8e9e957markdown
| Source row | Qty | Price and vendor | Line |
|---|---|---|---|
DYNAMIXEL XL430-W250-T | 1 | MyBotShopmybotshop.deno price listed | L72 |
ROBOTIS DYNAMIXEL U2D2 | 1 | MyBotShopmybotshop.deno price listed | L73 |
ROBOTIS DYNAMIXEL U2D2 POWER HUB | 1 | MyBotShopmybotshop.deno price listed | L74 |
Constant Force Spring (0.1x8x110) | 2 | AliExpressde.aliexpress.comno price listed | L75 |
Linear Rail & Carriage (80mm - MGN7C) | 2 | AliExpressde.aliexpress.comno price listed | L76 |
Flat Belt (width 5mm, thickness 1mm, length 300mm) | 1 | KeilriemenExpresskeilriemenexpress.deno price listed | L77 |
Heat Sets | 1 | L78 | |
Cylindrical Head Screws & Nuts (M3) | 1 | L79 |
9 more rows in README.md
How to build
Steps marked Motari summary condense the linked source; follow the source for exact instructions. Upstream step marks a step taken from the linked guide.
Print the parts
Print the v1 or v2 STL set (structure, jaws, drive pulley, spring idler, carriage and gripper mounts) in PLA.
Motari summaryyoutube.com/watchInstall rails and belt
Install the two 80 mm MGN7C linear rails with carriages and the 300 mm flat belt (5 mm wide, 1 mm thick), following the assembly video.
Motari summaryyoutube.com/watchFit the constant-force springs
Install the two constant-force springs (0.1 x 8 x 110) with the two printed CF spring idlers, following the assembly video.
Motari summaryyoutube.com/watchMount the Dynamixel servo
Bolt in the XL430-W250-T servo and connect it through the U2D2 and power hub.
Motari summaryyoutube.com/watchControl via Dynamixel API
Drive open/close through the Dynamixel control API referenced in the README.
Upstream stepgithub.com/TimSchneider42/dynamixel-api/blob/918c6bba61b89e1...
Wiring, power and firmware are safety-relevant and shown for reference only. Check them against the source before building.
metCAD / mesh present2 editable CAD files (STEP), including an assembly + 20 mesh files20/20
Quality tier 3 of 3
metBOM evidenceREADME.md table (Bill of Materials (BoM)): 9 line items, quantities, vendor links20/20
Quality tier 3 of 5
missingWiring diagramno wiring diagram found0/15
Quality tier 0 of 3
The engine found nothing to point at for this item.
metFirmware linkedcontrol software linked (software source TimSchneider42/dynamixel-api)10/10
Quality tier 2 of 3
partialBuild instructionsbuild section in the docs, no step-by-step guide with images + build video7.5/15
Quality tier 1 of 3
metOSHW-compatible licenseMIT (from repository license)10/10
Quality tier 2 of 2
- LICENSE8e9e957
missingKnown reproductionsno verified builds yet0/10
Quality tier 0 of 2
Only build reports a maintainer or admin has reviewed count here.
Engine v3.1.1 at 8e9e957
- The engine found no joint model or stated figure to count degrees of freedom from.
Files and sim
- assembly/actuated-UMI-v2-assy.step
- assembly/actuated-UMI-v1-assy.step
- 3d-printables/actuated-UMI-v1/actuated-UMI-gripper-structure.stl
- 3d-printables/actuated-UMI-v2/actuated-UMI-gripper-structure.stl
- README.md
Files stay in the upstream repository under their own licenses; these links open them there. The 3D model on this page is Motari's conversion of the file named under Simulation.
Simulation
Robot description files a simulator or CAD tool can load, linked at the commit they were found.
No URDF, MJCF, SDF, USD or Onshape model has been found in the sources.
The 3D specimen on this page is converted from assembly/actuated-UMI-v2-assy.step at 8e9e957.
Builds
No reviewed builds of Actuated UMI Gripper yet.
A build log records the evidence (photos, a video, your repository), what the build cost, how long it took and what you changed. Each one is checked by Motari (until a maintainer claims this page) before it shows here, and reviewed builds count toward the reproducibility score.
Sources
Where the facts come from
- Hardwaregithub.com/actuated-umi/actuated-umi-gripper8e9e957
- Build guideyoutube.com/watch
- Softwaregithub.com/TimSchneider42/dynamixel-api918c6bb
- Documentationactuated-umi.github.io
Last push to actuated-umi/actuated-umi-gripper: 2025-05-06 (checked 2026-10-01)
How this page was made
Assembled from public sources on 2026-06-04, not yet reviewed by the maintainer. Each figure links to where it is stated; a value the sources do not state reads "not published". Last source review: source BOM 8e9e957; unpriced.
Original files stay intact and separately licensed; Motari adds only the summary on this page. Maintainer? Request a correction or removal.
Robots like Actuated UMI Gripper
Shares parts with
Robots whose bill of materials names the same parts, most shared first. Each part links to every robot that uses it.
- Koch v1.1DynamixelXL43089
- ToddlerBotDynamixelXL43070
- TurtleBot3DynamixelXL43063
- Poppy HumanoidDynamixel80
- Q8botDynamixel80
- Stack-chanDynamixel80
Parts in this robot's BOM: ROBOTIS Dynamixel servos (16 other robots), Dynamixel XL430 servo (3 other robots)
Similar robots
The same type of robot, closest first by body plan, published cost and degrees of freedom. All grippers and robot hands
Badge for the README
Maintain Actuated UMI Gripper? Show its reproducibility score in the project's README. The badge links back to this page and updates with the score.

[](https://motari.io/r/actuated-umi-gripper)<a href="https://motari.io/r/actuated-umi-gripper"><img src="https://motari.io/api/v1/badge/actuated-umi-gripper" alt="Motari reproducibility score for Actuated UMI Gripper" height="20"></a>Not fully met yet: wiring diagram, build instructions (partial). The score is read from the project's own sources, so publishing what is missing is what raises it. A score of 90 or more needs a reviewed build. How the score is computed